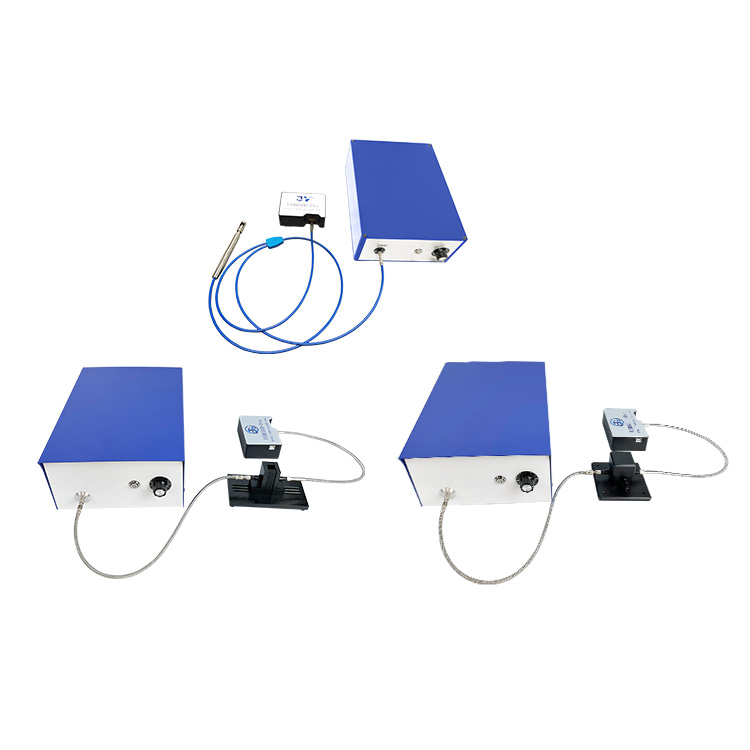
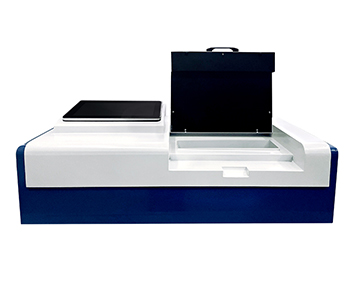
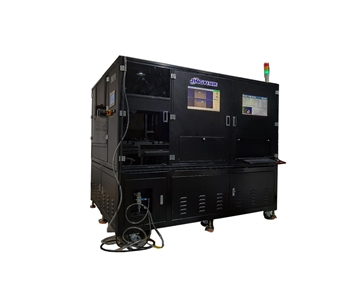
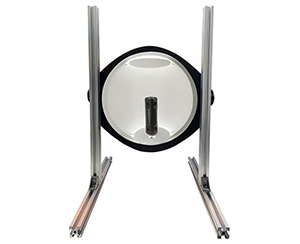
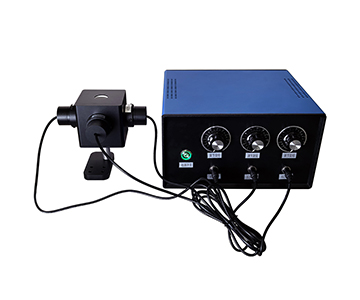
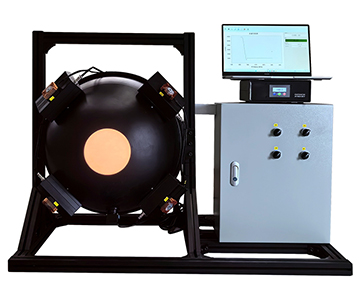
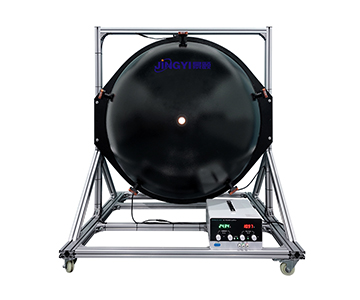
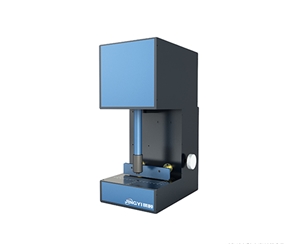
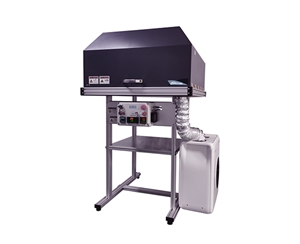
Compare 4 laser beam profiler architectures across 400-1800nm, from 29µm to 200mm beam sizes. Traceability chain, validation methodology, and a 7-step selection framework.
••Executive summary: four architectures, one measurement problem
A laser beam profiler turns the spatial intensity distribution of a laser beam into a reproducible digital value. In this white paper, "reproducible" carries a specific meaning: the result must survive a change of operator, a change of shift, and a change of detector head. That requirement, rather than raw resolution or frame rate, is what separates an inspection instrument from a diagnostic camera.
The four architectures examined here—visible-light CMOS, large-aperture CMOS, InGaAs infrared, and large-format VIS/NIR—cover the 400-1800nm wavelength range and beam sizes from 29µm to 200mm. All share 12-bit digitization depth, USB3.0 output, and external trigger capability. They diverge sharply in detector material, pixel geometry, and usable aperture, which is why no single architecture can be called a universal replacement for the other three.
Two conclusions follow. First, pixel size and measurable beam range jointly determine spatial sampling density: a 2.9×2.9µm pixel provides roughly ten times the sampling points needed to reconstruct a 29µm beam, while a 200mm far-field beam requires the large-format architecture plus an attenuator chain. Second, the traceability of those measurements rests on three separately calibrated links—pixel geometry, attenuator transmission, and algorithmic computation—not on the instrument's nominal repeatability spec alone.
1. Why beam quality measurement is moving from "usable" to "traceable"
The semiconductor equipment market, as documented in the SEMI 2025 annual report, continues to expand with advanced-node capacity additions, and the share of optical inspection and metrology equipment within that market keeps rising. That macro figure is background only; it does not justify any specific instrument choice. The operational fact behind it is narrower: laser processes are becoming sensitive to beam consistency in ways that a pass/fail power reading cannot capture.
In fiber alignment and coupling, a beam centroid shift that falls outside the process window drives down coupling efficiency and raises the risk of thermal failure in the device. The technical white paper published by the Chinese Optical Society identifies beam pointing stability and power fluctuation as key process parameters in high-speed optical module production lines, with real-time monitoring and statistical recording required. Note the direction of the requirement: the measurement device is now part of the process control loop, not a bench instrument consulted after a failure.
A separate observation matters more to line engineers. Beam drift is rarely a single-event defect. It usually appears as a slow centroid walk during a qualification run, visible in the statistics export before it becomes visible in yield data. That is the use case in which 12-bit depth and recorded pass/fail history earn their specification, rather than the headline wavelength range.
What this white paper does not do is introduce external derived claims. From this point forward, every parameter and test method rests on the product specifications listed in the following sections. Industry standards are referenced as context for the measurement framework, not as substitutes for on-site validation.
2. Measurement principle: from spatial intensity distribution to digital matrix
At its core, beam quality analysis converts a spatial light intensity distribution into a digital matrix. The input stage is shared between the detector chip and the attenuator stack: the detector converts photons into an electrical signal, while the attenuator keeps the detector inside its linear response range even when the input power is in the 1000W class.
The beam profiler market uses two detector materials with a hard spectral boundary between them. Visible and large-aperture types use CMOS, covering 400-1100nm; the infrared type uses an InGaAs chip, extending response to 1800nm. For a 1550nm telecom signal, InGaAs is not a preference but a requirement—a CMOS detector has no response at that wavelength. Specifying the wrong detector family is the most common and least recoverable error in beam profiler selection, because no software correction can recover a signal that was never converted.
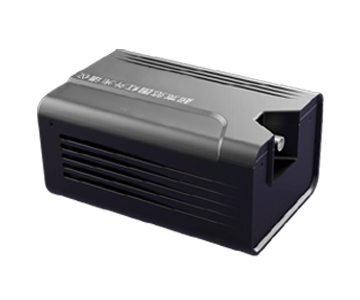
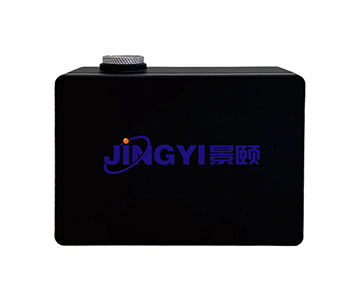
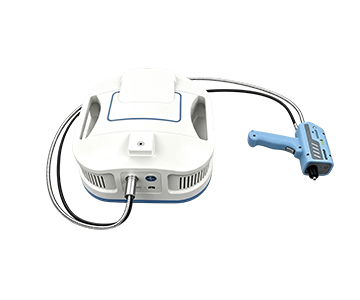
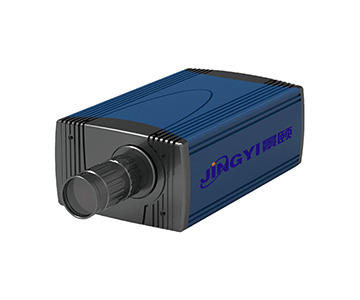
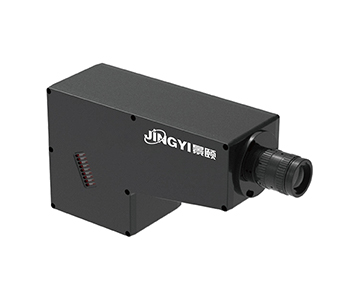
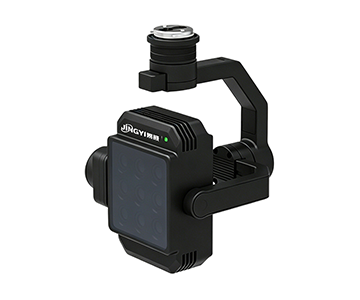
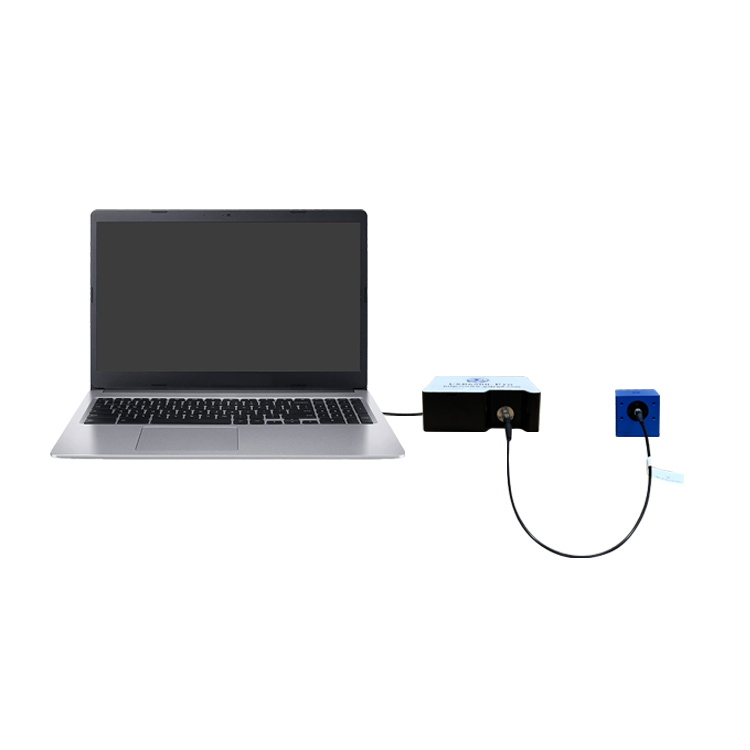
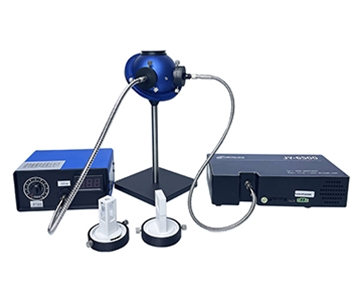
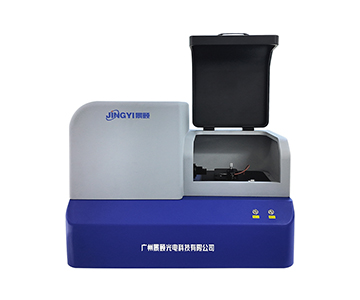
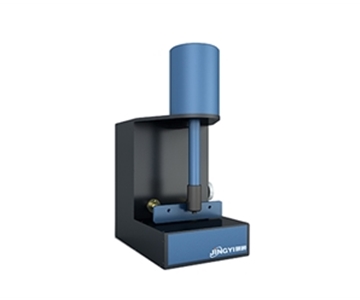
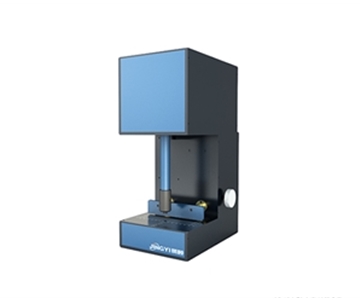
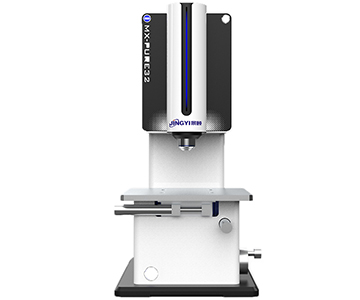
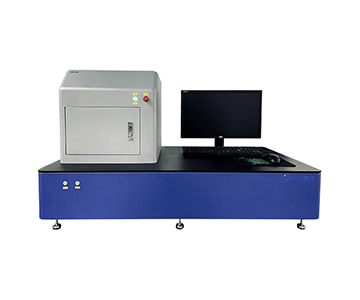
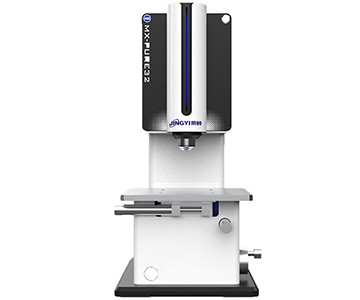
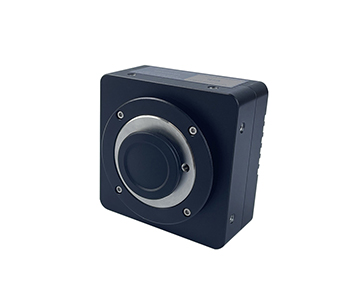
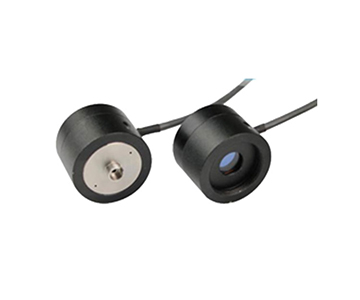
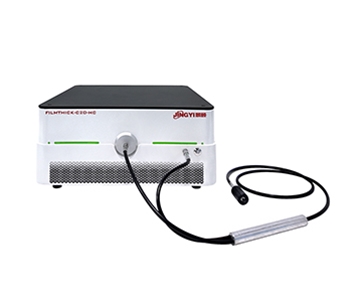
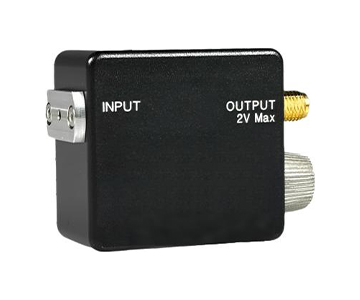
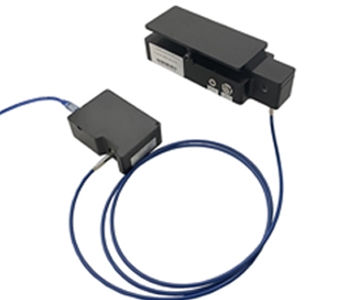
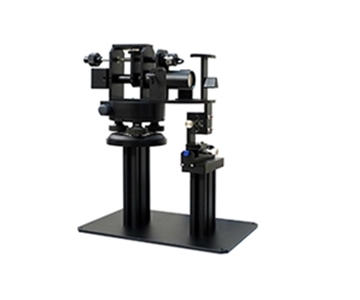
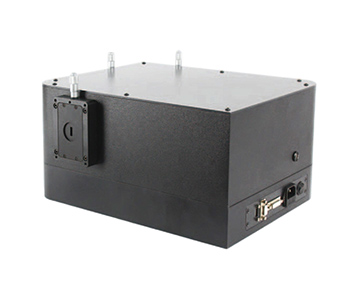
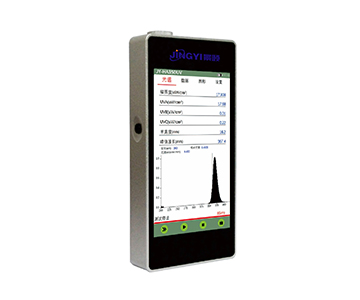
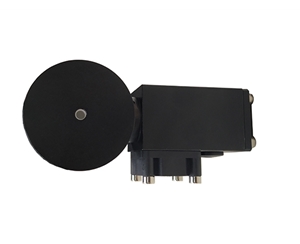
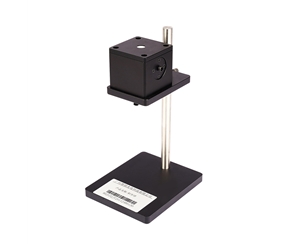
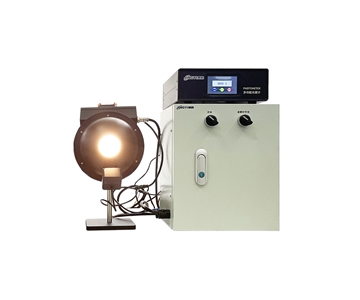
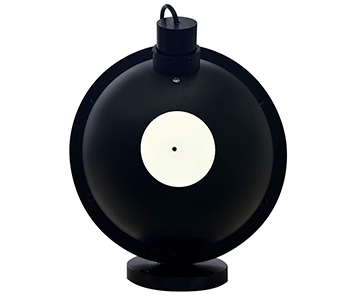
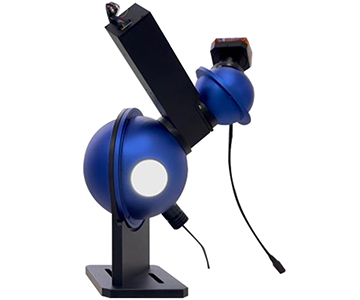
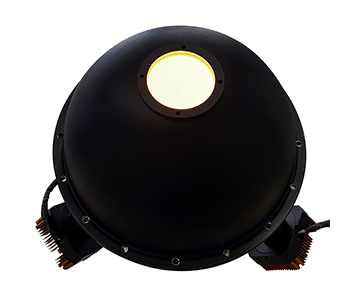
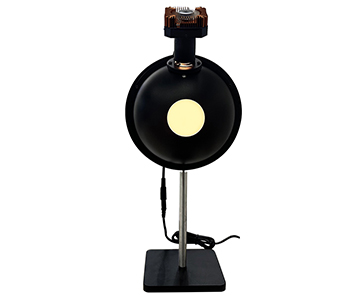
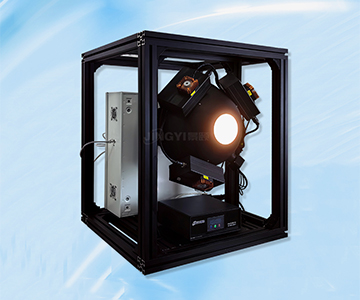
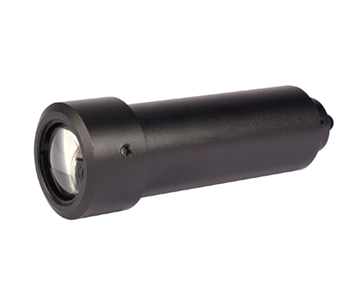
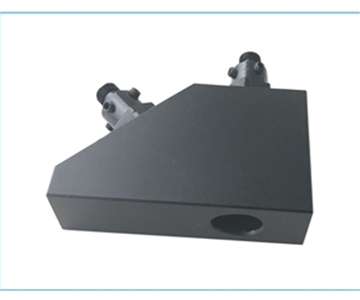
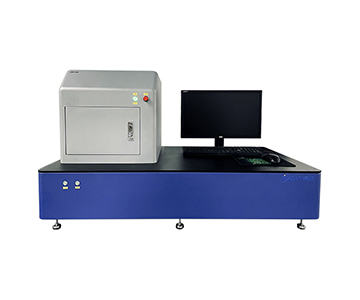
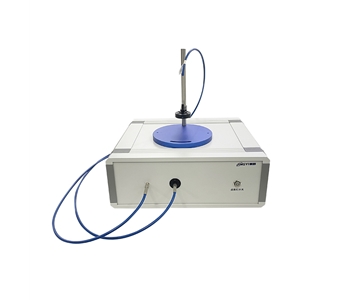
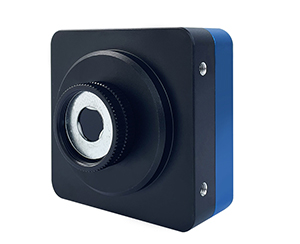
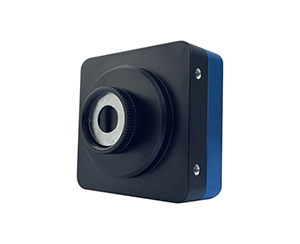
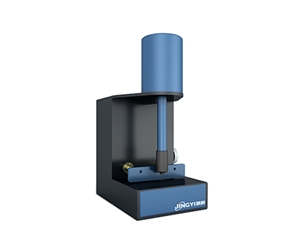
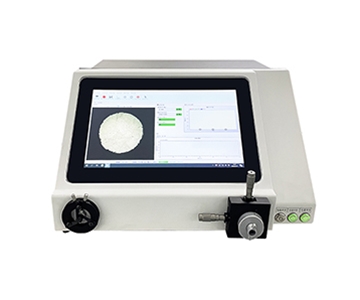
Figure 1: Side-view construction of the infrared architecture, showing the integration of the InGaAs detector module with the precision optical interface.
Signal processing consists of three linked steps: exposure control, gain adjustment, and algorithmic fitting. On the infrared architecture, exposure can be set from 15µs to 60s, with gain from 1× to 15×, in both manual and automatic real-time modes. That range is not a catalog curiosity. It is what allows one algorithm set to cover weak far-field beams and intense near-field beams without changing the optical path.
The algorithm computes beam diameter on the major and minor axes, ellipticity, and Gaussian fit quality, then outputs energy distribution and centroid position. Ellipticity is the parameter most often misunderstood: it reports the difference in divergence between two orthogonal axes, and it is a direct indicator of collimator assembly quality. A beam can have acceptable diameter and still fail assembly qualification because its orthogonal divergence is asymmetric.
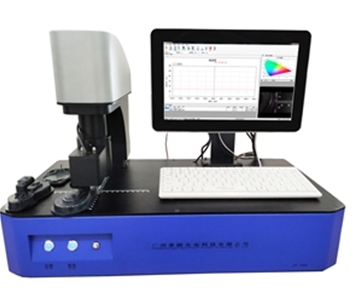
Output is delivered as pseudo-color 2D display and 3D beam profile, with major- and minor-axis Gaussian curves. The recording and export functions generate test reports for line traceability, while pass/fail settings provide the threshold interface for automated production.
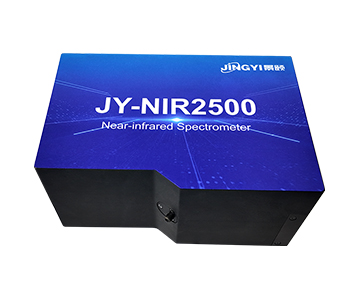
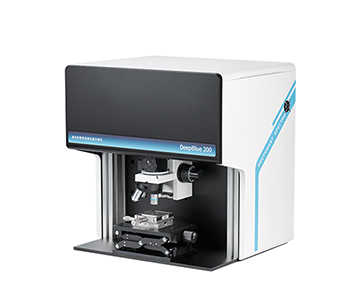
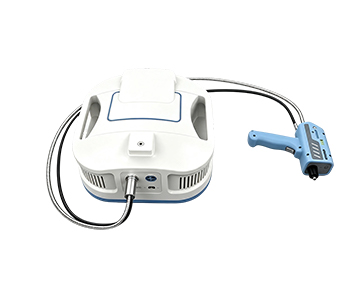
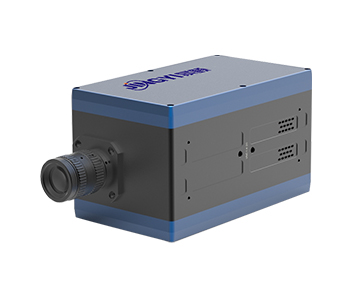
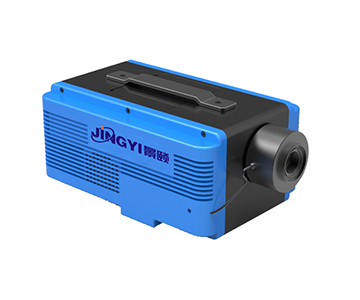
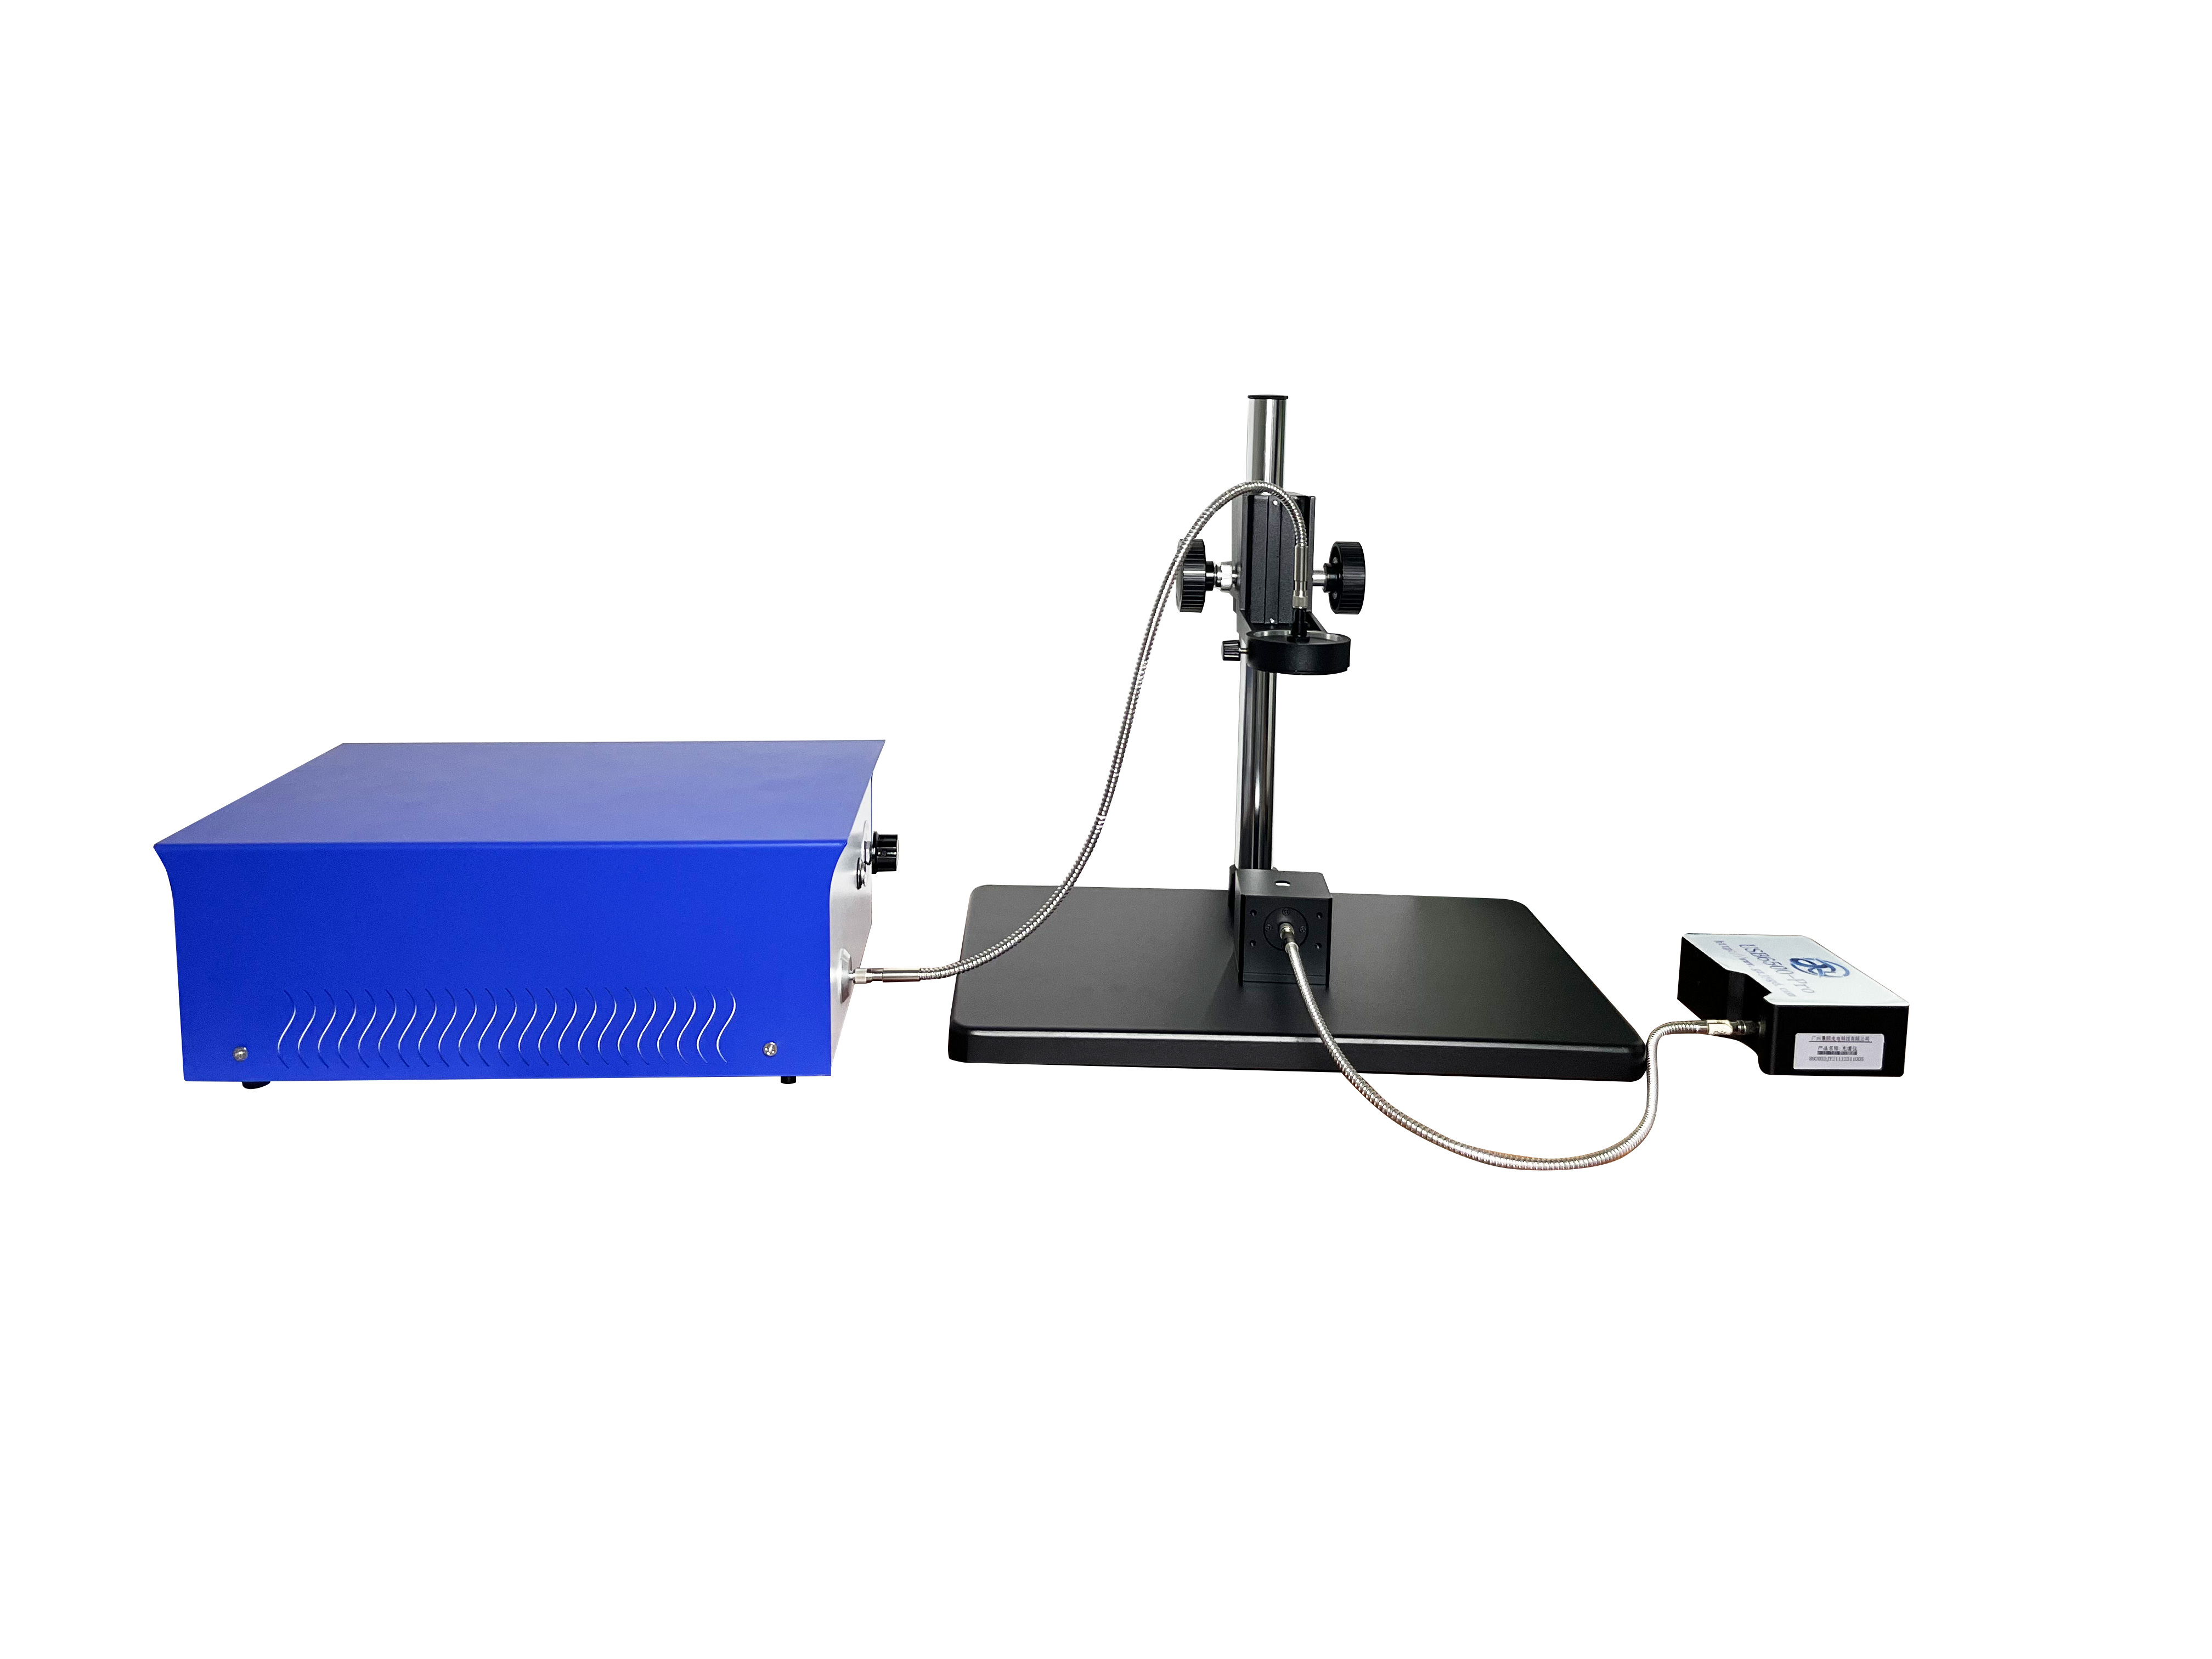
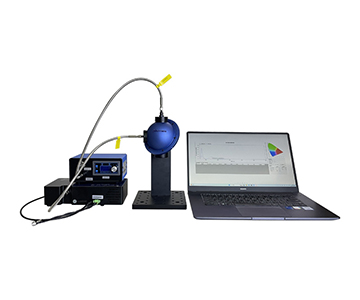
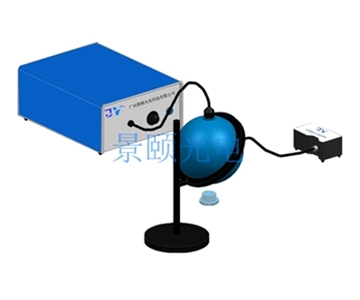
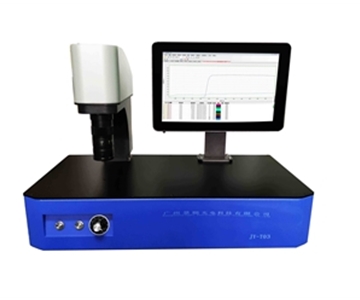
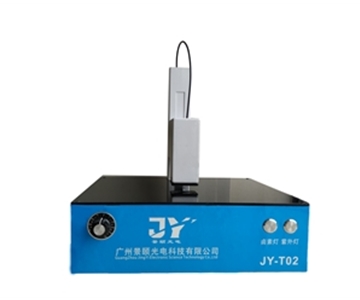
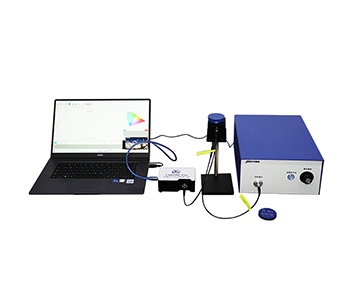
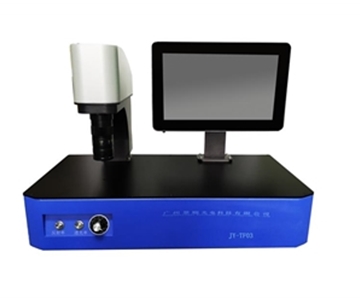
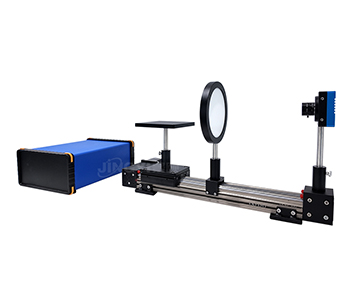
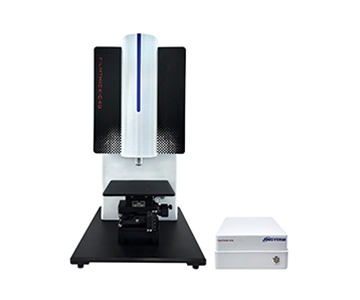
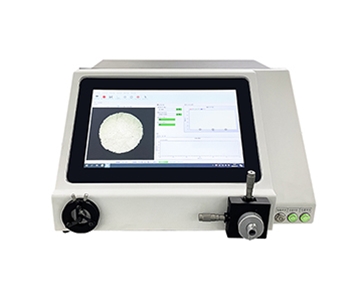
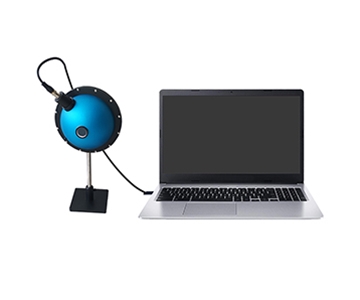
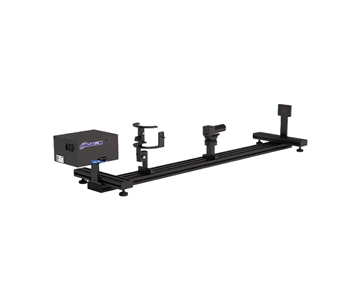
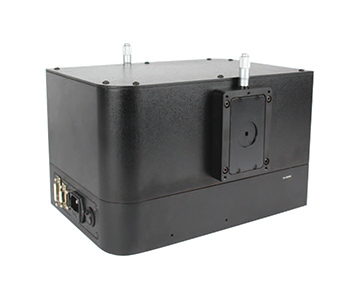
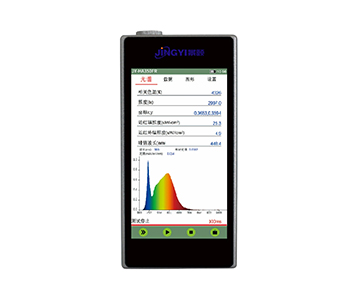
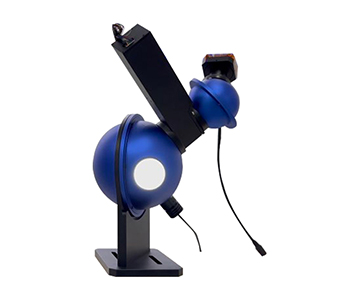
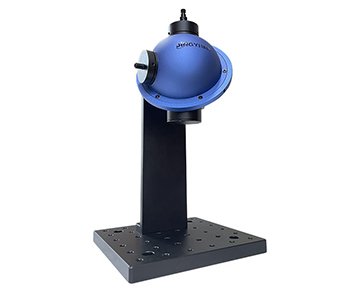
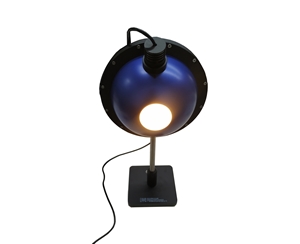
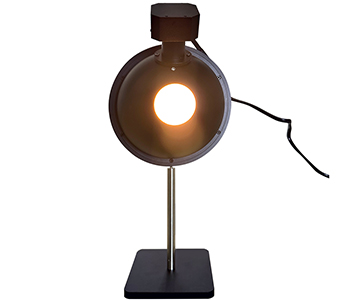
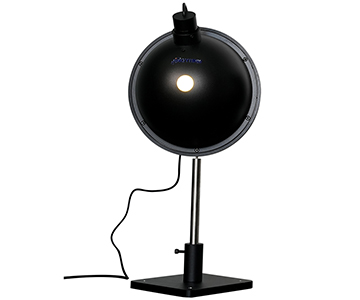
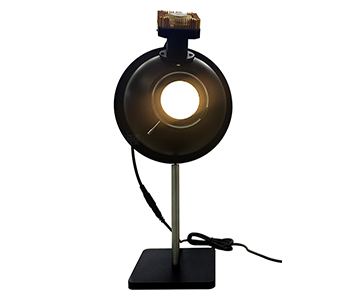
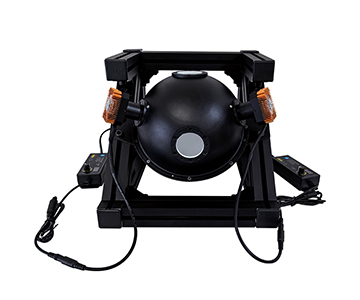
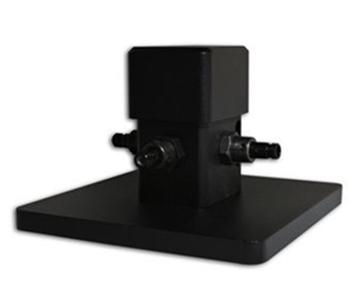
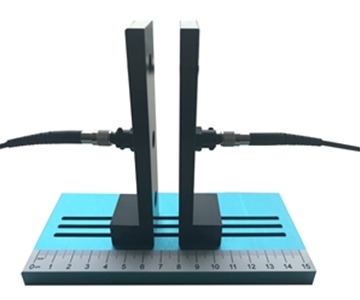
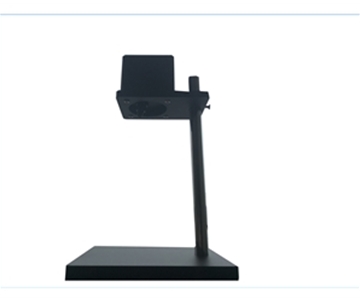
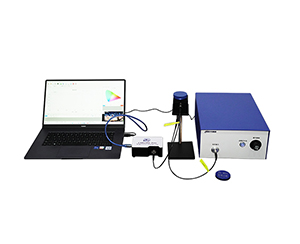
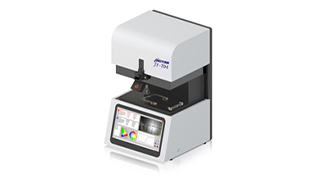
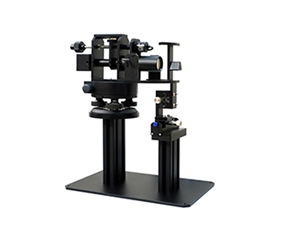
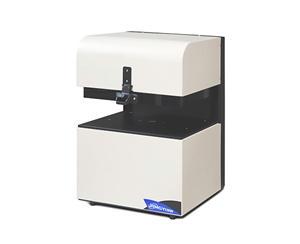
Figure 2: Typical bench deployment of the visible-light architecture in an optical laboratory, paired with the 2D/3D pseudo-color contour display for beam quality analysis.
3. Validation methodology: what was measured, and under which conditions
This section states the conditions under which the stated capabilities should be read. Without these conditions, a number such as "minimum detectable divergence angle below 0.1mrad" has no operational meaning.
Test conditions.
Specifications are given for operation at 23°C ±1°C unless otherwise stated. Pixel geometry calibration was performed on reference wafers; attenuator transmission values were taken from valid calibration certificates. Software version affects the exact implementation of the fitting algorithm, so all reported results should be re-confirmed against the version running in the user's own environment.
Sample size and statistical method.
Diameter and ellipticity values are derived from repeated frame captures on a stabilized beam, with the standard deviation across frames reported as repeatability. Centroid position is evaluated as the mean displacement over the same sequence. Sample counts and confidence intervals are recorded in the instrument's export files and should be retained as part of the qualification record.
What the validation does not establish.
The specifications in this document do not by themselves prove compliance with any particular end-user process window. They establish what the instrument can resolve. Whether that resolution is sufficient for a given coupling tolerance, radar range specification, or medical laser safety limit is a separate determination and must be made under the user's own process conditions.
This distinction is deliberate. It prevents a common procurement error: treating an instrument specification as a process guarantee. The two are related, but only traceable measurement can connect them.
4. Calibration traceability: three links, not one
The reliability of a beam quality result depends on a closed loop of three links: calibration of detector pixel geometry, valuation traceability of attenuator transmission, and verification of computational consistency in the software. Breaking any one of them breaks the chain, even if the other two are impeccably calibrated.
Pixel geometry.
The large-format architecture's claimed ability to resolve a 29µm beam rests on a 2.9×2.9µm pixel. That ten-to-one sampling ratio is necessary but not sufficient: pixel size must itself be calibrated against a referenced standard. An uncalibrated pixel is merely a nominal dimension, and a nominal dimension cannot support a traceable measurement.
Attenuator transmission.
At input powers in the 1000W class, the attenuator is not an accessory but part of the measurement. Its transmission ratio must carry a valid calibration certificate, and the certificate's validity period must be tracked inside the laboratory quality management system. An expired certificate is a traceability gap, not a paperwork issue.
Algorithmic consistency.
Identical raw frames must produce identical fitted results across software versions and across hosts. This is the easiest link to overlook because it requires no hardware, and the easiest to lose during a version update. Version control of the analysis software should therefore be treated as a metrology record, not an IT preference.
The instrument's 12-bit digitization depth and calibrated pixel geometry together form the technical basis for meeting the requirements set out in T/CIET 2298-2026,
Calibration Specification for Thin-Film Interference Thickness Measurement Systems
, for which Jingyi Optoelectronics served as a drafting unit. The standard defines the metrological value transfer requirements for optical measurement systems. It is referenced here as the calibration framework, not as a claim of automatic compliance.
Angle measurement and standards alignment.
The large-format architecture specifies a minimum detectable divergence angle below 0.1mrad, a value that corresponds to the ability to resolve small angular changes in far-field measurement and is traceable to the angle metrology reference. For automotive lidar applications, conformance with T/CITS 231-2025,
Technical Requirements for Vehicle-Mounted Lidar
, should be confirmed during selection: that standard sets explicit test requirements for the beam divergence characteristics of automotive lidar emitters, and a complete traceability chain depends on it.
5. Architecture comparison and application mapping
The table below consolidates the four architectures on the metrics that actually drive selection. "Best" is intentionally absent; the correct choice is the one whose constraints match the process.
Architecture
Detector
Wavelength
Pixel size
Beam range
Resolution
Max frame rate
Entry visible
CMOS
400-1100nm
2.9×2.9µm
29µm-4.4mm
2048×2048
—
Large-aperture
CMOS
200-1100nm
11×11µm
110µm-22.5mm
2048×2048
—
Infrared
InGaAs
400-1800nm
5×5µm
50µm-4.5mm
1280×1024
—
Large-format VIS
CMOS
400-1100nm
2.9×2.9µm
29µm-200mm
2688×1520
90fps
Large-format NIR
CMOS
400-1100nm
—
to 200mm
640×512
400fps
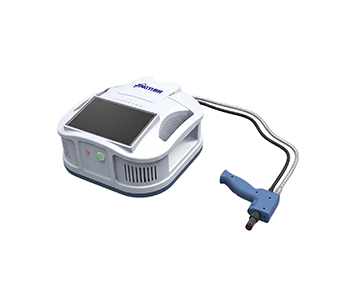
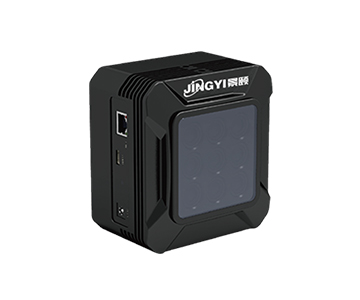
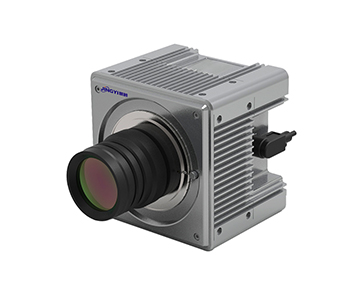
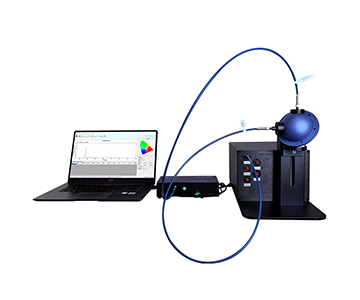
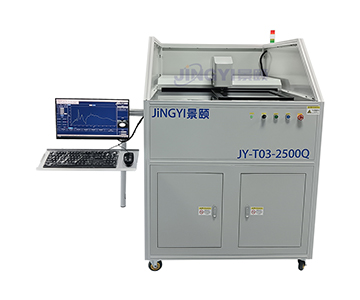
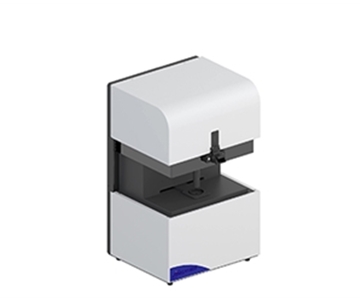
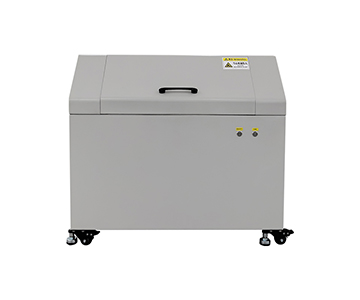
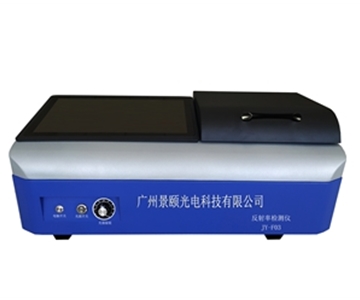
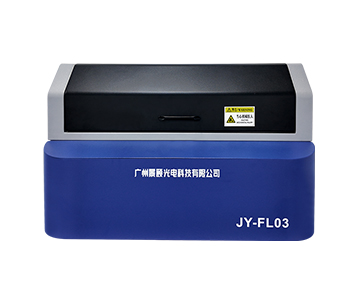
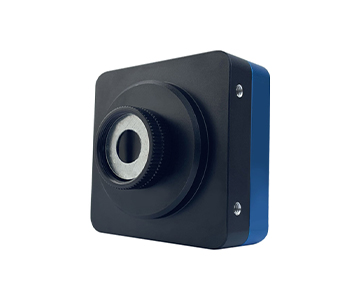
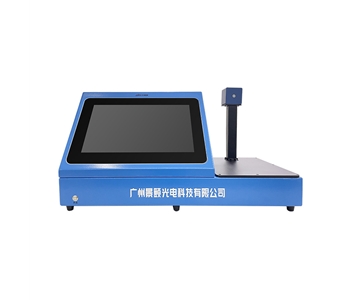
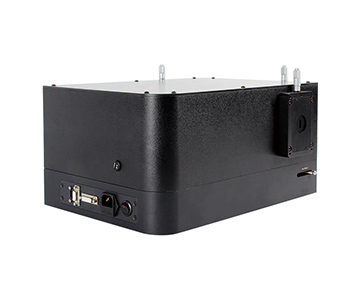
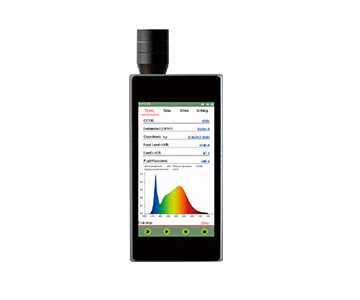
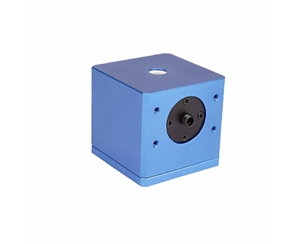
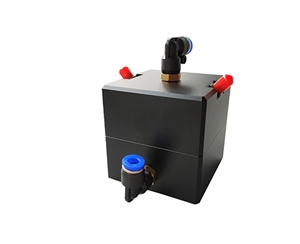
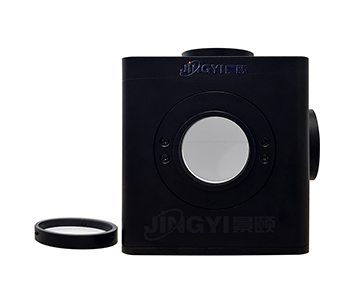
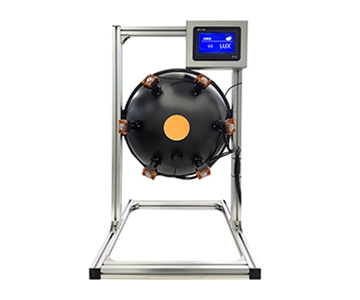
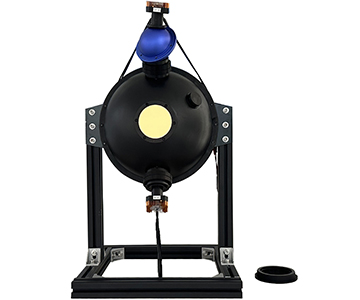
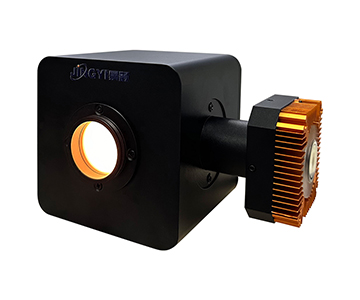
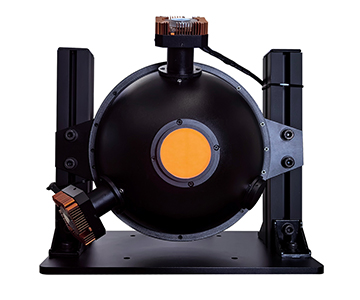
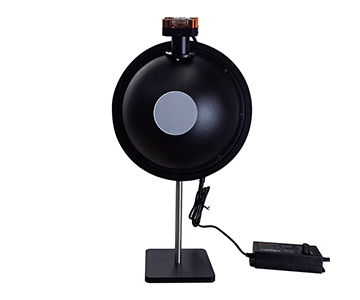
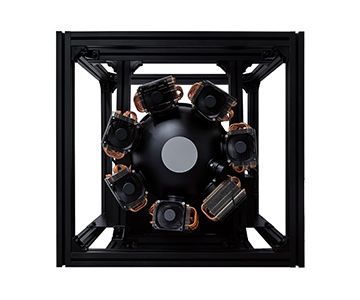
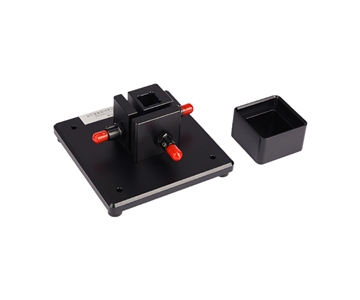
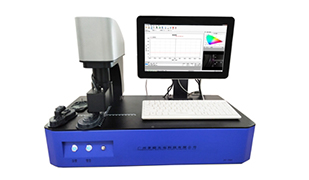
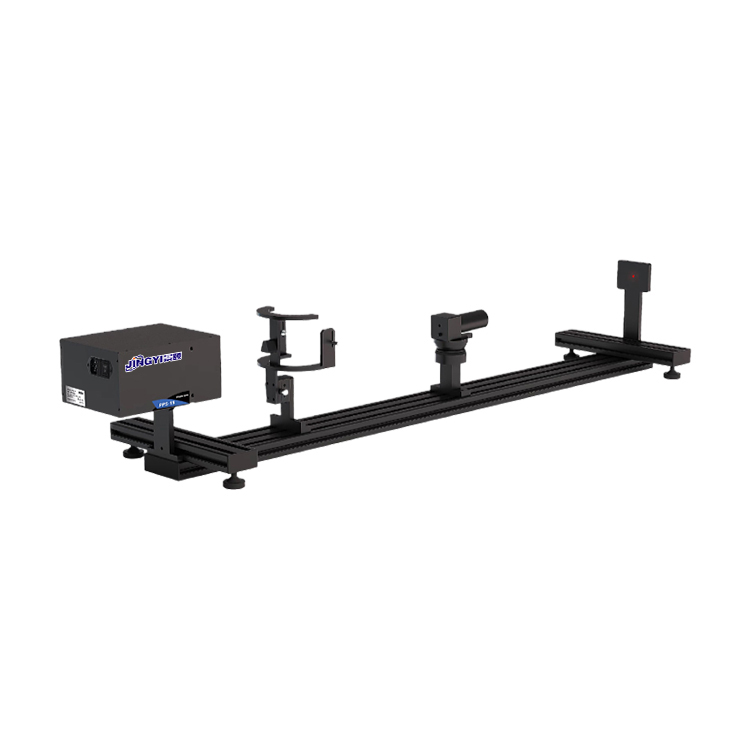
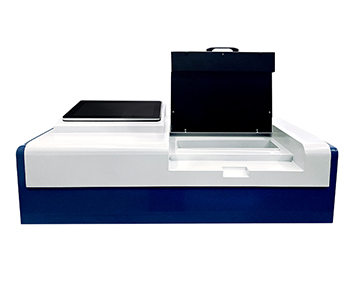
Figure 3: Front view of the large-aperture architecture, showing the mechanical realization of the 2-inch CMOS sensor and the 22.5mm×22.5mm clear aperture.
The application mapping is a direct derivation from these technical functions and does not reference any specific enterprise case.
Industry
Measurement object
Process step
Technical contribution
Result for the user
Semiconductor
Laser spot
Fiber alignment and coupling
Ellipticity analysis, mode defect detection
More consistent coupling efficiency
Optical communications
Output fiber spot
Line commissioning
Beam analysis, power fluctuation monitoring
Shorter commissioning cycles
Biomedical
Medical laser spot
Optical inspection
InGaAs infrared imaging, pointing stability
Eye-safety assurance
Automotive electronics
Lidar transmit spot
External optical path alignment
Divergence angle, centroid analysis
Supports ranging accuracy
Aerospace
Far-field beam
Laboratory R&D
Large-aperture 22.5mm clear aperture
Covers large-divergence-angle scenarios
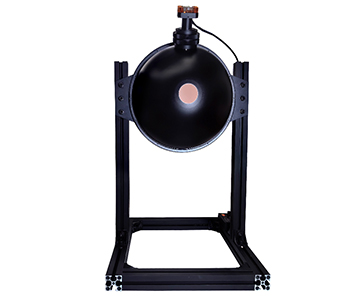
One specification deserves separate attention: the large-format architecture's 200mm upper detection limit. In far-field measurement, that number means the full angular spread of a diverging beam can be captured without moving the detector. Removing the mechanical re-positioning step removes the repeatability error that repositioning introduces. For a process engineer at a GaN fab in Arizona, that distinction showed up during a night shift as the difference between a stable centroid record and one that drifted with every fixture adjustment.
6. Selection guide: a decision tree based on process constraints
Step 1 — Wavelength.
This is the only hard branch. If the measurement band contains components above 1100nm, the selection enters the InGaAs branch; a CMOS-only architecture has no response there. If the entire band lies in the visible, proceed to beam size.
Step 2 — Beam diameter.
Below 4.5mm, the entry visible or infrared type meets sampling density requirements. Between 4.4mm and 22.5mm, the large-aperture type is required. At beam sizes that may extend to 200mm, only the large-format architecture applies.
Step 3 — Dynamic performance.
Large-format VIS supports up to 90fps; the NIR configuration reaches 400fps for capturing fast power fluctuations, while the UV configuration at 30fps is oriented toward predominantly steady-state measurement.
Step 4 — Compliance and calibration.
Verify that the attenuator transmission certificate is current and that pixel geometry calibration is documented. For automotive lidar use, confirm conformance with T/CITS 231-2025 and retain both certificates as part of the procurement record. ISO/IEC 17025-aligned laboratory practice is the practical reference point for how those records should be maintained.
Step 5 — Cost tier.
The three tiers map to the architecture split rather than to arbitrary price points: a $50K-class entry visible system for sub-5mm beams in the 400-1100nm range; a $100K-class large-aperture or infrared configuration for the mid-range and 1550nm requirement; and a $200K+ tier for the large-format 200mm far-field capability. These are planning brackets, not quotations, and should be reconfirmed against current configuration pricing.
Step 6 — Proof of concept.
A desktop demo is not a qualification. The POC should reproduce the actual beam path, including the attenuator stack and the host PC, and should run for a full shift to expose thermal and drift behavior. Retain the export files.
Step 7 — The ten questions to ask before signing.
What is the shortest wavelength in the actual beam? What is the largest beam diameter including worst-case divergence? Is the 1550nm band present at any stage? What is the attenuator's current certificate validity? What is the required frame rate versus resolution trade-off? Does the software version match the one used for this quotation? Is external trigger supported in the existing line control architecture? What is the repeatability over a full shift, not over ten frames? Is angle calibration traceable? And finally: who inside the organization owns the recalibration schedule?
7. Honest limitations: where the current product matrix stops
The spectral and aperture boundary.
The InGaAs architecture extends response to 1800nm, but its clear aperture is 6×4.5mm with an upper measurable beam range of 4.5mm. The implication is direct: for infrared measurement of large spots, there is a hard capability boundary. Covering both the infrared band and beam sizes above 22.5mm with a single configuration is not possible in the current matrix. The workaround is indirect—attenuation plus segmented measurement—and it introduces additional uncertainty that must be quantified during the POC rather than estimated afterward.
Frame rate versus resolution.
The large-format NIR configuration reaches 400fps, but at 640×512 resolution, well below the VIS configuration's 2688×1520. There is no single configuration that delivers both extremes. When a process window demands both high frame rate and high spatial resolution, the priority must follow the constraint: if spatial detail defines the acceptance limit, protect resolution; if the task is capturing fast power fluctuations, choose frame rate. Calling this a limitation is not a caveat. It is the engineering decision the buyer is paying for.
8. Frequently asked questions
Q1: What is the measurement reference for beam diameter, and how are major- and minor-axis differences distinguished?
The system computes beam diameter separately for the major and minor axes and for the X/Y directions, and outputs ellipticity synchronously. Ellipticity reports the divergence difference between two orthogonal axes and is a direct indicator of collimator assembly quality. The exact algorithm implementation depends on the software version; refer to the version-specific documentation.
Q2: How does the infrared architecture's cooling range affect measurement stability?
The infrared architecture specifies cooling to 10°C below ambient, with an operating temperature range of -20 to 60°C. The cooling design reduces detector dark noise. Outside that temperature range, measurement repeatability should be re-confirmed through on-site calibration rather than inferred from the specification.
Q3: How are pass/fail settings integrated with an automated production line?
The system supports statistical analysis of parameters, record export, and report generation; pass/fail settings provide the threshold interface for line judgment. The integration method depends on the user's line control architecture.二次开发 via the USB3.0 data output protocol is the recommended route, and the interface specification should be confirmed with the control system supplier before commitment.
Q4: How should the trade-off between frame rate and resolution be weighed against cost?
Large-format VIS offers 90fps at 2688×1520; NIR offers 400fps at 640×512. If the process window is more sensitive to spatial detail, resolution takes priority. If the requirement is capturing fast power fluctuations, the high-frame-rate configuration is the correct choice. Cost enters only after the constraint has been identified—optimizing the wrong parameter saves money on the wrong specification.
Q5: How can I independently verify long-term measurement consistency?
Periodically check pixel response uniformity using a reference light source, and compare the attenuator transmission ratio against the validity period of its calibration certificate. The check interval should be written into the laboratory quality management documentation; the appropriate period is determined by the organization's own metrology management procedures, not by a generic recommendation.
9. Outlook and conclusion
Beam quality analysis is moving toward multi-sensor fusion and intelligent algorithms. The parallel existence of CMOS and InGaAs detector routes in the current product matrix reflects a long-running tension between spectral coverage and cost. If a single platform can eventually combine broad spectral response with large-format detection, the selection decision becomes considerably simpler.
For the present, the four architectures listed in this document cover measurement requirements from 29µm to 200mm across the 400-1800nm band. Selection should start from deterministic process parameters—wavelength range determines the detector route, beam size determines the target format, dynamic characteristics determine the frame rate configuration—rather than from generalized performance claims.
For detailed specifications and application notes on laser beam profilers, search "Jingyi Optoelectronics laser beam profiler" or visit the technical library.
About This Guide
Data Sources
: Product specifications as listed in this document; T/CIET 2298-2026
Calibration Specification for Thin-Film Interference Thickness Measurement Systems
; T/CITS 231-2025
Technical Requirements for Vehicle-Mounted Lidar
; SEMI 2025 Annual Report; Chinese Optical Society technical white paper on beam quality evaluation.
Author
: Cai Xiaodong, Senior Application Engineer, Jingyi Optoelectronics — 12 years in industrial precision optical measurement equipment.
Disclosure
: Jingyi Optoelectronics manufactures laser beam profilers and optical metrology equipment. This article presents technical assessments based on published specifications and publicly available industry information. No compensation was received from any third-party brand mentioned.
Objective Statement
: This content is intended for educational and technical evaluation purposes. Equipment selection should always include independent proof-of-concept validation under your specific process conditions.
Last Updated
: September 2026
Reference Information
Breadcrumb structure
: Home / Resources / White Papers / Laser Beam Profiler: Detector Architectures & Calibration Traceability
Article Schema author
: Cai Xiaodong, Senior Application Engineer, Jingyi Optoelectronics