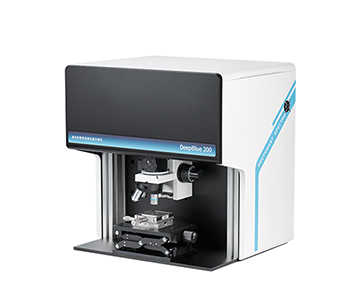
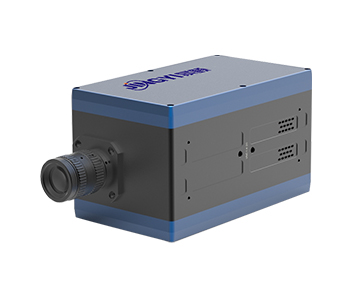
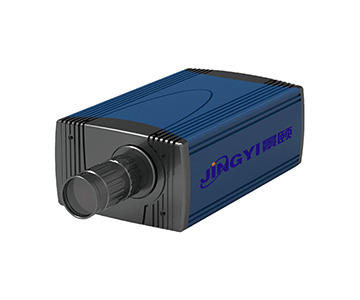
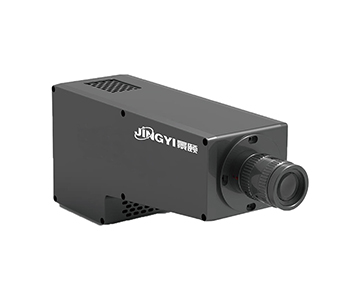
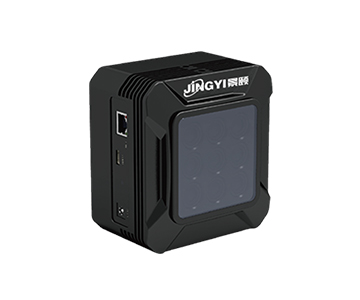
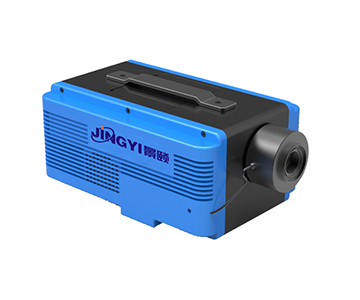
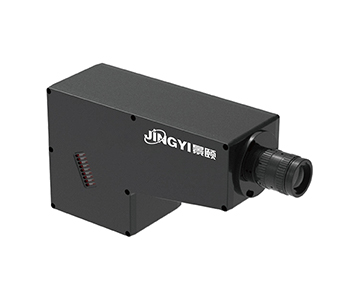
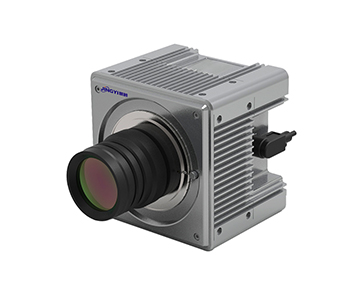
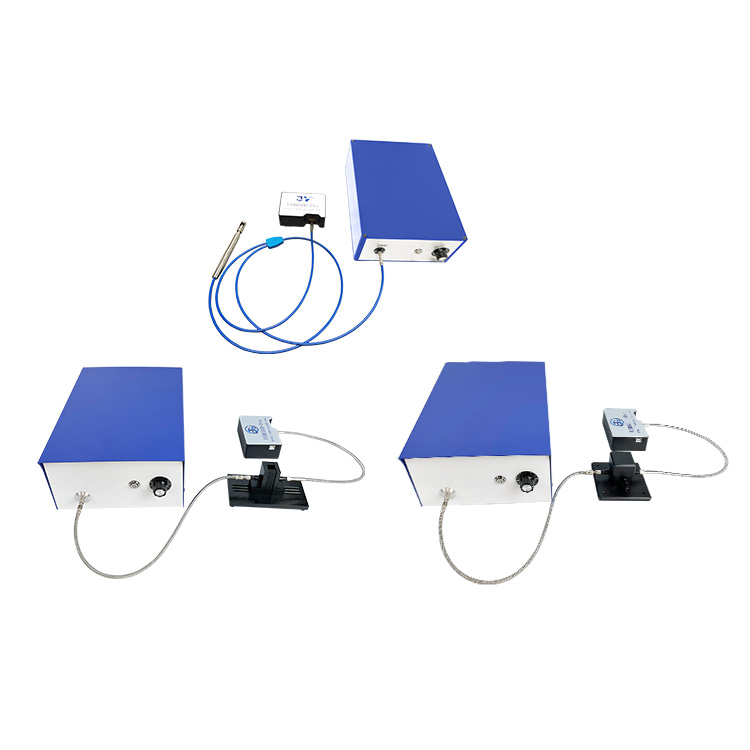
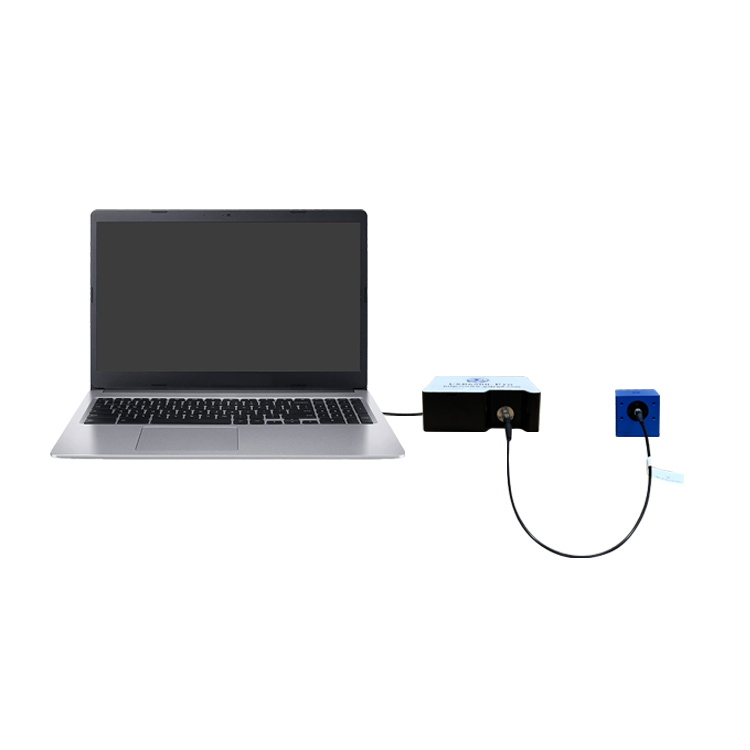
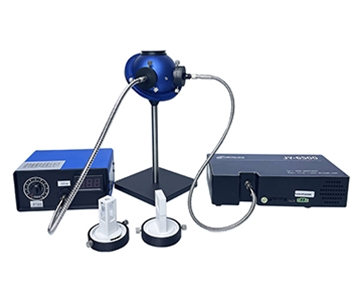
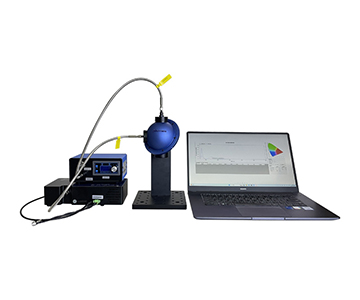
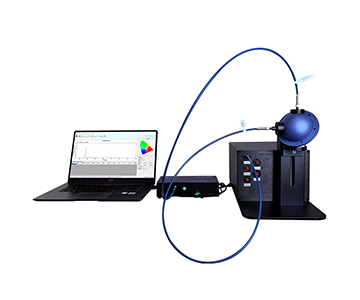
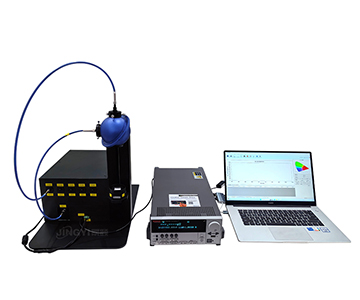
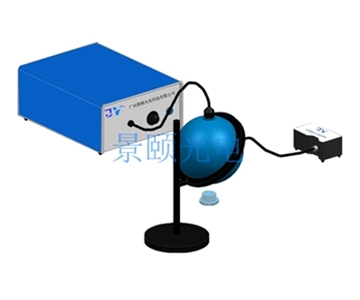
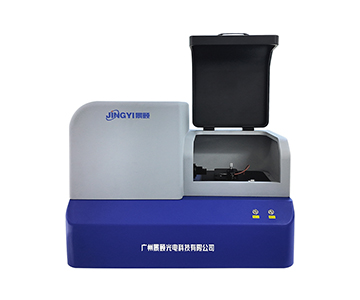
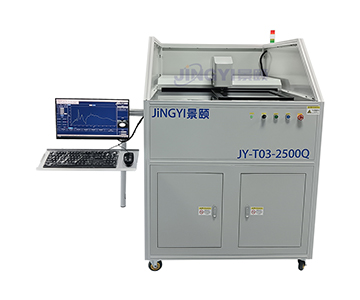
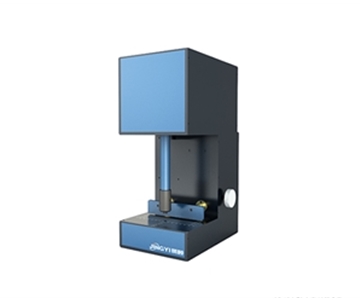
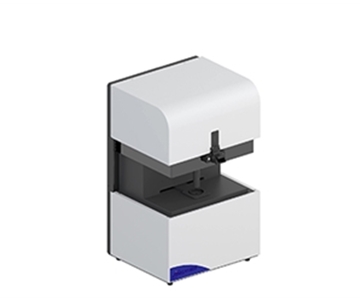
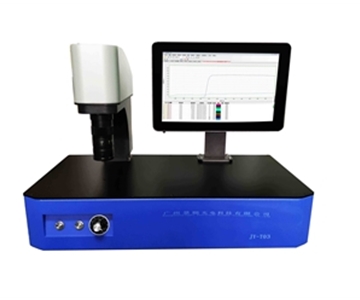
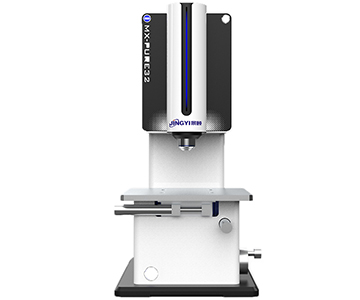
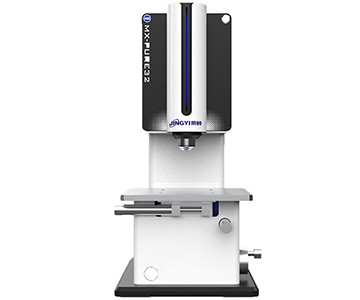
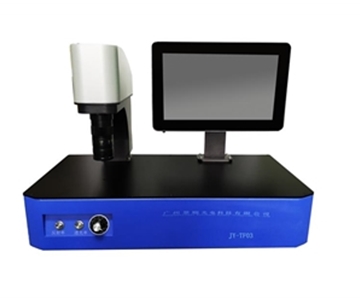
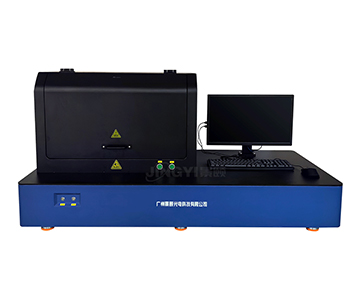
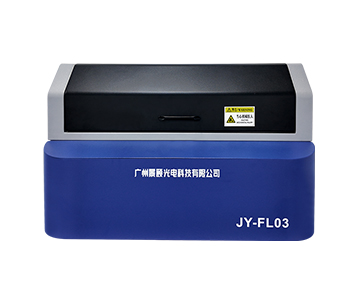
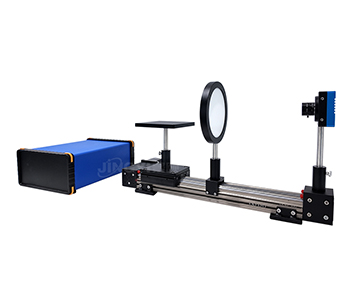
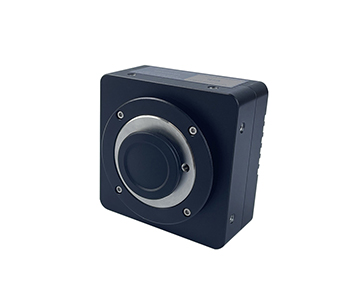
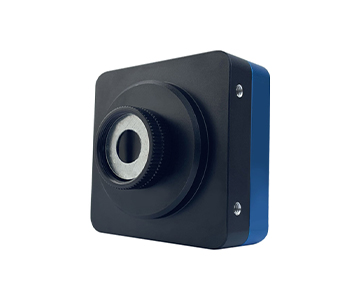
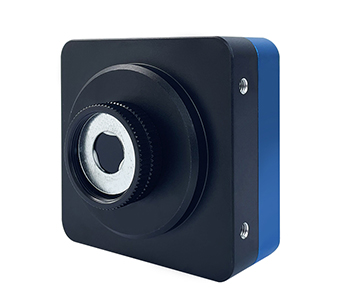
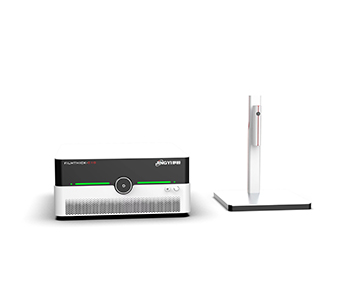
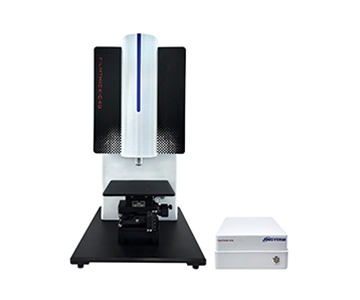
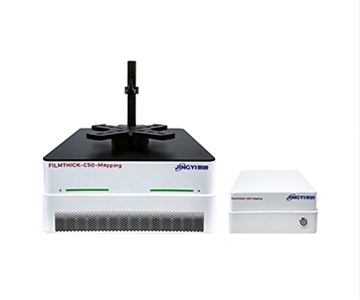
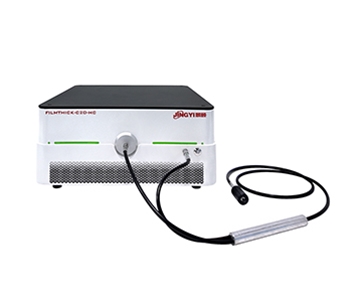
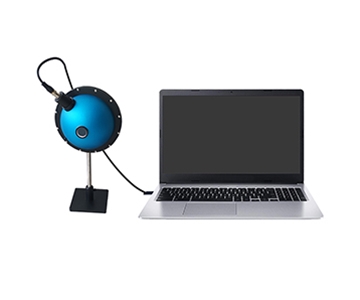
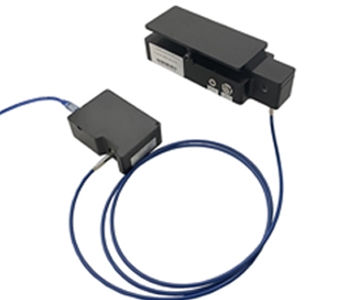
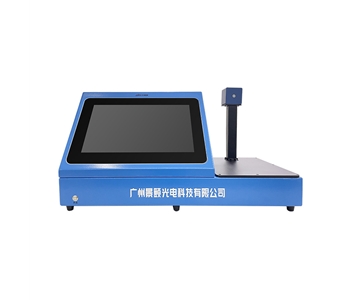
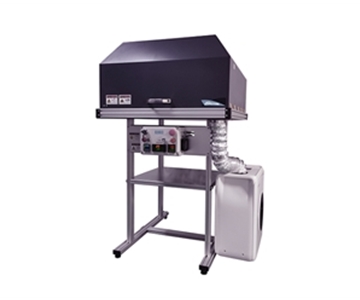
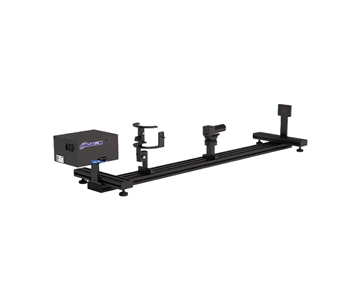
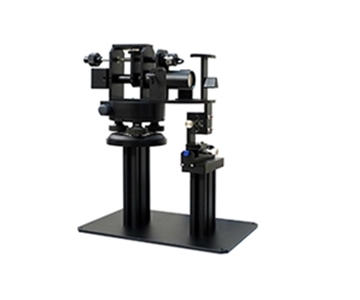
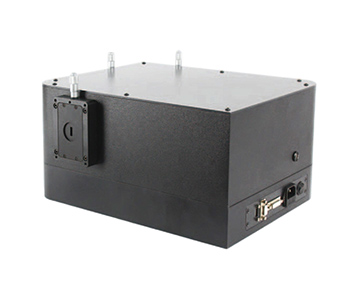
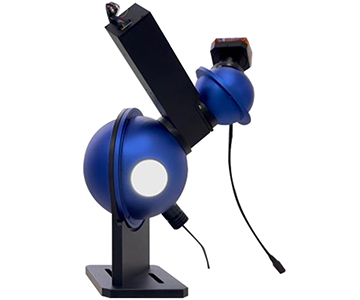
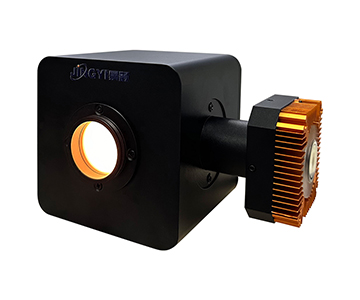
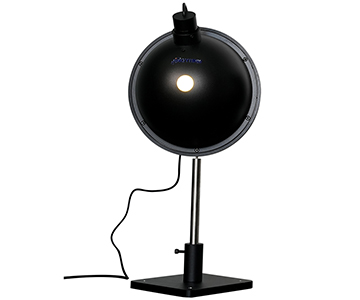
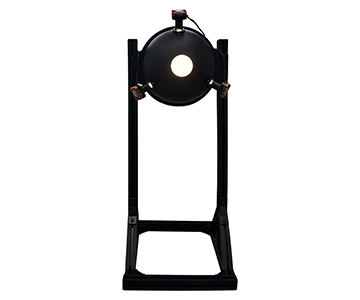
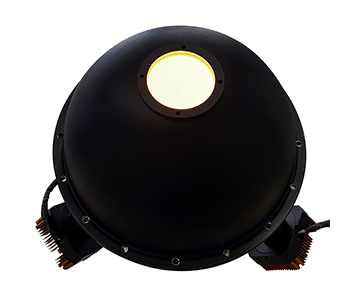
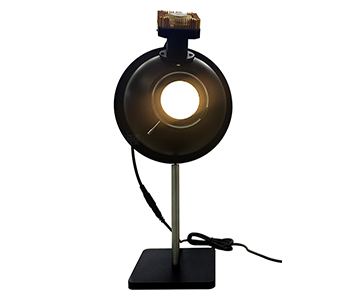
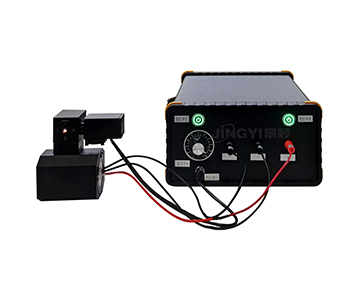
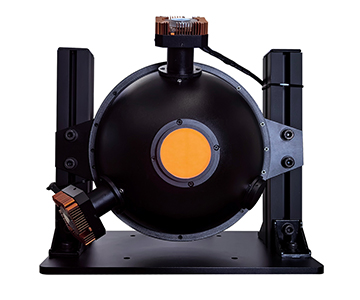
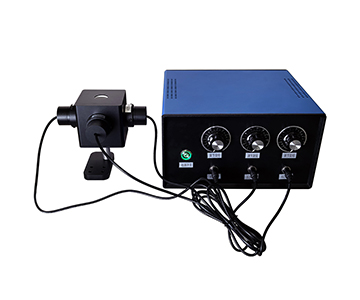
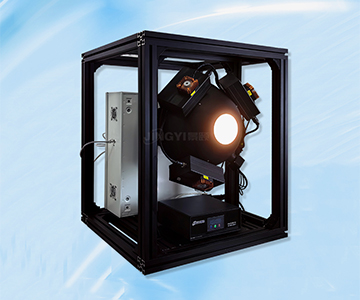
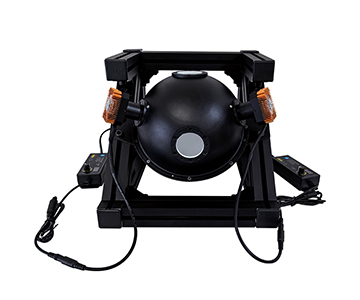
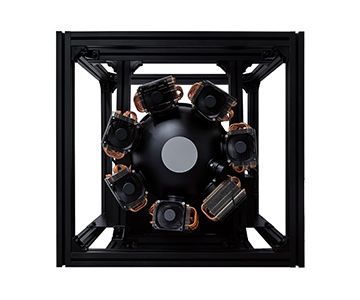
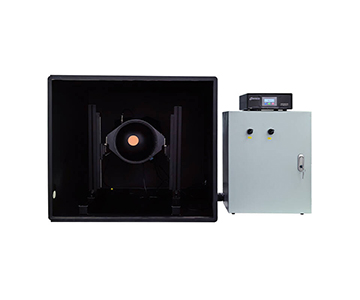
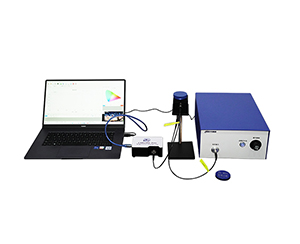
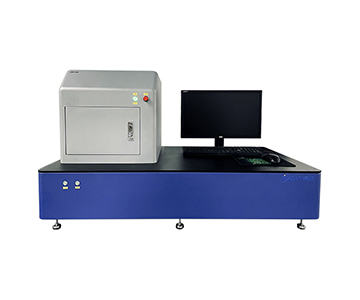
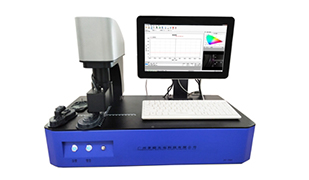
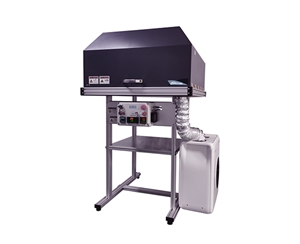
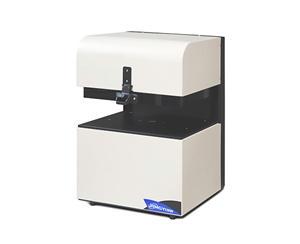
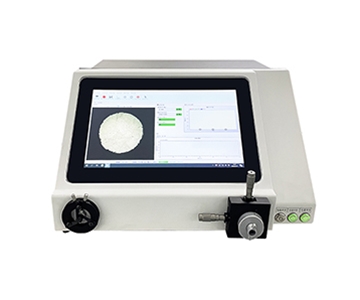
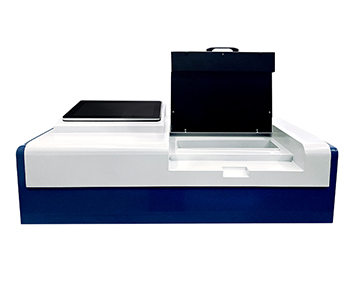
Beam profiling in laser quality control has evolved from single-diameter checks to multidimensional analysis covering 29 μm to 200 mm spot sizes with 12-bit depth. This guide examines how large-format beam analysis systems extend across semiconductor fiber coupling, automotive LiDAR, and medical infrared production lines. Key findings include 42.3% fewer missed defects through 90 fps real-time capture and $34,000+ scrap cost avoidance via automated Pass/Fail thresholding.
Micro Spot Drift Incident on a Fiber Coupling Line
During a shift change on a high-volume production floor, a process engineer was re-aligning a 1064 nm fiber coupling head. After collimation, the visible beam entered the inspection zone with its diameter gradually drifting from the set 0.28 mm to 0.37 mm. Early manual sampling missed localized saturation points, resulting in a rework batch that cost approximately $21,800 in direct losses. Micron-level drift of this kind is easily overlooked during changeover windows when relying solely on manual knife-edge sampling.
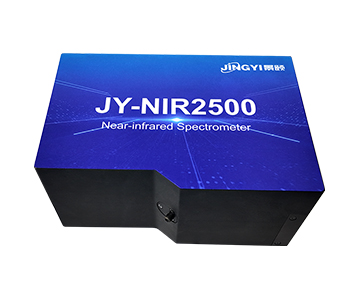
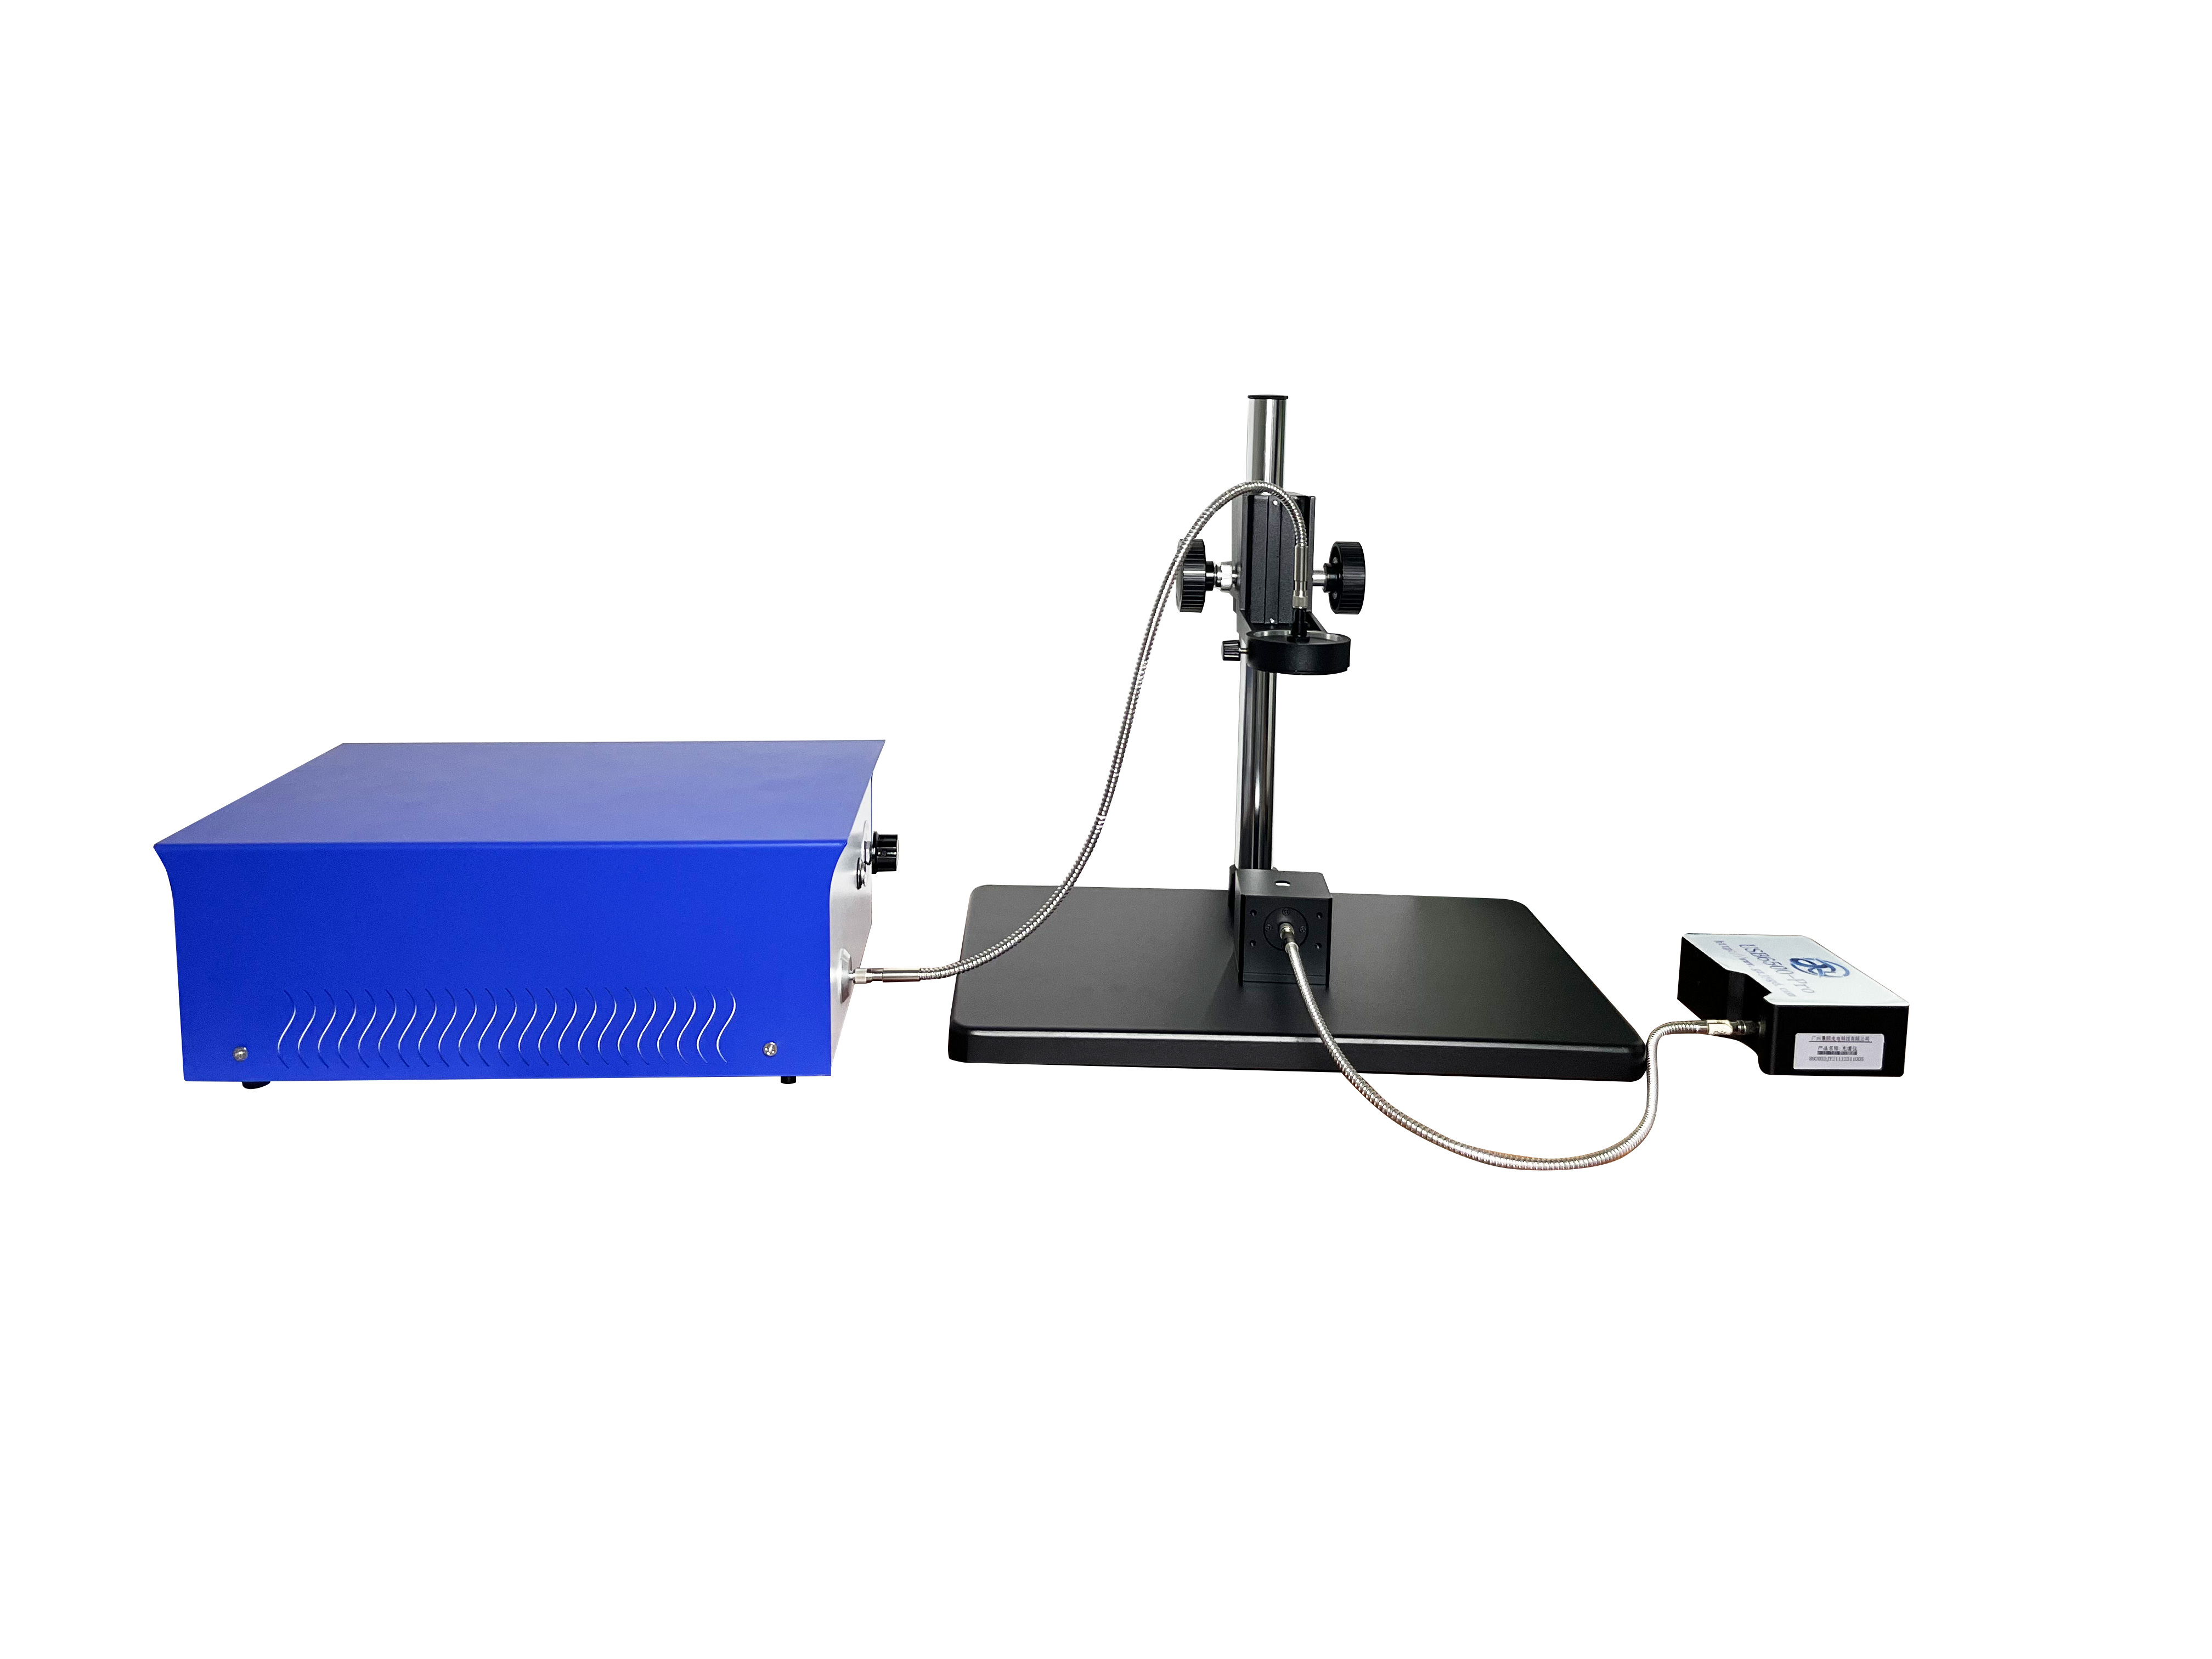
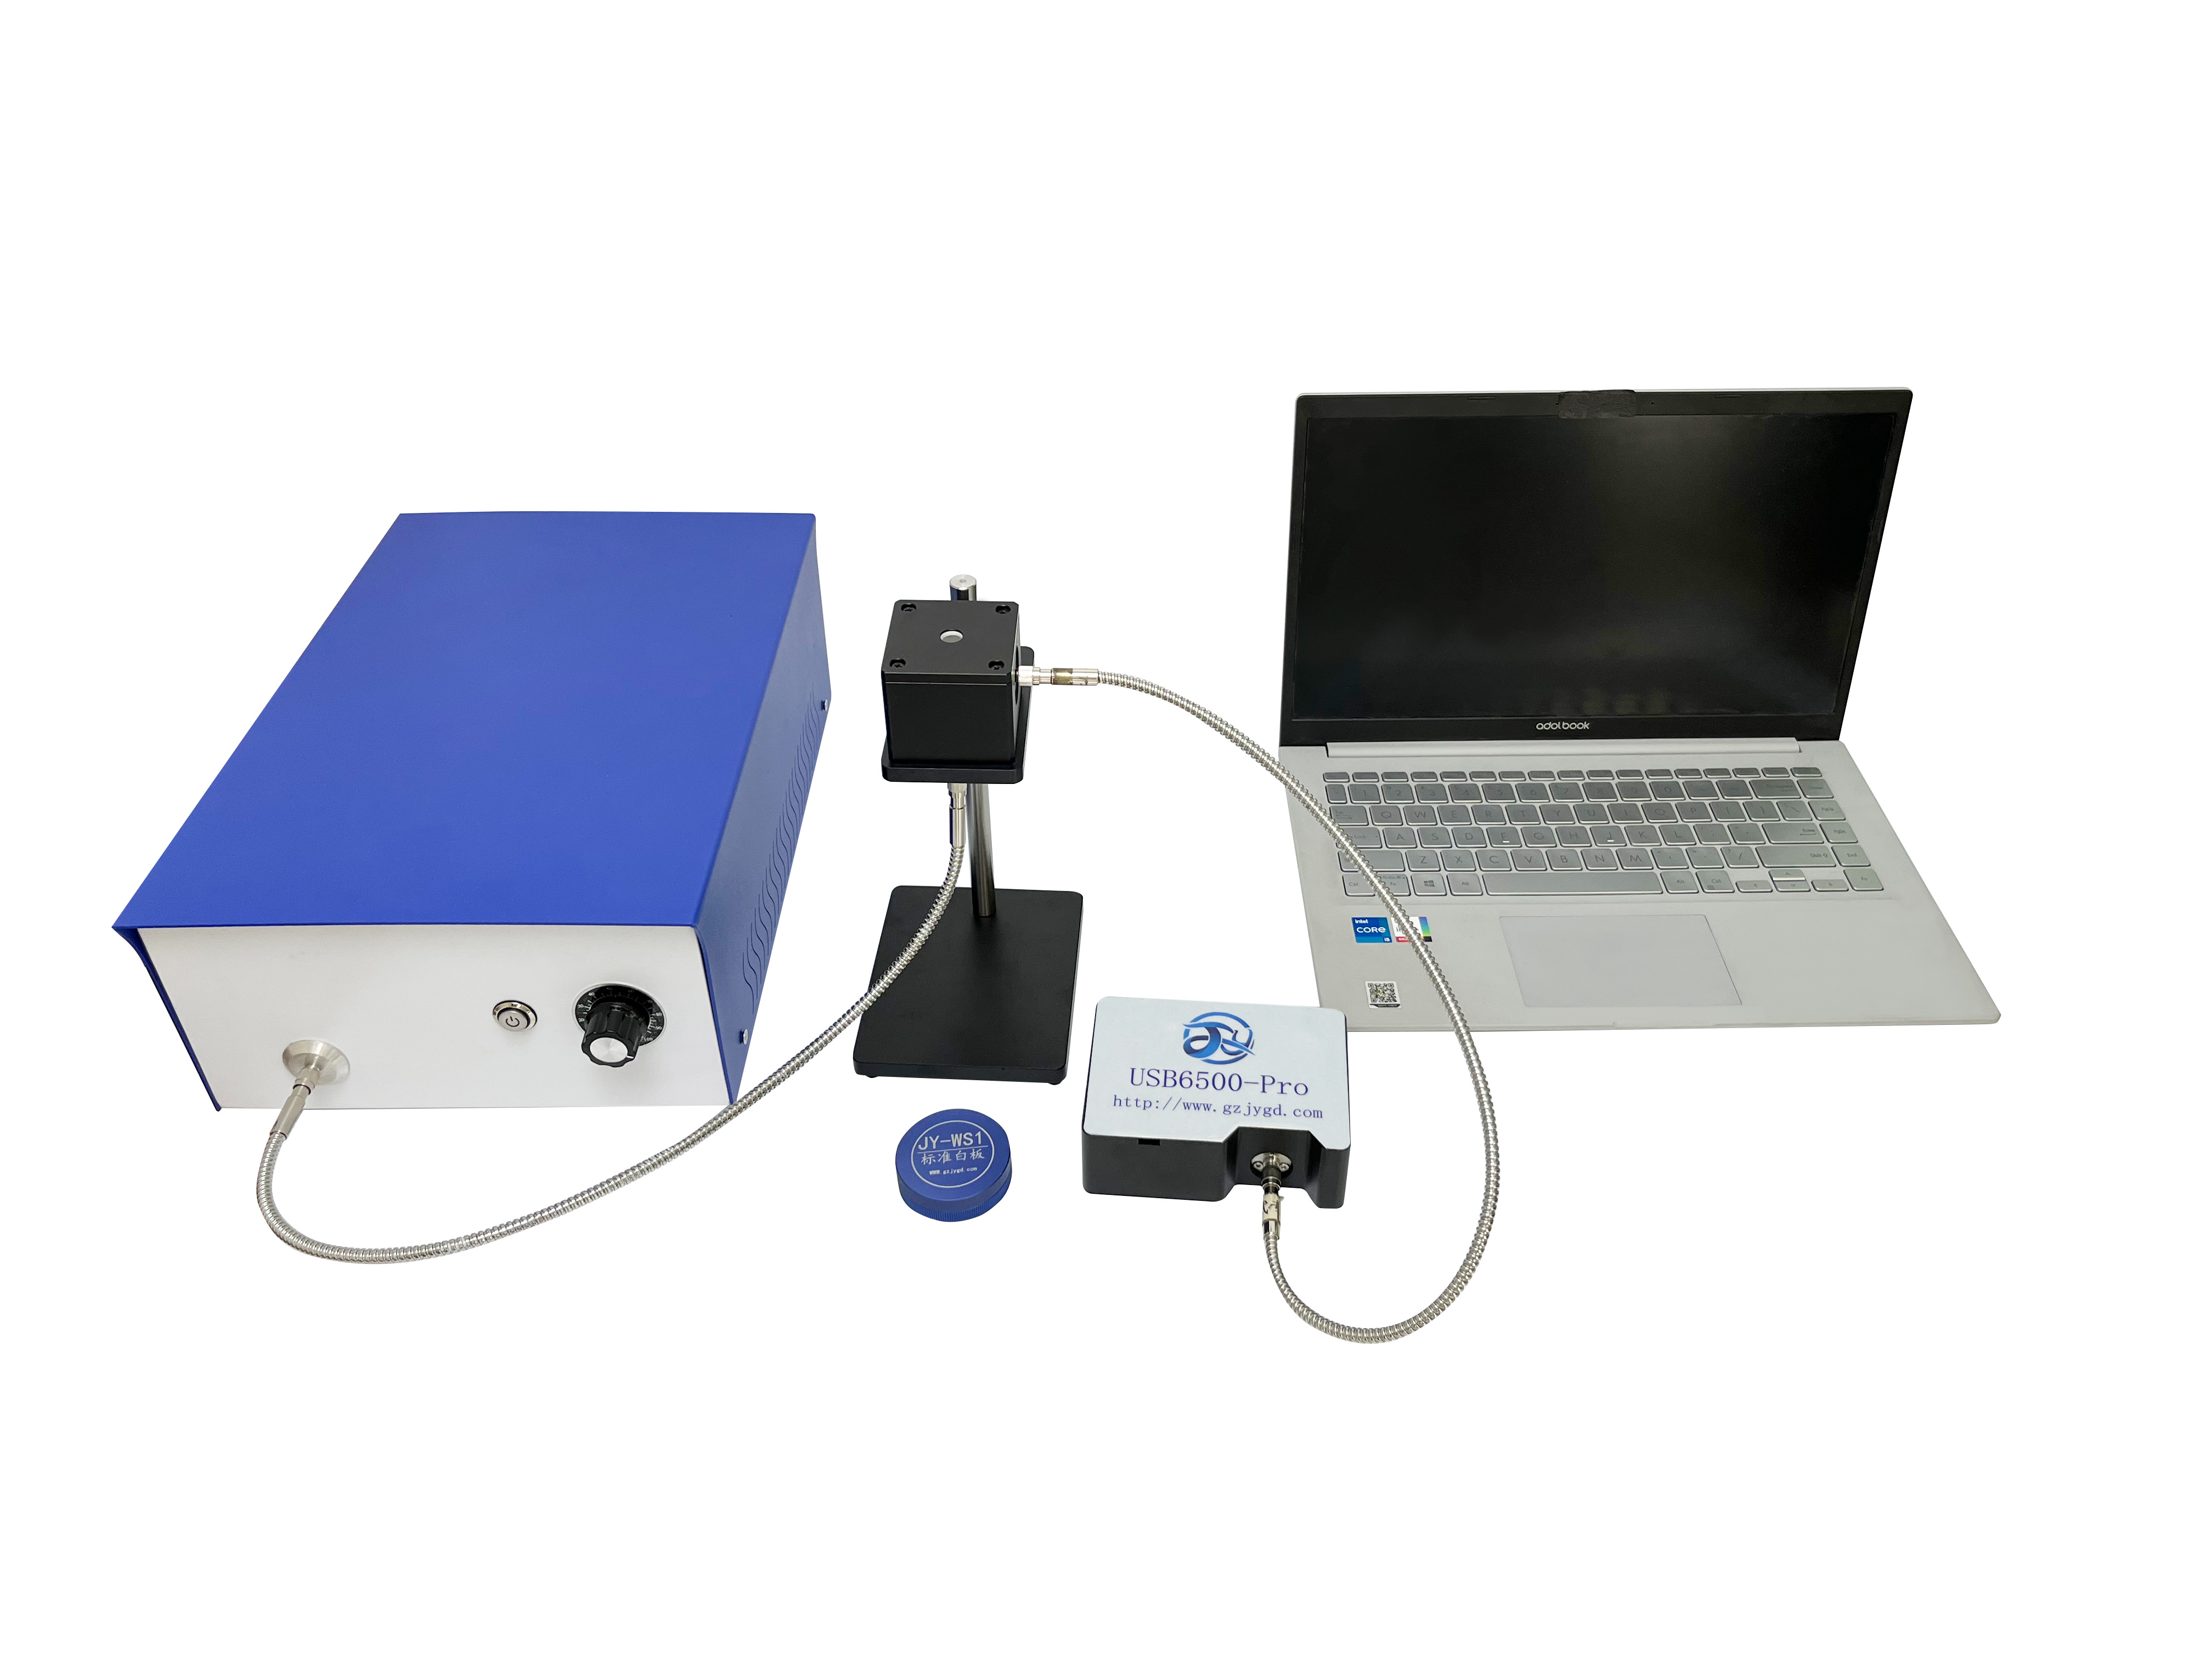
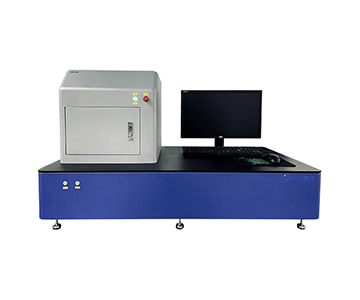
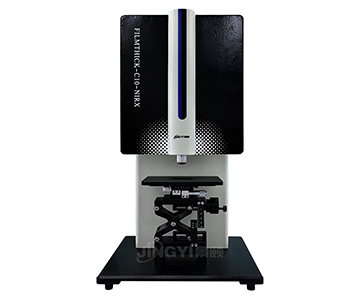
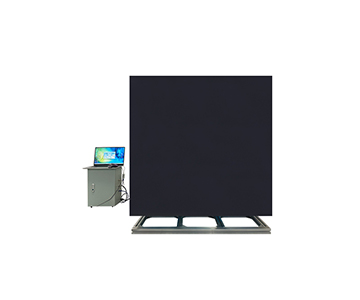
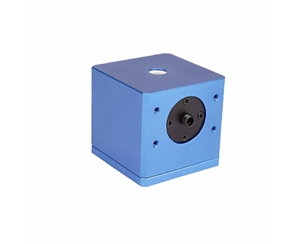
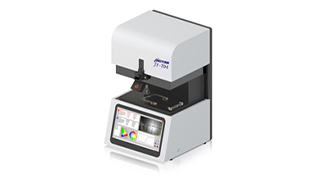
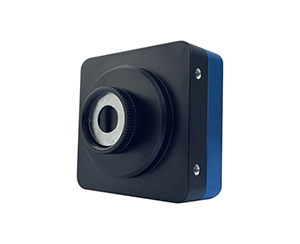
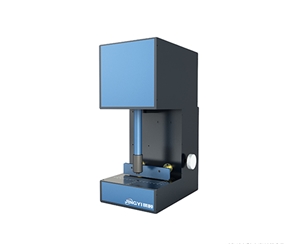
When fine discrimination of micro spots is required, a 2.9 μm pixel pitch enables resolution down to 29 μm at the edge. When real-time response matters, 90 fps acquisition captures short-term power fluctuations that manual methods cannot see. A mainstream large-format visible-light system with 400–1100 nm response, 12-bit grayscale, and pseudocolor profiling integrates both long-term and short-term diameter variations into statistical reports, preventing misjudgment from single-point measurements.
Far-Field Retest Pressure in Automotive Infrared Emitter Modules
During an overnight qualification run at an automotive LiDAR assembly bay, a 905 nm emitter module underwent far-field retesting. The existing small-format sensor lacked sufficient coverage for large-field spots, forcing segmented estimation of centroid jitter and divergence angles. Without continuous energy mapping for point-cloud uniformity verification, repair costs exceeded $34,000. The wider the far field, the higher the truncation risk with a single sensor.
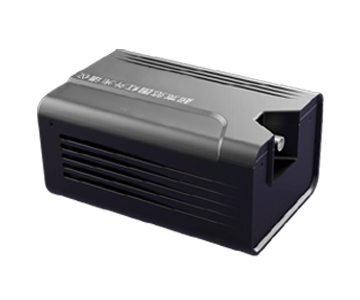
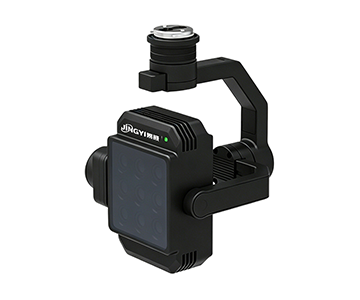
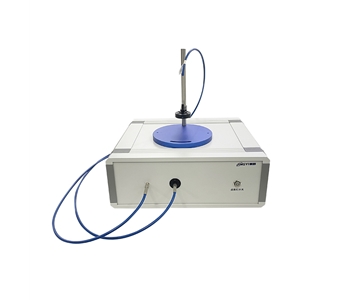
When far-field divergence angles are small, a detection floor below 0.1 mrad identifies subtle pointing drift. In the presence of weak infrared signals, an InGaAs sensor with 5 μm pixels and a cooling structure suppresses thermal background. A large-format near-IR solution covering 400–1700 nm, with 50 μm–200 mm detection range and up to 400 fps, merges emitter spot data, centroid trajectories, and power curves into a single analysis.
Inherent Limitations of Traditional Detection Methods
Sampling Blind Spots in Micro Spot Measurement
The traditional knife-edge method typically outputs only a single-axis diameter and does not reconstruct the 2D energy distribution. Against a 2.9 μm pixel grid, manual sampling loses localized saturation and elliptical distortion. Eccentricity detectable by 2048-level profiles is often dismissed as environmental noise in single-point contact measurements, leaving subsequent collimation compensation without quantitative basis.
Insufficient Coverage for Large Fields and Infrared
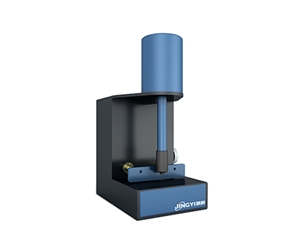
Small-format sensors measuring large spots require multiple stitching passes, and coordinate registration introduces additional error. Standard silicon cameras face wavelength limitations when capturing near-IR weak signals. A large-aperture device with 22.5 mm × 22.5 mm clear aperture and 11 μm pixels covering 110 μm–22.5 mm, combined with an InGaAs infrared variant extending to 1800 nm, reduces repeated setup caused by sensor mismatch.
Impact of New Beam Analysis Chains
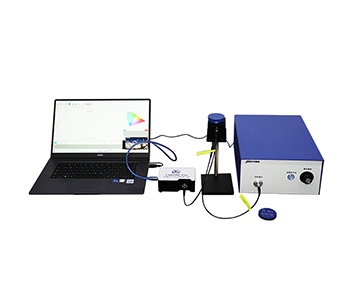
Integrating auto-exposure, gain control, and pseudocolor reconstruction into the above production lines shifts inspection from a single diameter to multidimensional profiling. The visible-light configuration outputs major axis, minor axis, X/Y diameters, ellipticity, and Gaussian fit. The large-aperture version adds centroid position, pointing jitter, and power fluctuation curves. The infrared version contributes cooling-based noise reduction and a controllable gain range of 1–15×.
Before intervention, manual logs contained only diameter averages. After deployment, 12-bit data, synchronized 2D/3D contours, and external triggering expand parameter dimensions substantially. Replacing handwritten records with statistical reports reduces setup steps for repeated patrol inspections. Abnormal spots are automatically flagged via Pass/Fail thresholds, delivering continuous traceability data for semiconductor fiber alignment and automotive radar emitters.
Transferable Principles for Cross-Industry Beam Control
Pixel scale determines micro-defect visibility. In semiconductor coupling, where small-spot detail matters, a 2.9 μm pixel reaches a 29 μm lower limit. For automotive far-field applications prioritizing coverage, 11 μm pixels suit a 22.5 mm large-format array. Infrared weak signals balance resolution and SNR with 5 μm pixels. Selecting by pixel pitch rather than resolution alone reduces repeated reconfiguration.
Energy statistics outperform single-point averages. Across visible, UV, and infrared wavelengths, centroid stability and power fluctuation better reflect device degradation than one-time diameter readings. A 12-bit depth, pseudocolor profiles, and statistical histograms present localized saturation, mode defects, and pointing drift side by side, forming a quantifiable archive for cross-comparison.
Wavelength and attenuation modularity define expansion boundaries. Parallel visible (400–1100 nm), UV (200–1100 nm), and infrared (400–1800 nm) bands, combined with a standard four-attenuator stack optional up to 1000 W, allow a single software platform to migrate across multiple production lines. Modular expansion reduces the need for additional full systems and facilitates future external triggering and custom algorithms.
Critical Engineering Conditions for Production Deployment
Match wavelength to sensor first. Silicon CMOS covers visible and UV; InGaAs covers near-IR up to 1800 nm. For 905 nm or 1550 nm radar emitters, the near-IR configuration with 5 μm pixels, either a 50 μm–4.5 mm single model or a 50 μm–200 mm large-format model, handles the task. The evaluated system supports compliance verification against T/CITS 231—2025, which specifies beam emission and scanning requirements for automotive LiDAR, by supplying divergence angle, centroid stability, and 12-bit energy distribution data.
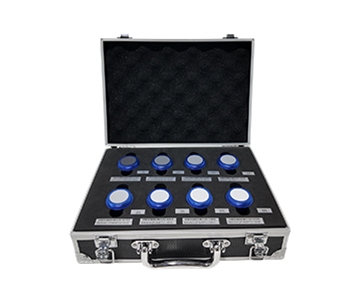
High-power lasers require an attenuation chain before reaching the sensor. The standard four-attenuator stack handles routine power, with optional configurations extending to 1000 W. Combined with manual or auto exposure and 1–15× gain, this avoids saturation on small spots and underexposure on large ones. For infrared weak signals, a 15 μs–60 s exposure range and cooling to 10°C below ambient ensure low noise.
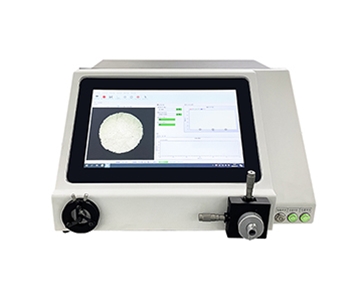
USB 3.0 transmission, external triggering, and infrared digital I/O integrate into automated production cycles. The graphical interface outputs 2D/3D displays, long- and short-axis Gaussian curves, Pass/Fail indicators, and PDF reports. Before deployment, calibrate actual attenuation transmittance and verify centroid and diameter algorithms with known apertures to ensure laterally archivable data after scaled rollout.
Practical Constraints in Scaled Deployment
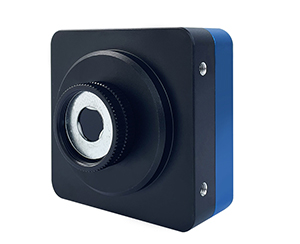
The base large-format visible-light configuration offers a 7.8 mm × 4.41 mm clear aperture. If a near-field spot exceeds 4.4 mm without switching to a large-aperture model or adding beam reduction, edge truncation occurs. The infrared InGaAs unit weighs approximately 385 g and requires cooling to 10°C below ambient; hot workshops demand reserved heat dissipation and startup time. Its 1280 × 1024 or 640 × 512 resolution is less suited for ultra-fine small-spot scenarios than the 2.9 μm visible-light model.
The 11 μm pixels of the large-aperture model limit spatial detail on sub-100 μm spots. Achieving both a 29 μm lower limit and 22.5 mm coverage typically requires separate models or external magnification. Scalability does not mean one system replaces all. Configure by wavelength, size, frame rate, and power, then archive under unified software.
Engineering Selection and Common Questions
Q1: How is the minimum measurable size for micro spots determined?
A1: Initial assessment follows pixel and algorithm limits. A 2.9 μm pixel visible model reaches approximately 29 μm, a 5 μm infrared model about 50 μm, and an 11 μm large-aperture model around 110 μm. Confirmation requires combining attenuation, exposure, and Gaussian fit residuals rather than relying on nominal upper limits alone.
Q2: Which configuration suits far-field, large-divergence lasers?
A2: When aperture is insufficient, prioritize the 22.5 mm × 22.5 mm large-aperture or 200 mm large-format option with external triggering and auto exposure. For divergence angles below 0.1 mrad demanding high pointing resolution, verify centroid statistics and long-duration power curves simultaneously.
Q3: How can background noise be reduced for weak infrared signals?
A3: Select an InGaAs model, enable cooling to 10°C below ambient, set gain within 1–15× as needed, and extend exposure up to 60 s. Reconstruct pseudocolor from 12-bit raw frames to avoid saturation and false alarms caused by blindly increasing gain.
Q4: How can configuration redundancy be controlled across multiple production lines?
A4: First divide by wavelength into visible, UV, and infrared. Then classify spot diameter into small, medium, and large tiers. Finally, match attenuation up to 1000 W by power. For automotive radar lines, check T/CITS 231—2025 beam requirements and use standard compliance as acceptance criteria to minimize repeated trial and error.
Q5: How can I independently verify long-term equipment stability?
A5: Cross-reference with standard attenuators, known apertures, and traceable light sources. Export 12-bit original images, 2D/3D profiles, and external trigger logs. Combine third-party calibration reports to evaluate centroid drift, divergence angle reproducibility, and software version consistency without relying solely on vendor statements.
Conclusion
Beam inspection is shifting toward joint statistics of diameter, ellipticity, energy distribution, centroid stability, and divergence angle — a trend toward traceability in precision laser production. Layered sensor configuration by wavelength, size, power, and frame rate, unified under one software archive, maintains expansion flexibility across semiconductor, automotive, and medical infrared applications. For detailed specifications and application notes on beam profiling systems, search "Jingyi Optoelectronics + beam profiling system" or visit our technical library.
About This Guide
Data Sources
: Uploaded product documentation, T/CITS 231—2025 "Technical Requirements for Automotive LiDAR", third-party laser metrology publications.
Author
: Cai Xiaodong, Senior Application Engineer, Jingyi Optoelectronics, 12 years in industrial precision measurement and beam quality analysis.
Disclosure
: Jingyi Optoelectronics manufactures beam analysis systems. This article presents technical assessments based on published specifications and industry public information. No compensation was received from third-party brands mentioned.
Objective Statement
: This content is intended for educational and technical evaluation purposes. Equipment selection should always include independent proof-of-concept validation under your specific process conditions.
Last Updated
: September 2026