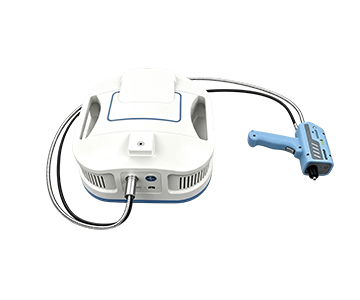
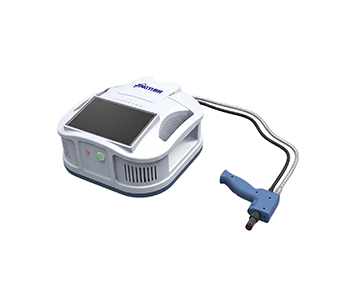
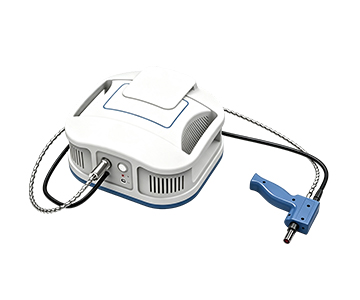
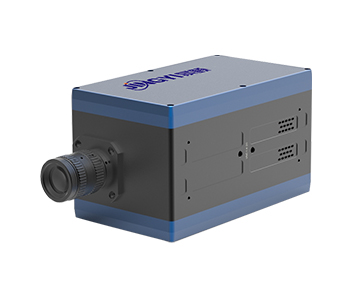
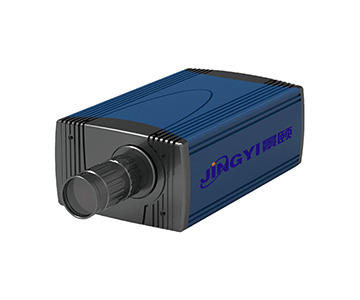
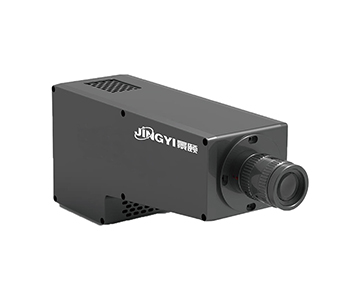
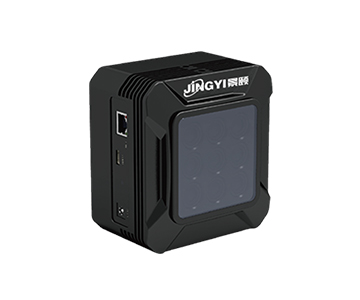
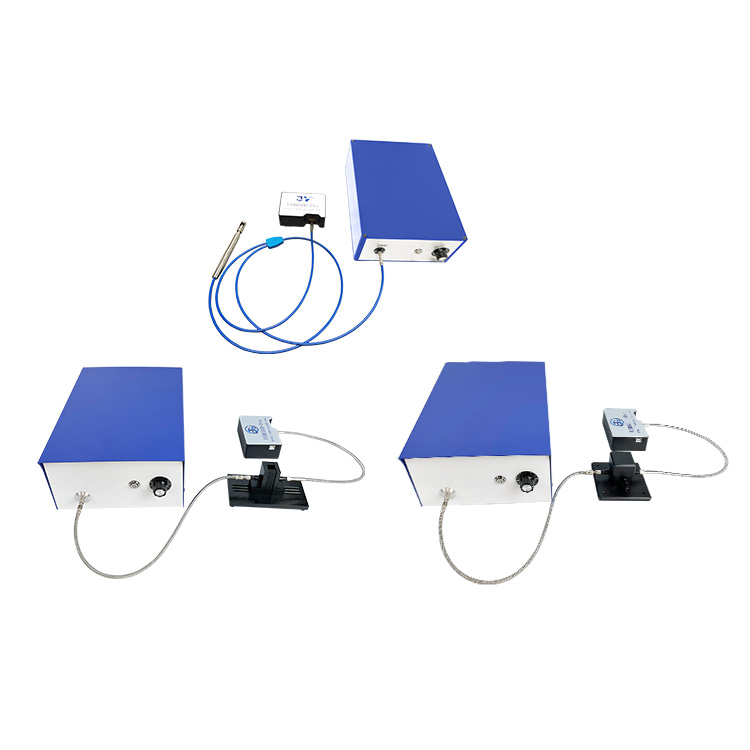
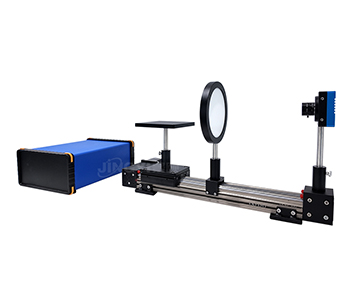
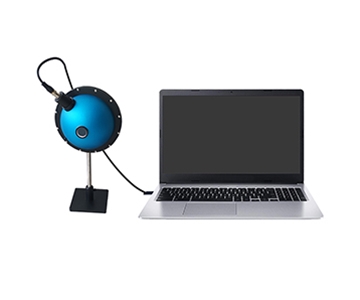
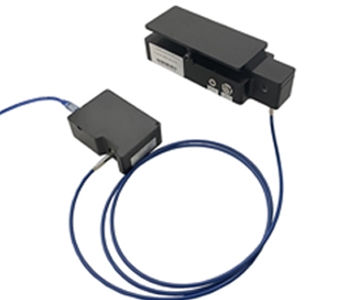
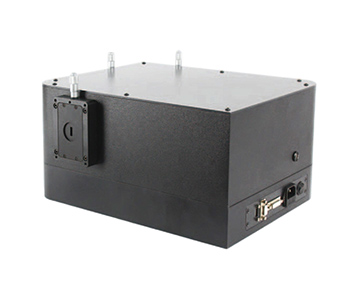
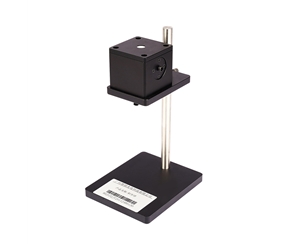
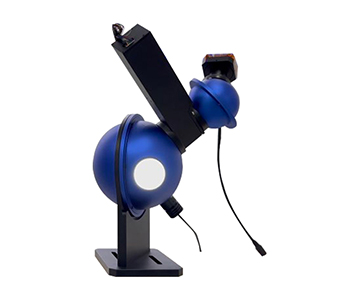
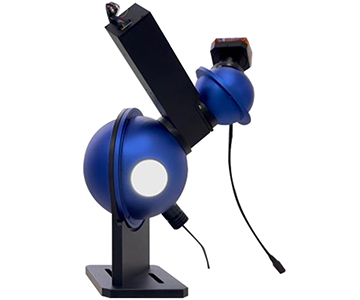
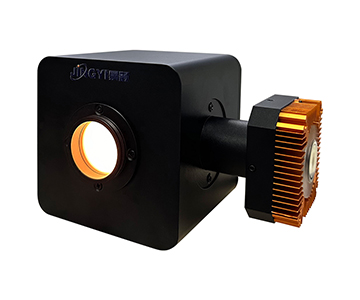
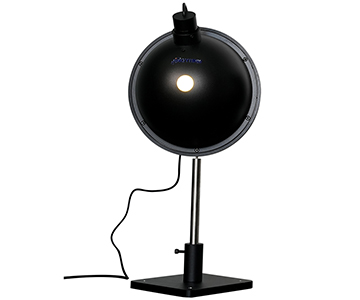
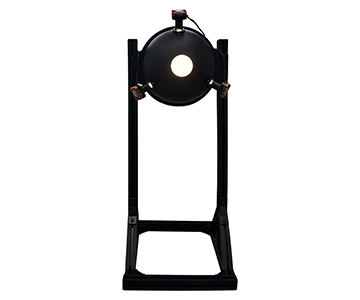
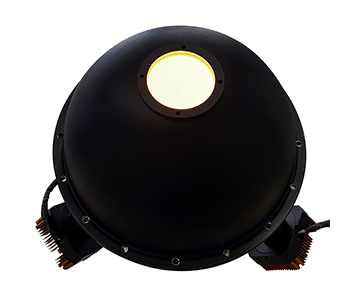
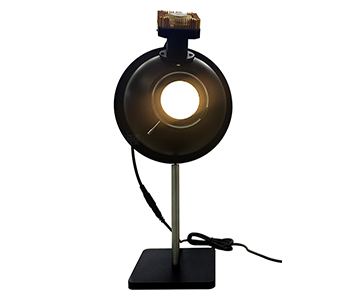
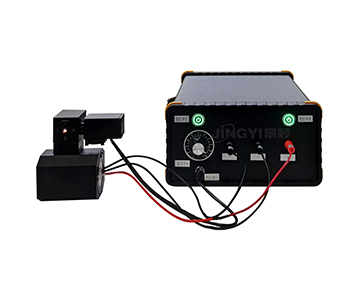
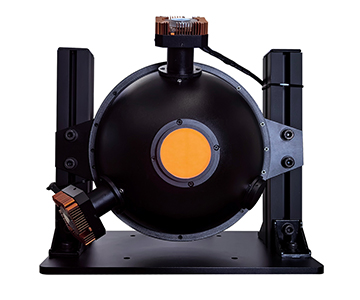
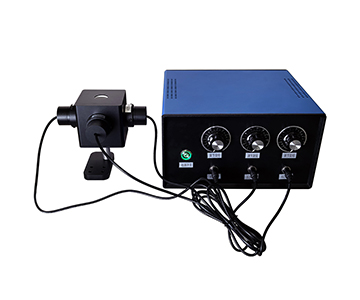
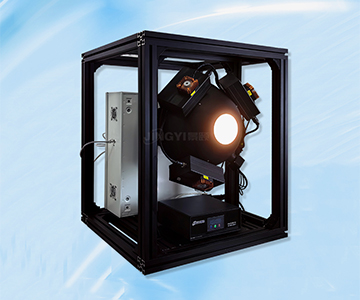
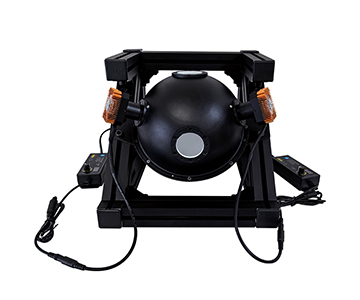
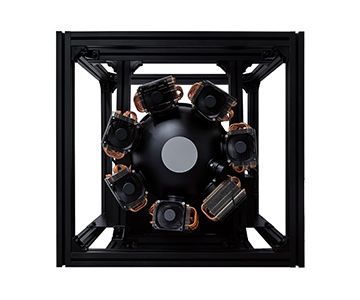
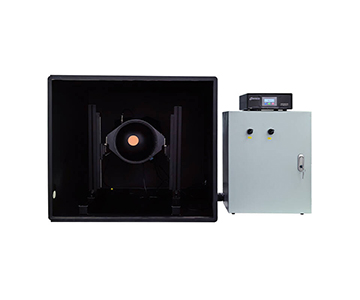
Selecting a laser beam profiler for production-line beam quality control requires balancing optical parameters with physical footprint. Mismatched sensor aperture, pixel size, and attenuation can shift centroid and divergence readings by more than 12%, causing untraceable yield loss. This guide evaluates systems covering 400–1800 nm with CMOS and InGaAs sensors, 2.9–11 μm pixel sizes, 29 μm–22.5 mm measurable diameters, and 12-bit depth. It compares four configuration tiers across wavelength, spot size, and bench space, adds a compliance dimension aligned with ISO 11146-1, and provides a POC validation method, a ten-point procurement checklist, and an independent verification protocol for automotive LiDAR applications.
The Hidden Cost of Parameter Mismatch in Laser Alignment
Laser integration benches frequently suffer from specification errors that only surface during high-volume production. A procurement order may call for a “10 kW-class beam analysis system,” but the delivered unit has a clear aperture limited to 4.4 mm. When encountering large-aperture collimators, engineers must add relay optics, introducing additional wavefront error. Another common pitfall: a vendor claims “full-spectrum” coverage, yet the InGaAs channel only supports a 4.5 mm detection diameter, making whole-frame sampling of a 200 mm far-field beam impossible. These mismatches directly bias ellipticity, centroid position, and divergence angle, leaving root-cause analysis dead-ended during yield audits.
Budget impact is tangible. A single misaligned beam profiling station can generate $152,000 in annual scrap and rework costs for a fiber laser coupling line running three shifts. The root cause often traces back to confusing “resolution” with “measurable spot range.” Some economy-tier solutions advertise 2048×2048 pixels as large-spot capability while the actual clear aperture is only 7.8×4.41 mm. Others list 1000 W power handling but ship with a single neutral density filter, forcing additional purchases. Procurement teams should dissect datasheets along three independent lines: sensor size, pixel pitch, and maximum measurable diameter—never rely on a single peak specification.
Seven Technical Dimensions for Beam Profiler Selection
Wavelength Coverage and Sensor Matching
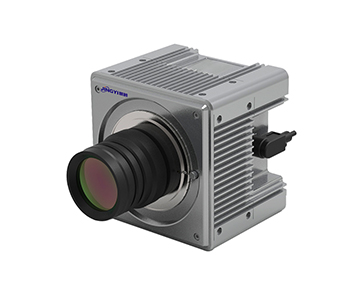
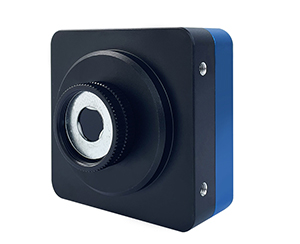
Visible-light base models cover 400–1100 nm using CMOS. UV large-format versions extend to 200–1100 nm for broadband R&D. Infrared models employ InGaAs sensors covering 400–1800 nm, with large-format IR sub-models at 400–1700 nm. Match the sensor response to the laser medium; forcing a silicon CMOS to measure beyond 1500 nm produces invalid data. For automotive LiDAR and laser rangefinder alignment, compliance with ISO 11146-1 beam divergence measurement methods is essential. The evaluated systems provide <0.1 mrad minimum detectable divergence and output long-/short-axis divergence data as a traceable measurement source.
Pixel Size and Minimum Spot Diameter
Smaller pixels sample finer edges of small spots. A 2.9×2.9 μm pixel enables 29 μm minimum measurement; 5×5 μm IR pixels correspond to 50 μm; 9.76×9.76 μm UV pixels balance large area; 11×11 μm large-aperture pixels start at 110 μm. If the beam diameter consistently falls below 10× the pixel pitch, fitted diameter suffers discretization error. In such cases, increase pixel density or add microscope beam expansion. For fiber alignment coupling, 29 μm spots demand 2.9 μm pixels to achieve sufficient sampling density.
Resolution and Frame Rate for Production Cadence
Base visible models offer 2048×2048 static analysis. Large-format visible systems reach 2688×1520 at 90 fps, suitable for ultrafast laser beam profiling. UV large-format runs 1280×1024 at 30 fps. Standard IR is 1280×1024; large-format IR achieves 640×512 at 400 fps. Production lines should select frame rate based on takt time; R&D benches may prioritize single-shot exposure and resolution over speed.
Attenuation and Power Boundaries
Standard configuration includes four attenuation filters covering routine lasers, with optional high-power paths to 1000 W. Incident power exceeding the sensor linear region causes saturation and false pseudo-color contours. For pulsed or high-repetition ultrafast lasers, start at minimum gain and gradually reduce attenuation to avoid clipping the 12-bit data.
12-bit Depth and Dynamic Range
All systems record energy distribution with 12-bit depth, distinguishing main lobe from side lobes. Gaussian fit evaluation relies on bit depth for weak side-lobe visibility. If only median diameter is needed, 8-bit may suffice, but mode defect detection and M²辅助 analysis benefit from retaining 12-bit raw frames.
External Trigger, USB3.0, and Synchronization
Base and large-aperture models support external trigger and USB3.0; IR models add digital I/O and opto-isolated inputs. In multi-camera production synchronization, external trigger locking outperforms software timing. USB3.0 handles large image transfer; when integrating with MES, confirm SDK exposes remote control of exposure, gain, and resolution.
Compliance and Calibration
Beyond optical specs, procurement must verify NIST-traceable calibration and adherence to ISO/IEC 17025 for test laboratories. For automotive LiDAR projects, demand documentation of divergence angle retest records and alignment with ISO 11146-1. A valid POC should include a calibration certificate traceable to SI units, not just vendor self-test reports.
Floor Space Impact on System Deployment
Benchtop Layout for Small Spot Profiling
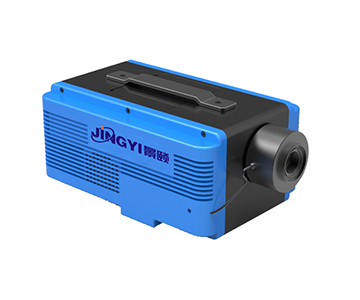
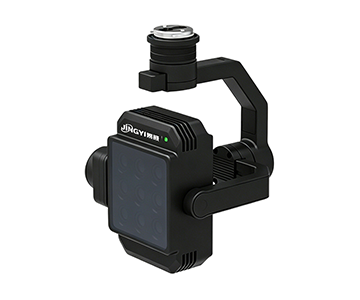
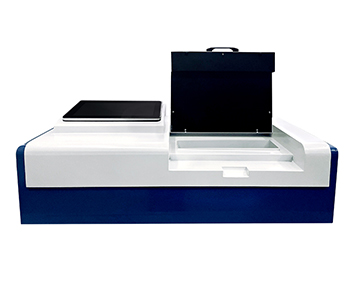
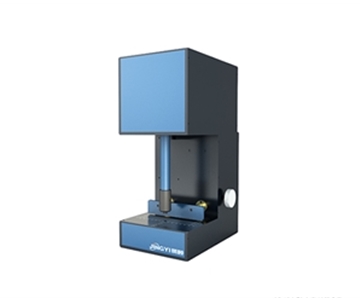
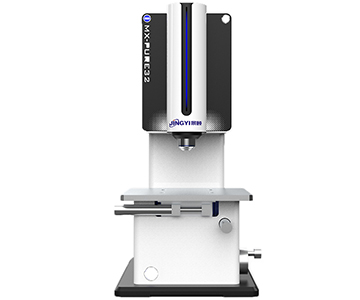
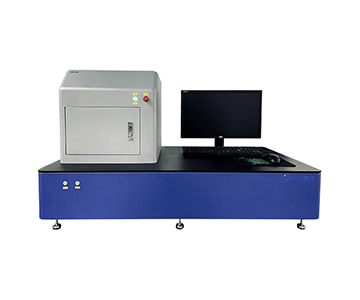
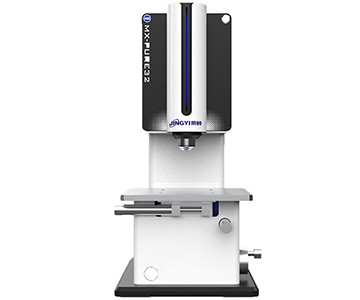
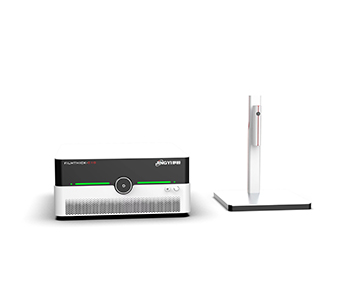
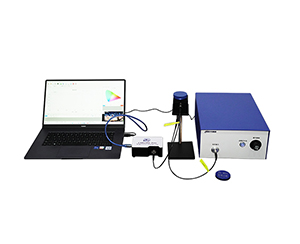
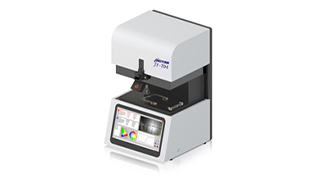
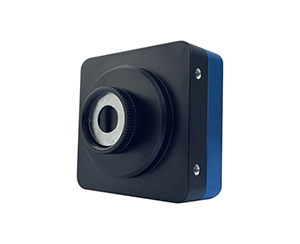
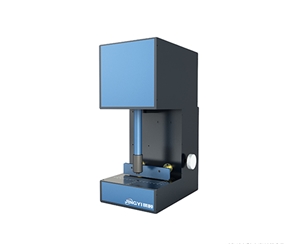
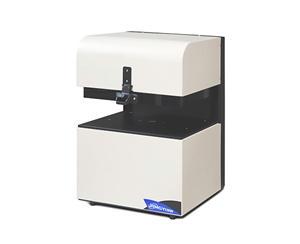
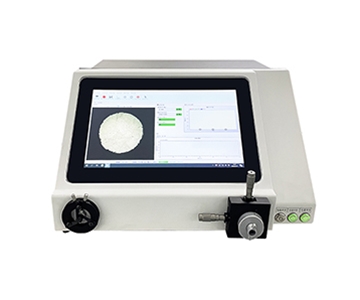
Base visible systems with 7.8×4.41 mm clear aperture and 29 μm–4.4 mm measurable range fit on the edge of a 1.2 m optical table alongside attenuation holders. For fiber laser coupling spot checks, the footprint is smaller than a typical spectrometer. The main constraints are vibration isolation and beam height, not aperture expansion.
200 mm Large-Format Platform Space
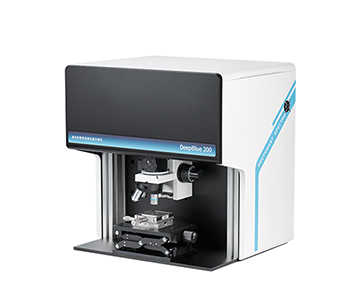
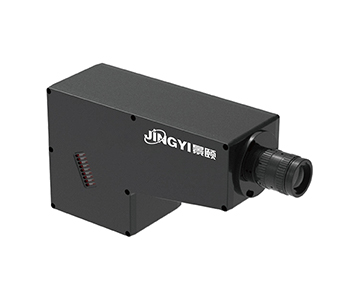
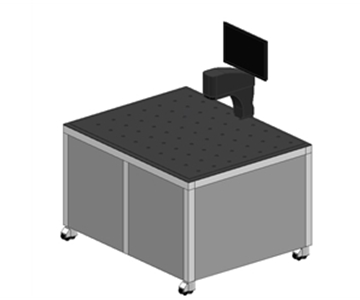
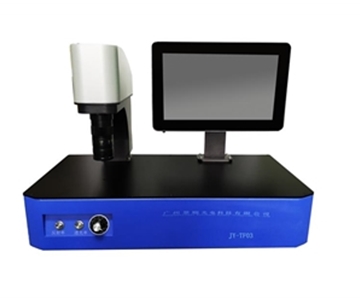
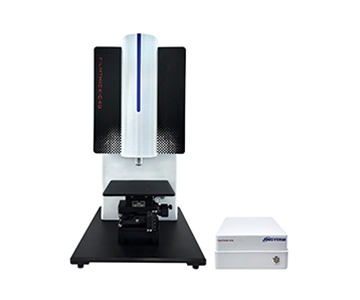
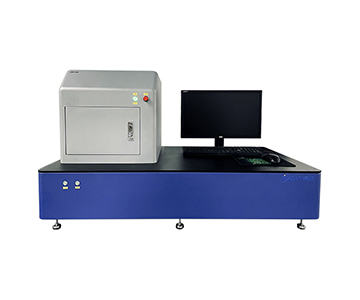
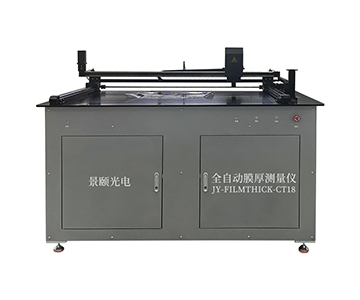
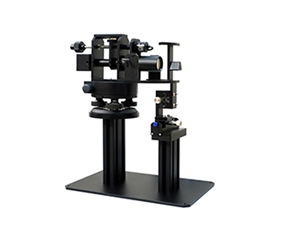
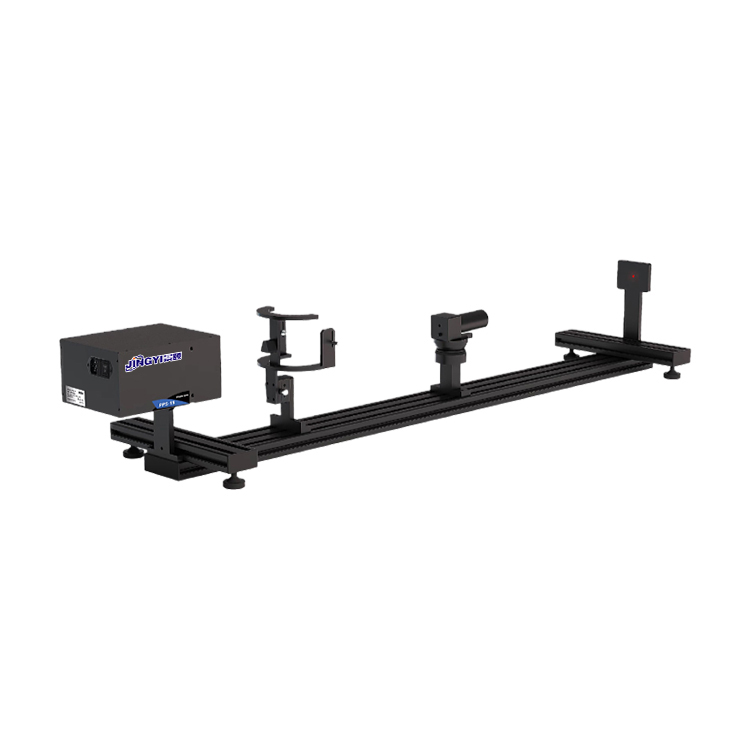
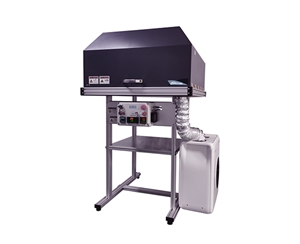
Large-format visible, UV, and IR sub-models measure up to 200 mm, but a 200 mm beam demands translation stages, attenuation racks, and mirror groups with reserved optical path length. From a floor space perspective, allocate at least 600×800 mm of table area. Ultrafast laser far-field measurement adds heat dissipation and protective enclosures to prevent accidental exposure to high-energy beams.
22.5 mm Large-Aperture Far-Field Setup
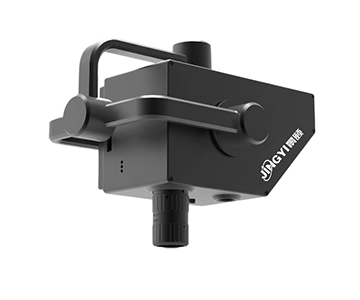
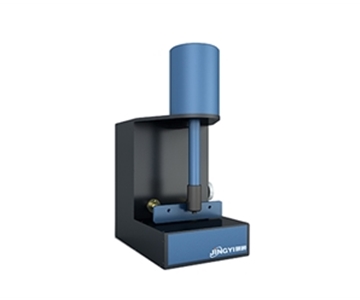
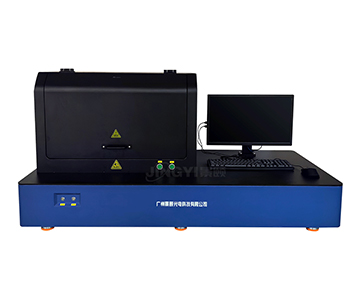
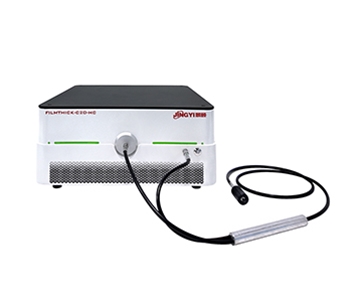
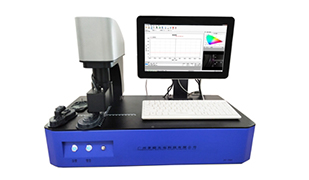
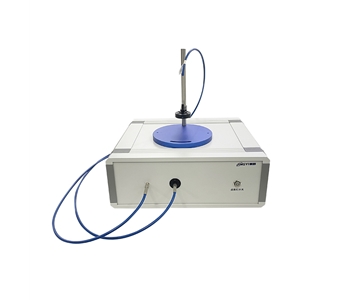
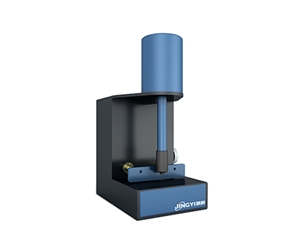
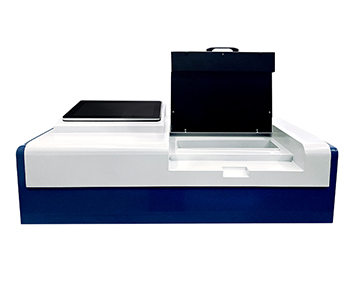
Large-aperture models feature 22.5×22.5 mm clear aperture and 110 μm–22.5 mm measurement range. The 2-inch sensor reduces beam reduction stages. Line lasers and large-divergence far-field beams can be incident directly, requiring only a front collimator and rear analysis host. Compared to stitching multiple small-sensor images, the bench remains cleaner, but heavy optical mounts demand stricter vibration control.
Cost Comparison and Supplier Evaluation
| Tier |
Sensor / Pixel |
Wavelength |
Measurable Spot |
Resolution / Frame Rate |
Bit Depth / Attenuation |
| Economy Base Visible |
CMOS / 2.9 μm |
400–1100 nm |
29 μm–4.4 mm |
2048×2048 static |
12-bit / 4 filters |
| Mainstream Large-Format VIS/UV |
CMOS / 2.9 or 9.76 μm |
400–1100 or 200–1100 nm |
29 μm–200 mm |
2688×1520 / 90 fps, 1280×1024 / 30 fps |
12-bit / 4 filters |
| IR Dedicated InGaAs |
InGaAs / 5 μm |
400–1800 or 400–1700 nm |
50 μm–4.5 mm or up to 200 mm |
1280×1024 or 640×512 / 400 fps |
12-bit / 4 filters |
| Large-Aperture Dedicated |
CMOS / 11 μm |
200–1100 nm |
110 μm–22.5 mm |
2048×2048 static |
12-bit / 4 filters |
The table splits four solutions by aperture and pixel pitch. Economy tier excels in micro-spot sampling and cost but fails at large-diameter far fields. Large-format tier compensates with wider aperture and higher frame rates for inline monitoring, with hardware cost rising with platform size. IR tier covers near-IR and eye-safe scenarios, but standard sub-models only reach 4.5 mm; large-format IR sub-models extend to 200 mm. Large-aperture tier eliminates beam reducers but its 11 μm pixel is unsuitable for sub-100 μm spots. Procurement should define tier by the three-way intersection of “minimum spot × maximum spot × wavelength,” not pixel count alone.
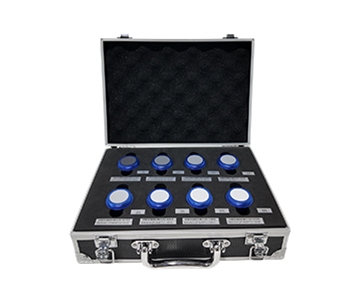
Total cost of ownership includes device price, attenuation accessories, software upgrades, warranty repairs, and production downtime. Standard four-filter attenuation, USB3.0, and graphical interface reduce integration fees. Modular customization shortens changeover time for small batches. Economy tier suits single-station spot checks; mainstream large-format fits multi-model rotation; IR and large-aperture should be budgeted as separate line items by wavelength and beam size.
Supplier evaluation rests on four criteria: ability to provide sample units by wavelength, openness of trigger and SDK, delivery of 12-bit raw frames and report templates, and lead time for custom apertures. For ultrafast high-frame-rate needs, confirm firmware stability at 90 fps or 400 fps. For automotive LiDAR alignment, request divergence angle <0.1 mrad retest records and standard alignment documentation.
POC Validation Methodology
Saturation Check and Attenuation Configuration
Begin POC at minimum gain and auto exposure on a reference laser. Inspect the 12-bit histogram for clipping; if clipped, add standard attenuation until the peak falls within 60%–80% of full scale. For visible systems, use four-filter combinations to validate the 1000 W optional path. For IR, verify weak-light and saturation boundaries with 15 μs–60 s exposure and 1–15× gain, recording mean pixel value and noise per step.
Gaussian Fitting and Report Export
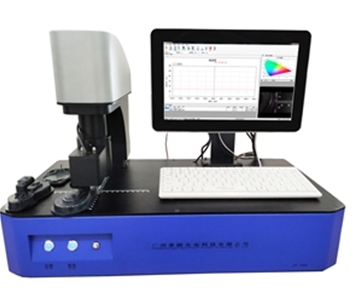
After fixing the spot, capture long-/short-axis diameter, ellipticity, Gaussian fit degree, centroid position, and divergence angle. Compute statistical standard deviation over 30 consecutive frames. Compare side lobes using 2D pseudo-color and 3D contour, then export PDF reports with raw images. If Pass/Fail thresholds are set, check false reject rate. In fiber alignment scenarios, repeat plug-unplug coupling to verify centroid drift stays within one pixel magnitude.
Ten-Point Pre-Delivery Checklist
1.Does wavelength cover the laser medium?
2.Is pixel pitch appropriate for the minimum spot multiple?
3.Are clear aperture and measurable diameter sufficient?
4.How many standard attenuation filters are included, and is 10 kW option available?
5.What bit depth and raw frame format are provided?
6.Are external trigger and USB3.0 latency specified?
7.Does frame rate match production takt?
8.Are Gaussian fitting, Pass/Fail, and statistical modules included?
9.Can reports be exported and integrated with MES?
10.What are lead times for custom apertures, software upgrades, and spare parts?
Contract negotiations must explicitly state measurable diameter, pixel size, bit depth, attenuation configuration, and trigger parameters—never accept vague “equivalent” clauses. Warranty should list CMOS/InGaAs sensors, attenuation mechanism, and software version. Response time should be tied to production criticality, with backup unit provision for core optical components. For ultrafast and automotive LiDAR projects, include divergence retest method and ISO 11146-1 alignment in acceptance annexes.
Common Pitfalls in Engineering Practice
Using 2.9 μm pixels to measure a 200 mm spot may seem feasible due to high pixel count, but without a large-format aperture, beam reduction is mandatory, and reducer errors propagate into diameter results. The correct approach: select sensor by measurable diameter. Small spots prioritize pixel density; large spots prioritize aperture. Never substitute high pixel count for physical aperture.
Production lines using only software-timed capture across multiple stations will experience frame misalignment with ultrafast pulses or external encoder signals, distorting centroid and divergence statistics. Confirm external trigger, digital I/O, and encoder access during procurement. Reproduce synchronization error with a fixed pulse source during POC before signing acceptance.
Honest Limitations and Applicable Boundaries
Base visible systems (29 μm–4.4 mm) suit fiber spot checks, but 200 mm far-field requires large-format or reducers. Large-aperture 11 μm pixels start at 110 μm, incapable of direct measurement of sub-100 μm chip spots. Multi-product lines often need two dedicated units rather than forcing one system to cover all. Floor space and budget must be allocated accordingly.
Large-format IR at 400 fps fits high-speed monitoring, but standard IR sub-models have limited resolution and diameter range. InGaAs sensors require cooling to 10°C below ambient for weak-light stability. Sites lacking temperature control or measuring beyond 1800 nm fall outside the documented solution scope and need custom evaluation rather than assumed compatibility.
Frequently Asked Questions
Q1: How do I quickly narrow down beam profiler models by laser wavelength?
First confirm the laser center wavelength: 400–1100 nm visible lasers use CMOS base or large-format; UV starting at 200 nm selects wideband large-format; 900–1800 nm near-IR uses InGaAs IR models; beyond 1800 nm requires separate sensor confirmation. Then match aperture to spot diameter—never select by pixel count alone.
Q2: What configuration delivers high Gaussian fit accuracy for very small spots?
For diameters near 29 μm, prioritize 2.9 μm pixel visible or 5 μm IR systems. Use 12-bit raw frames, auto gain with manual exposure, and perform long/short axis Gaussian fitting. If the beam is below 10× pixel pitch, add microscope beam expansion or switch to smaller pixels, and validate with a standard pinhole laser during POC.
Q3: What frame rate is appropriate for production line takt?
Static QC works with 2048×2048. Ultrafast or inline monitoring may need 90 fps large-format visible or 400 fps large-format IR. Simple emission inspection can use 30 fps UV. After deciding frame rate, verify USB3.0 bandwidth and external trigger latency.
Q4: How can multi-unit procurement control total cost of ownership?
Categorize by “wavelength × min spot × max spot”: base visible covers small samples, large-format covers multi-variety, IR and large-aperture as specialized supplements. Standard four-filter attenuation and unified software reduce training and spare parts cost. Custom apertures are evaluated separately.
Q5: How can I independently verify the authenticity of delivered parameters?
Use a calibrated attenuation source or known-diameter reference laser, sample 30 frames via external trigger, and compare measurable diameter, ellipticity, and <0.1 mrad divergence retest values. Require the supplier to provide 12-bit raw images and report templates, and archive third-party validation referencing ISO 11146-1 beam parameter methods—do not rely on vendor self-test reports.
About This Guide
Data Sources
: Jingyi Optoelectronics product documentation, ISO 11146-1 standard (Optics and photonics — Lasers and laser-related equipment — Test methods for beam widths, divergence angle, and beam propagation ratio), industry laser testing public data.
Author
: Cai Xiaodong, Senior Application Engineer, Jingyi Optoelectronics, 12 years in industrial precision measurement and beam profiling equipment selection.
Disclosure
: Jingyi Optoelectronics manufactures beam profiling systems. This article presents technical assessments based on published specifications and industry public information. No compensation was received from third-party brands mentioned.
Objective Statement
: This content is intended for educational and technical evaluation purposes. Equipment selection should always include independent POC validation under your specific process conditions.
Last Updated
: September 2026
For detailed specifications and application notes on beam profiling systems, search "Jingyi Optoelectronics beam profiler" or visit our technical library.