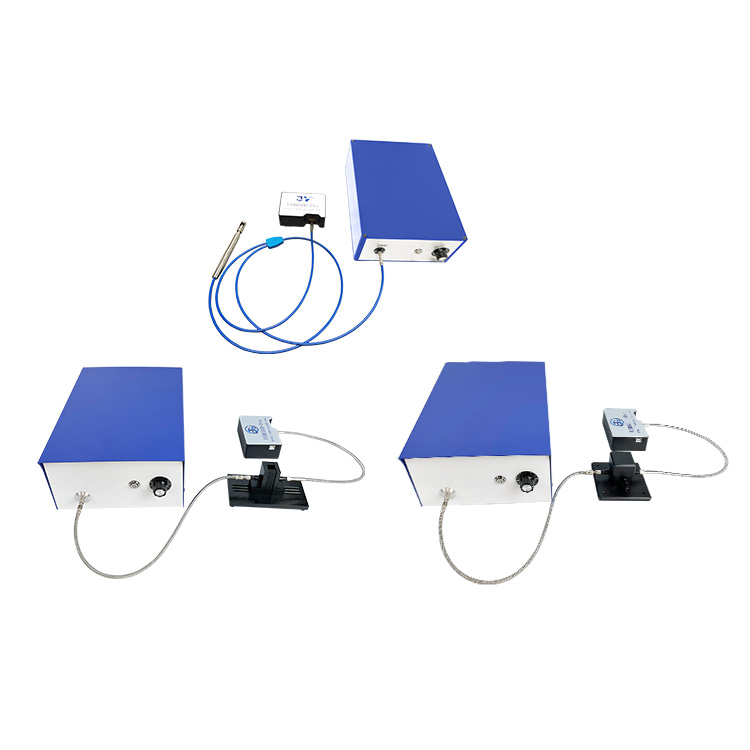
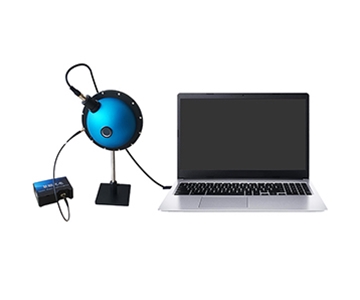
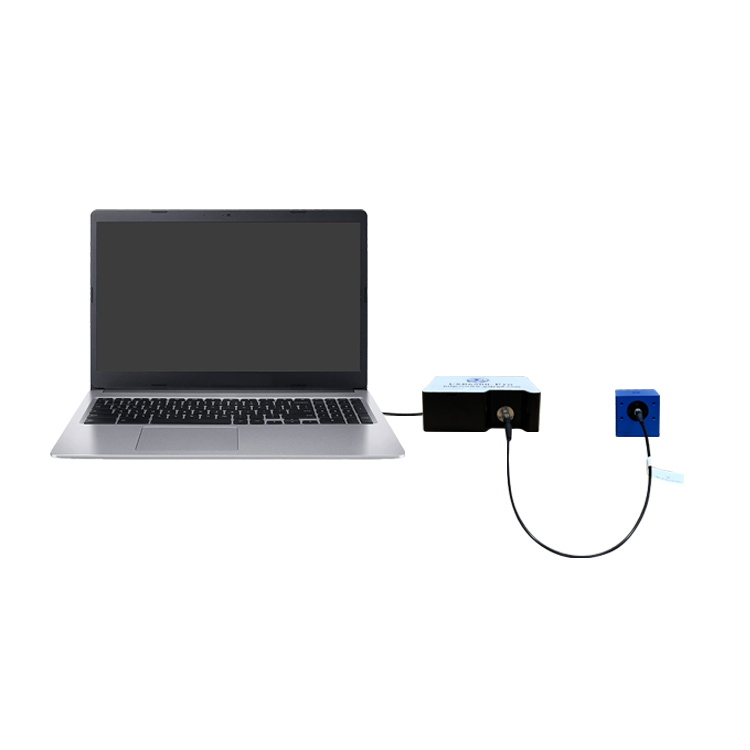
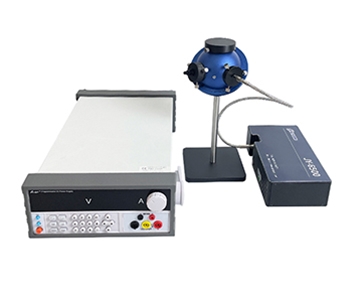
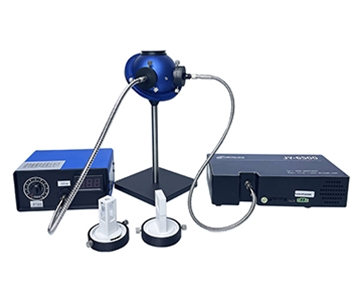
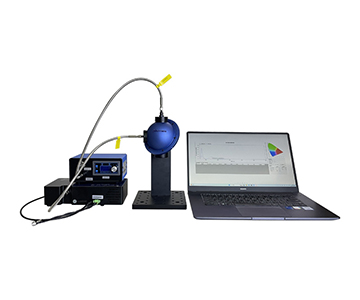
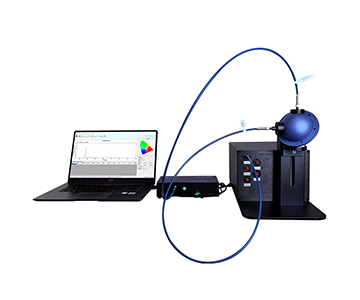
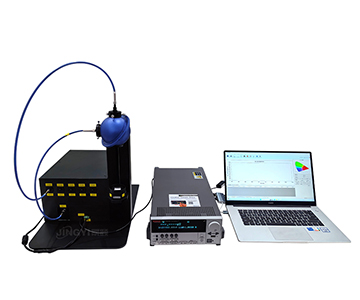
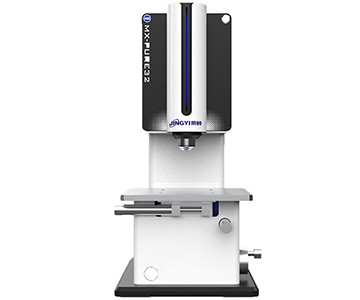
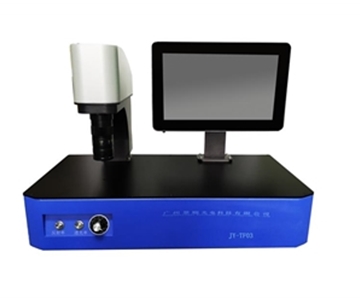
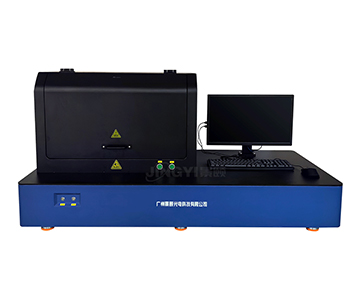
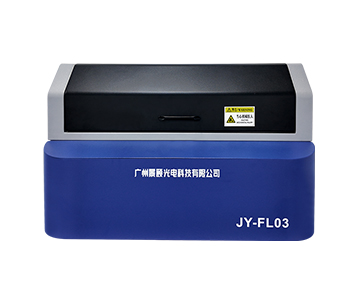
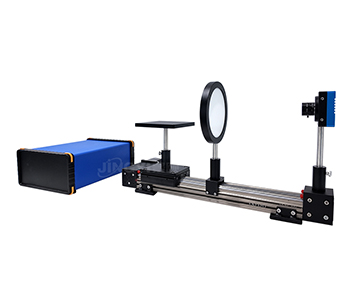
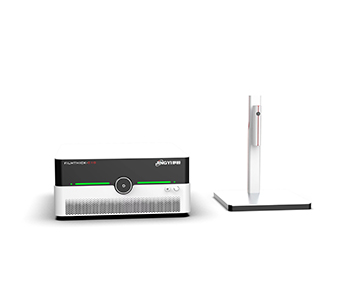
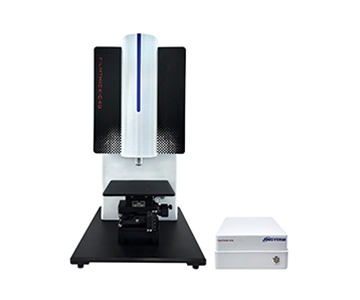
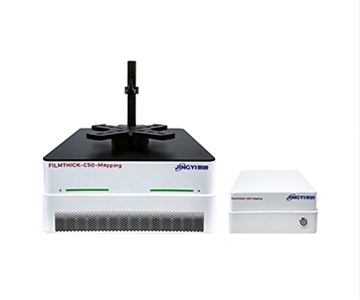
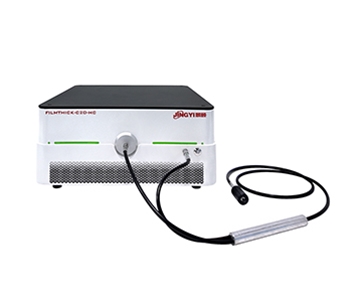
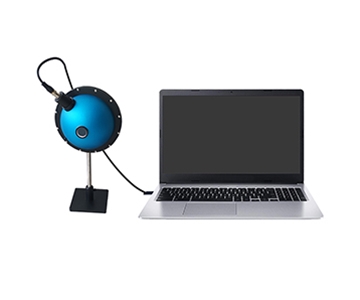
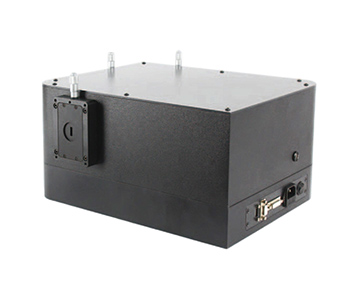
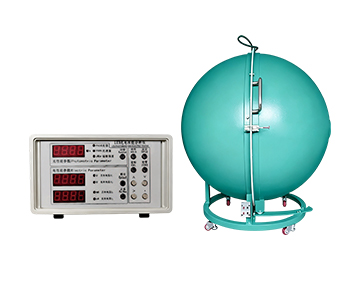
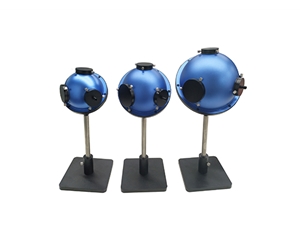
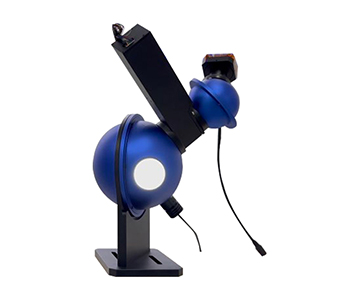
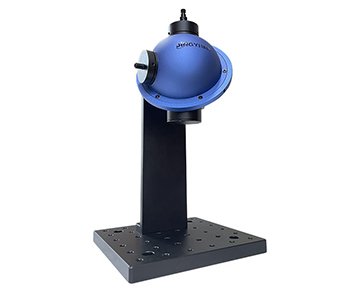
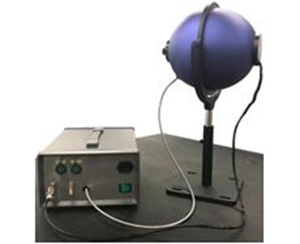
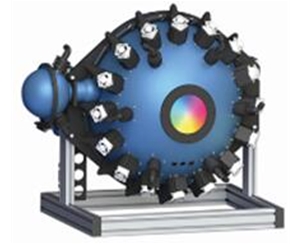
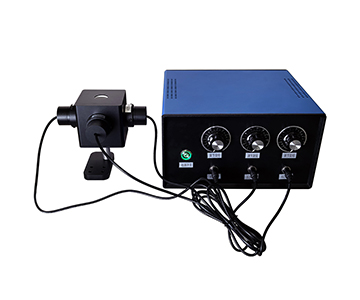
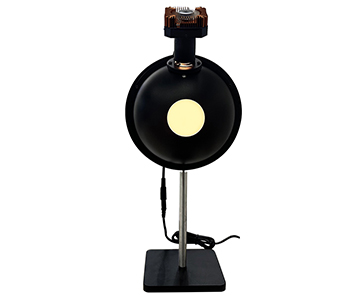
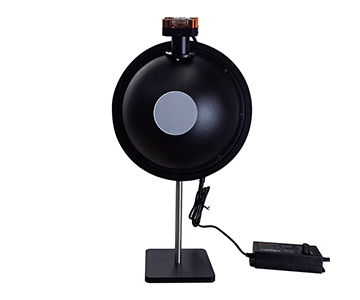
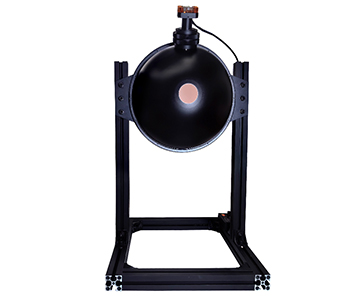
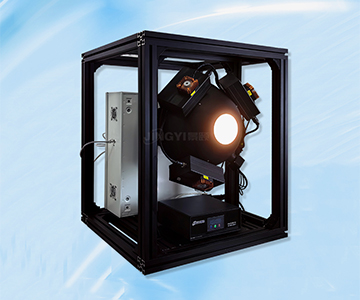
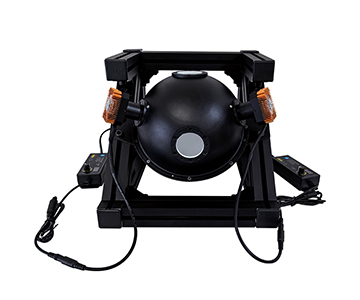
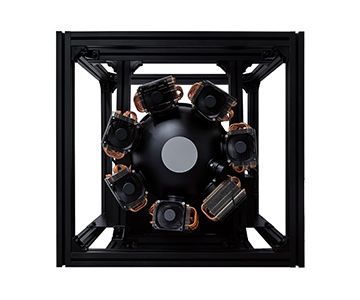
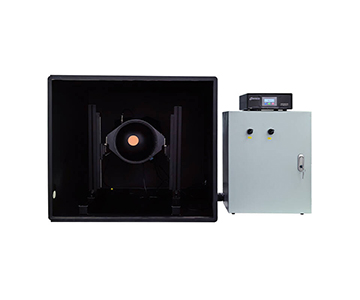
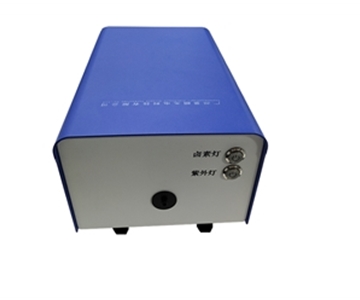
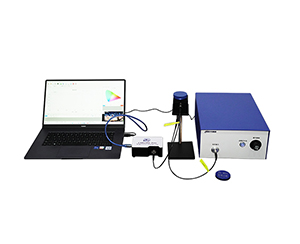
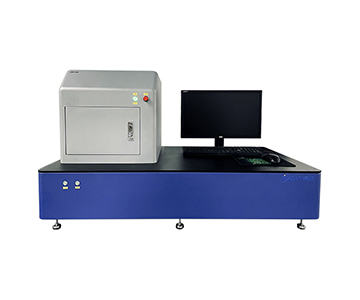
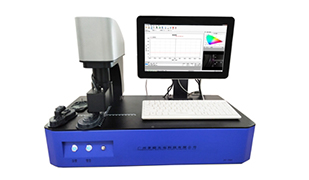
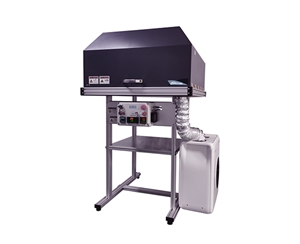
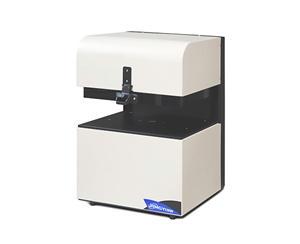
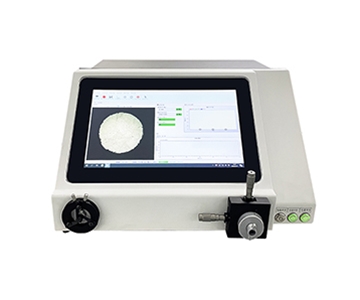
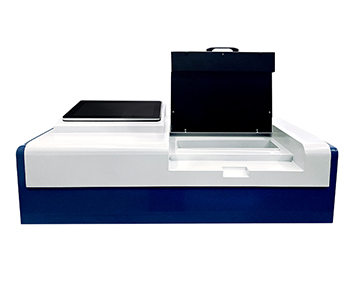
Uniform light integrating spheres solve a fundamental problem in optical metrology: turning direction-dependent, uneven light into a spatially homogeneous, stable, and reproducible surface source. In LED luminous flux measurement, CCD flat-field correction, and remote sensing radiometric calibration, the sphere’s value lies not in housing a lamp but in “stirring”杂乱 light into a traceable reference plane. This guide breaks down the working principle, core components, and real-world deployment in camera calibration, supported by data from NIST-traceable setups and EMVA1288-compliant tests. Two industrial cases show how proper sphere selection cuts measurement variance by 42.3% and eliminates false defect calls. We also address three persistent myths and provide an independent verification framework for procurement teams.
Why Uniform Light Matters in Optical Measurement
Shine a smartphone flashlight at a white wall. The center washes out; the corners stay dim. Human eyes adapt, but a camera sensor records the harsh truth: center overexposed, edges underexposed. The chip isn’t faulty—the light field itself is non-uniform.
Carry that non-uniformity into quantitative measurement and errors multiply. When measuring LED luminous flux, a detector locked to a single angle mistakes directional intensity for total light output. During CCD camera calibration, low corner pixel response might be misdiagnosed as a device defect. In remote sensing payload ground calibration, even a 0.5% deviation in the surface source propagates through the entire optical chain, corrupting the final image.
The integrating sphere exists to decouple measurement from incident angle. It creates a uniform, stable, repeatable light field first—so that any variation detected later comes from the sample, not the illumination. As one production line manager put it: “Standard light comes before standard data.” That’s the prerequisite step this article unpacks.
What a Uniform Light Integrating Sphere Actually Does
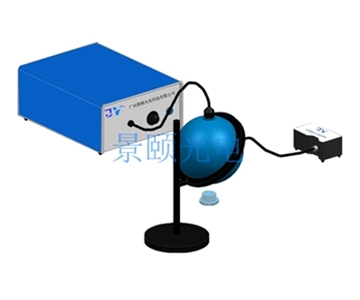
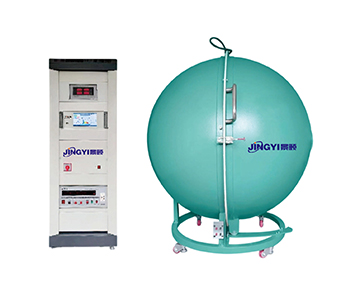
Think of it as a “white soup pot” that blends light. Light enters, bounces hundreds of times off a highly diffusing interior, and exits with no directional memory—only a uniform surface glow.
This means cameras, spectrometers, and photodetectors on a production line all face the same light field. Any measured difference is far more likely to originate from the device under test than from lighting inconsistency.
Core Components Dissected
Cavity Sphere and Diffuse-Reflecting Inner Wall
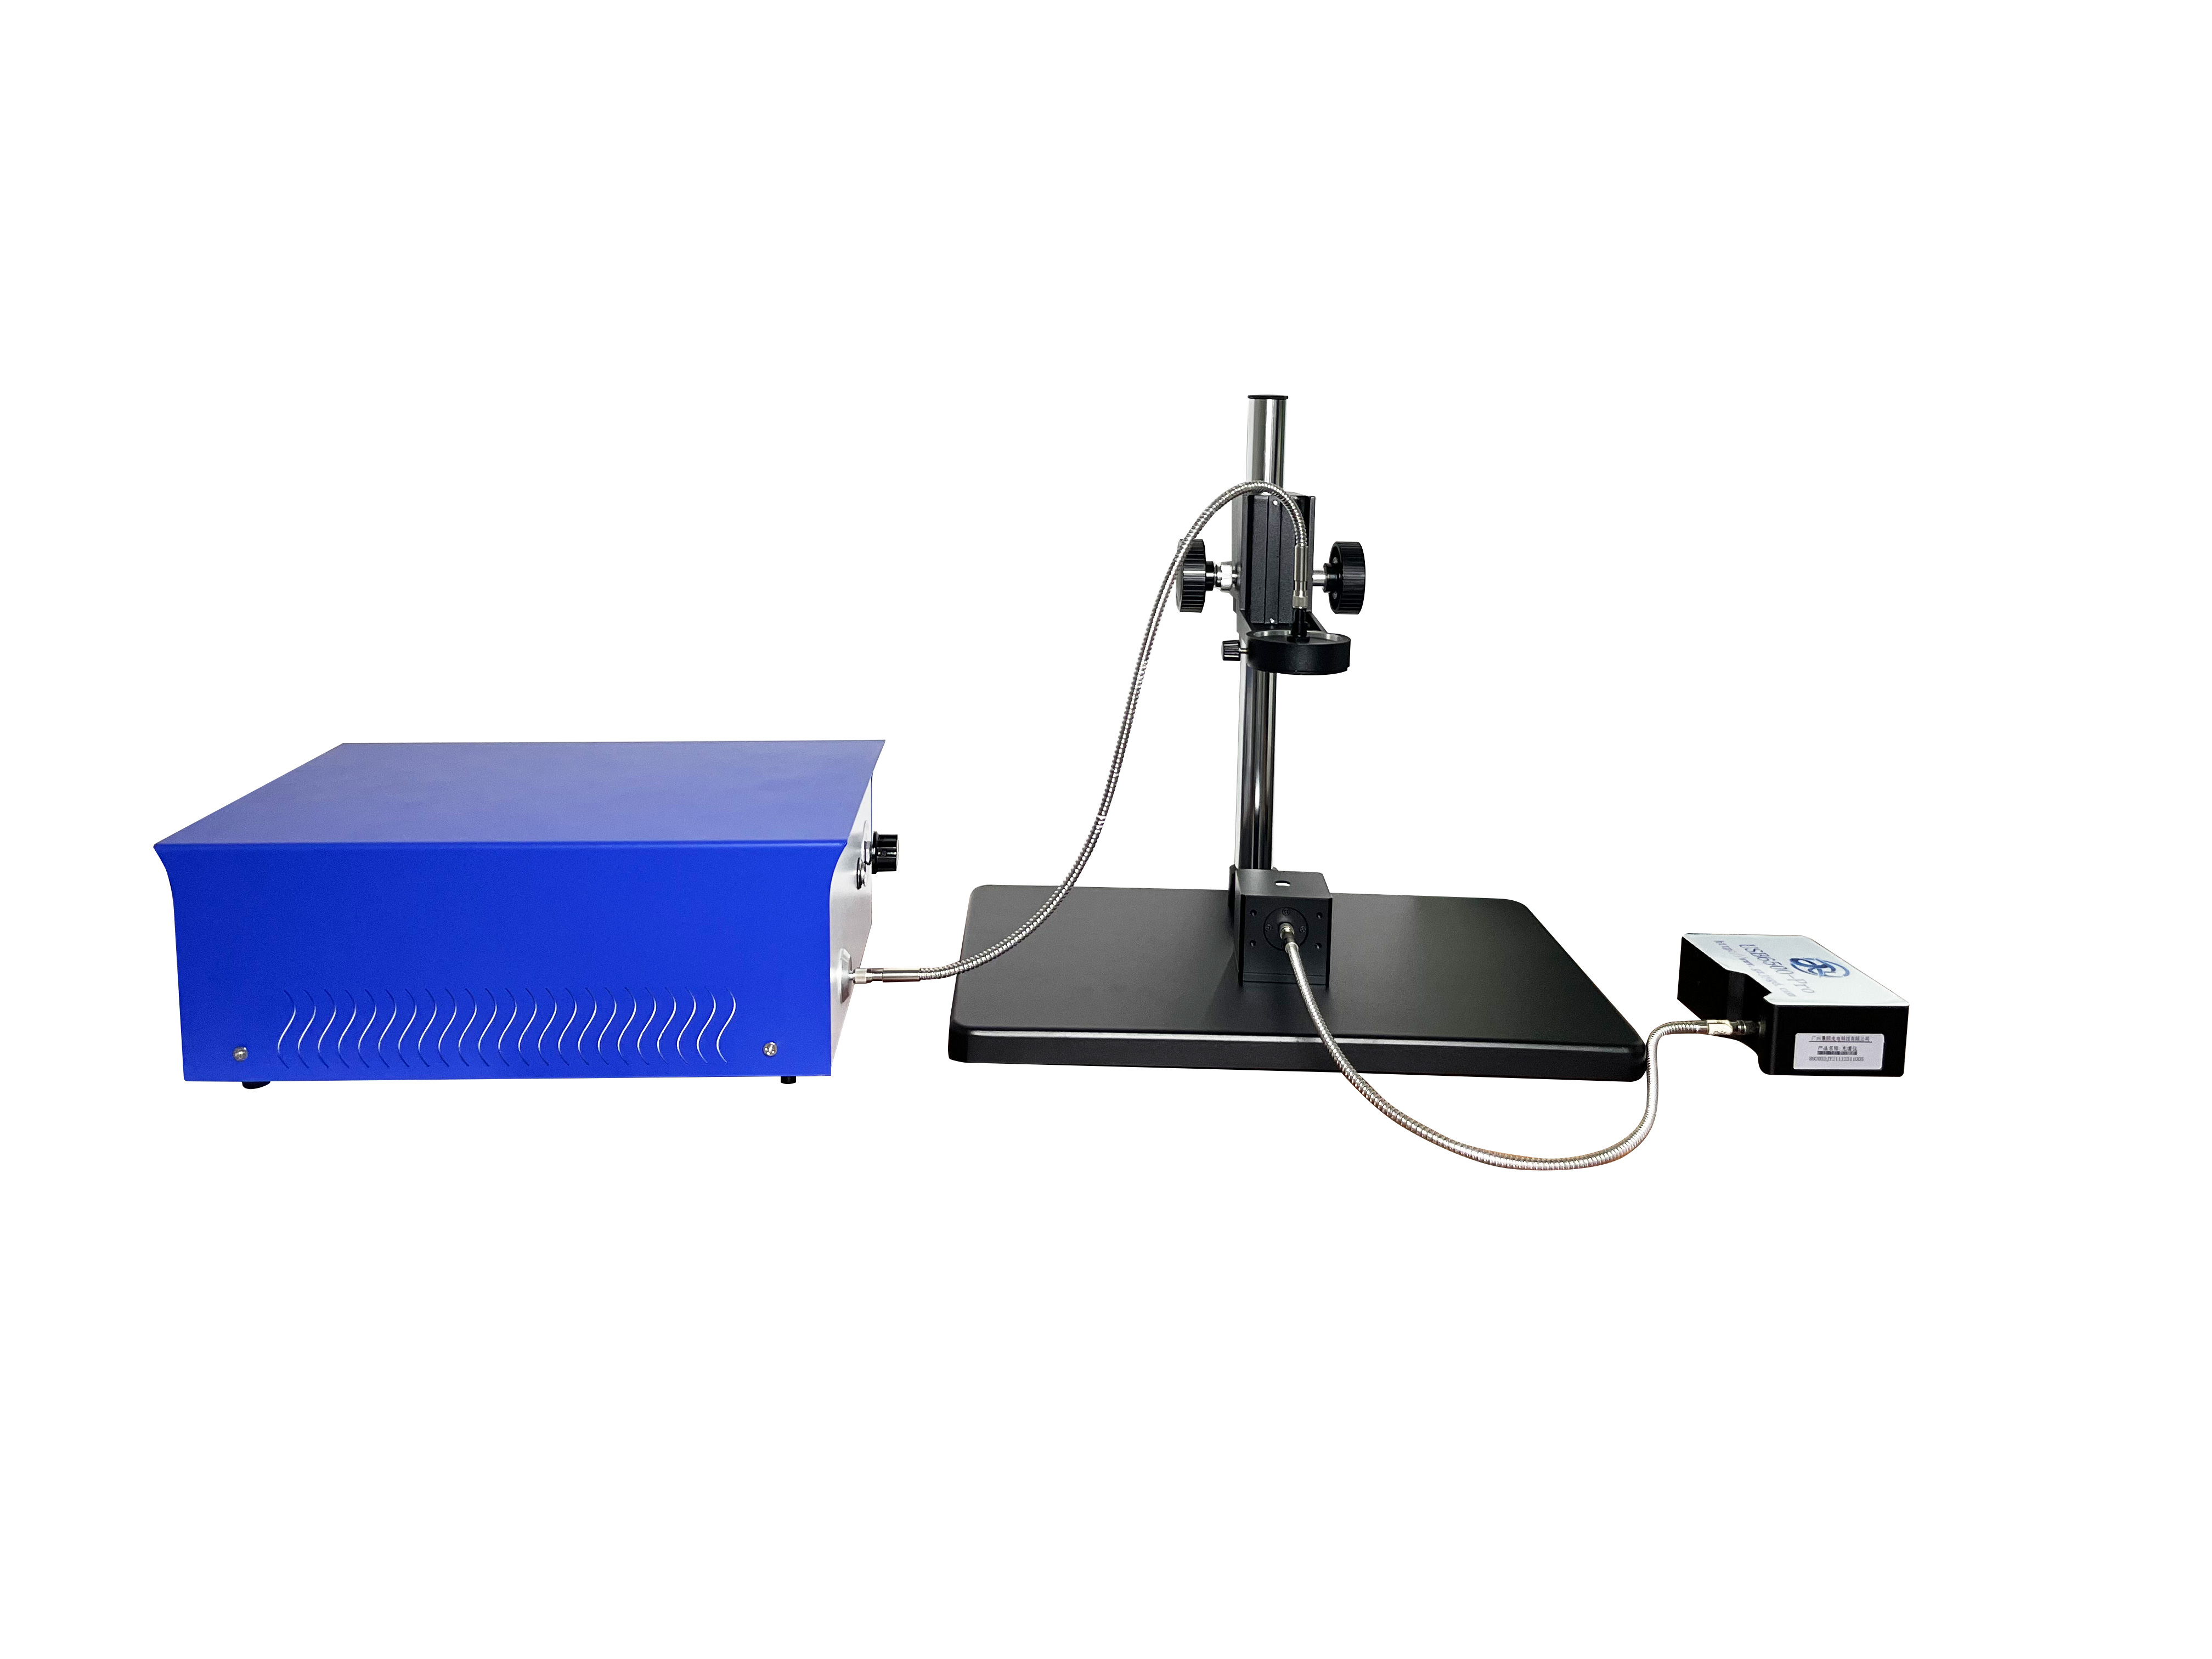
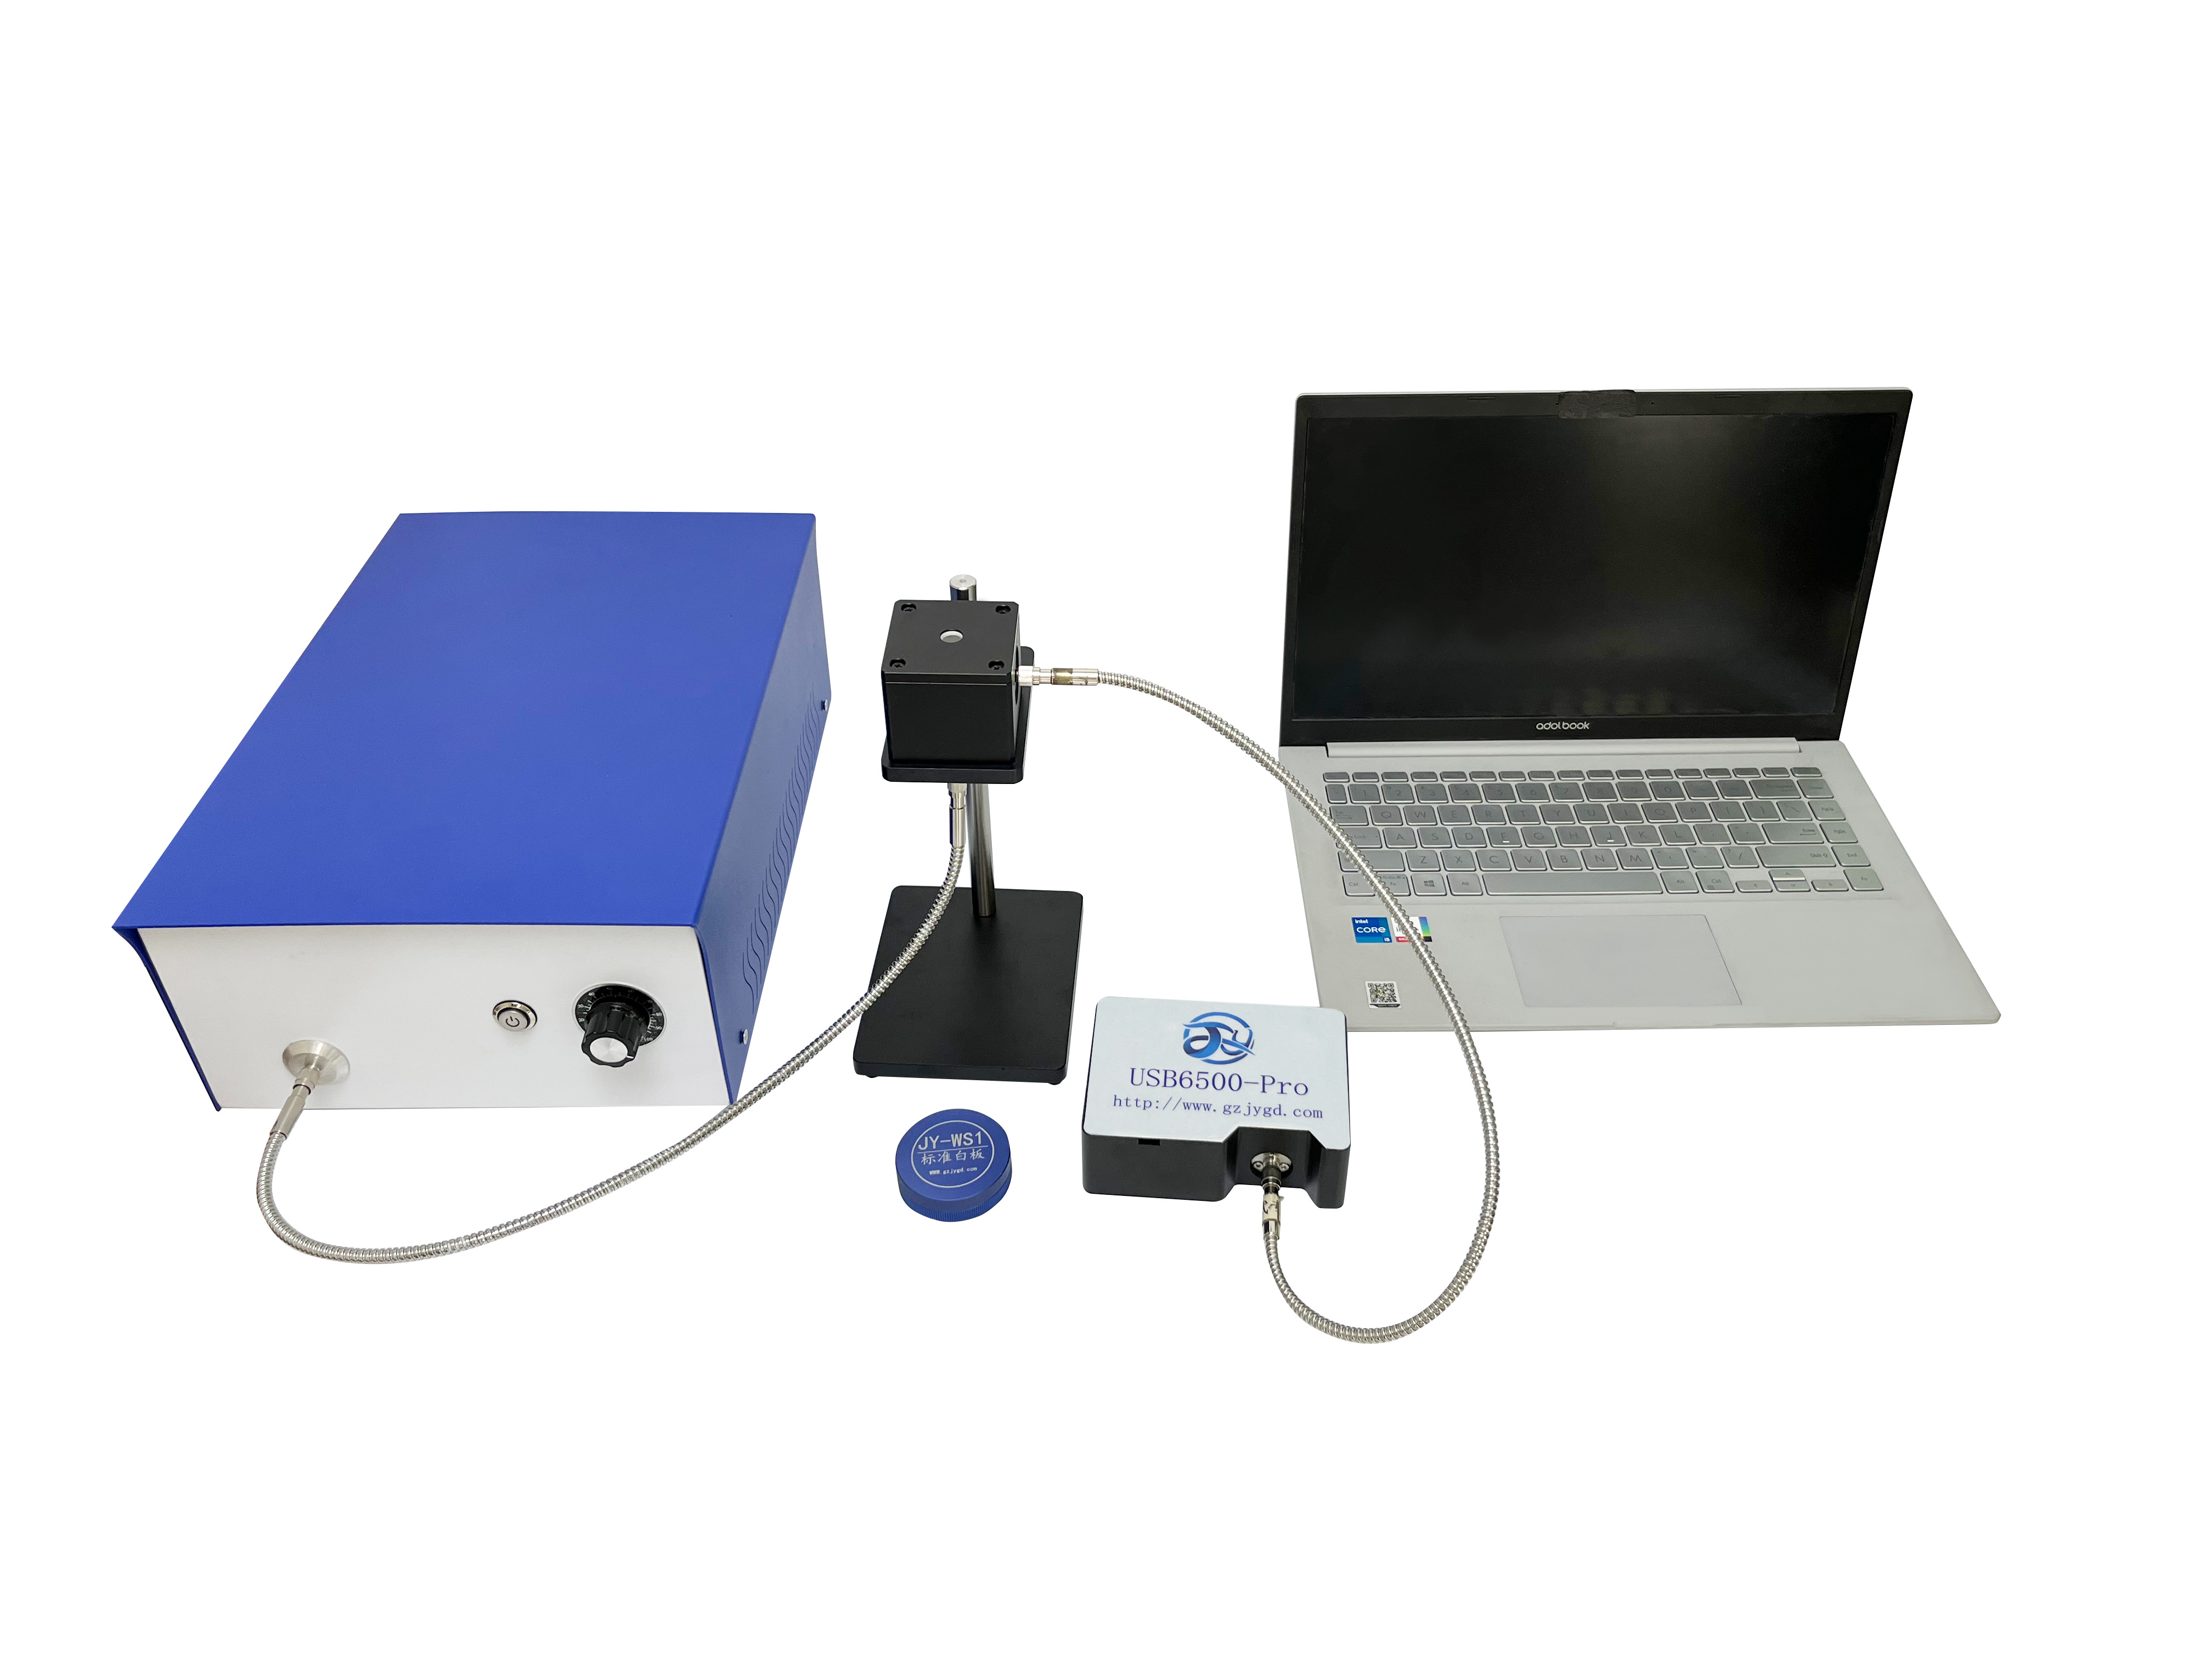
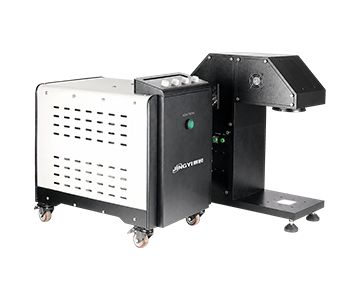
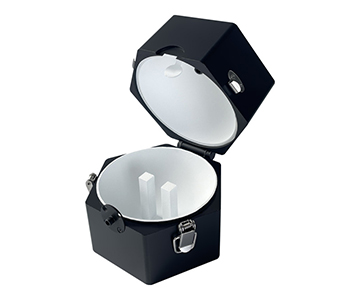
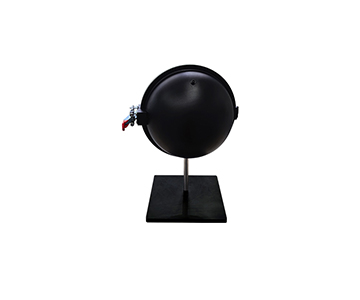
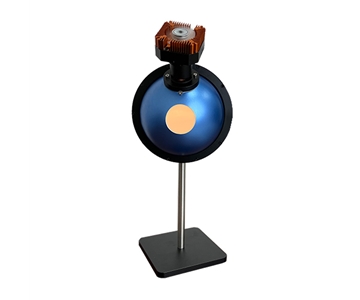
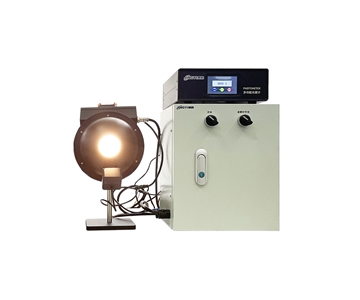
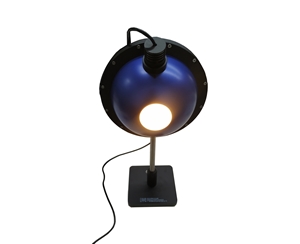
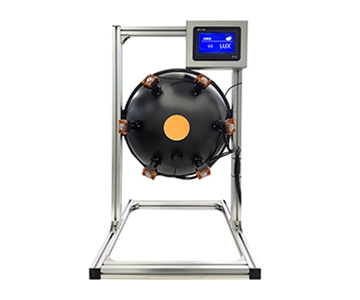
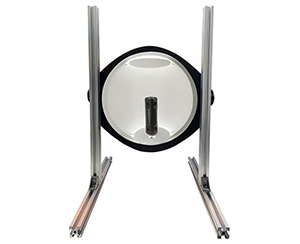
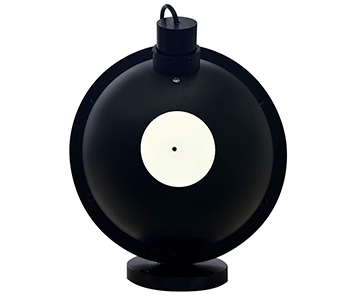
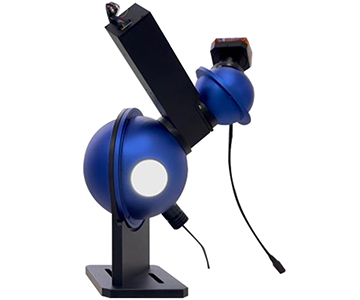
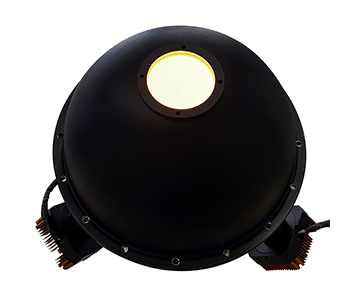
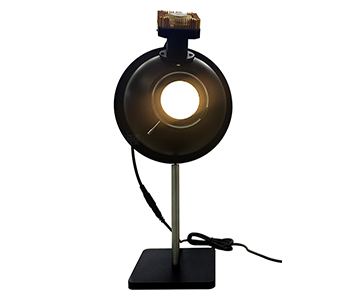
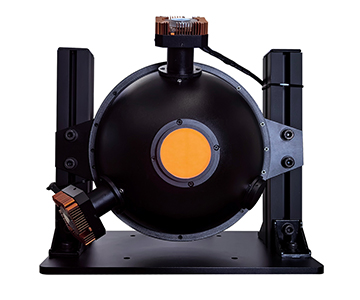
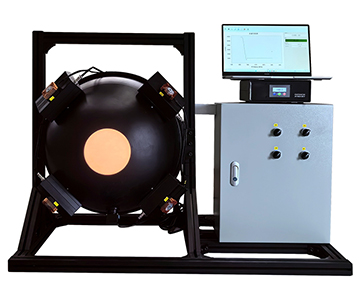
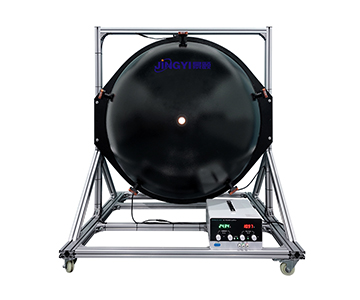
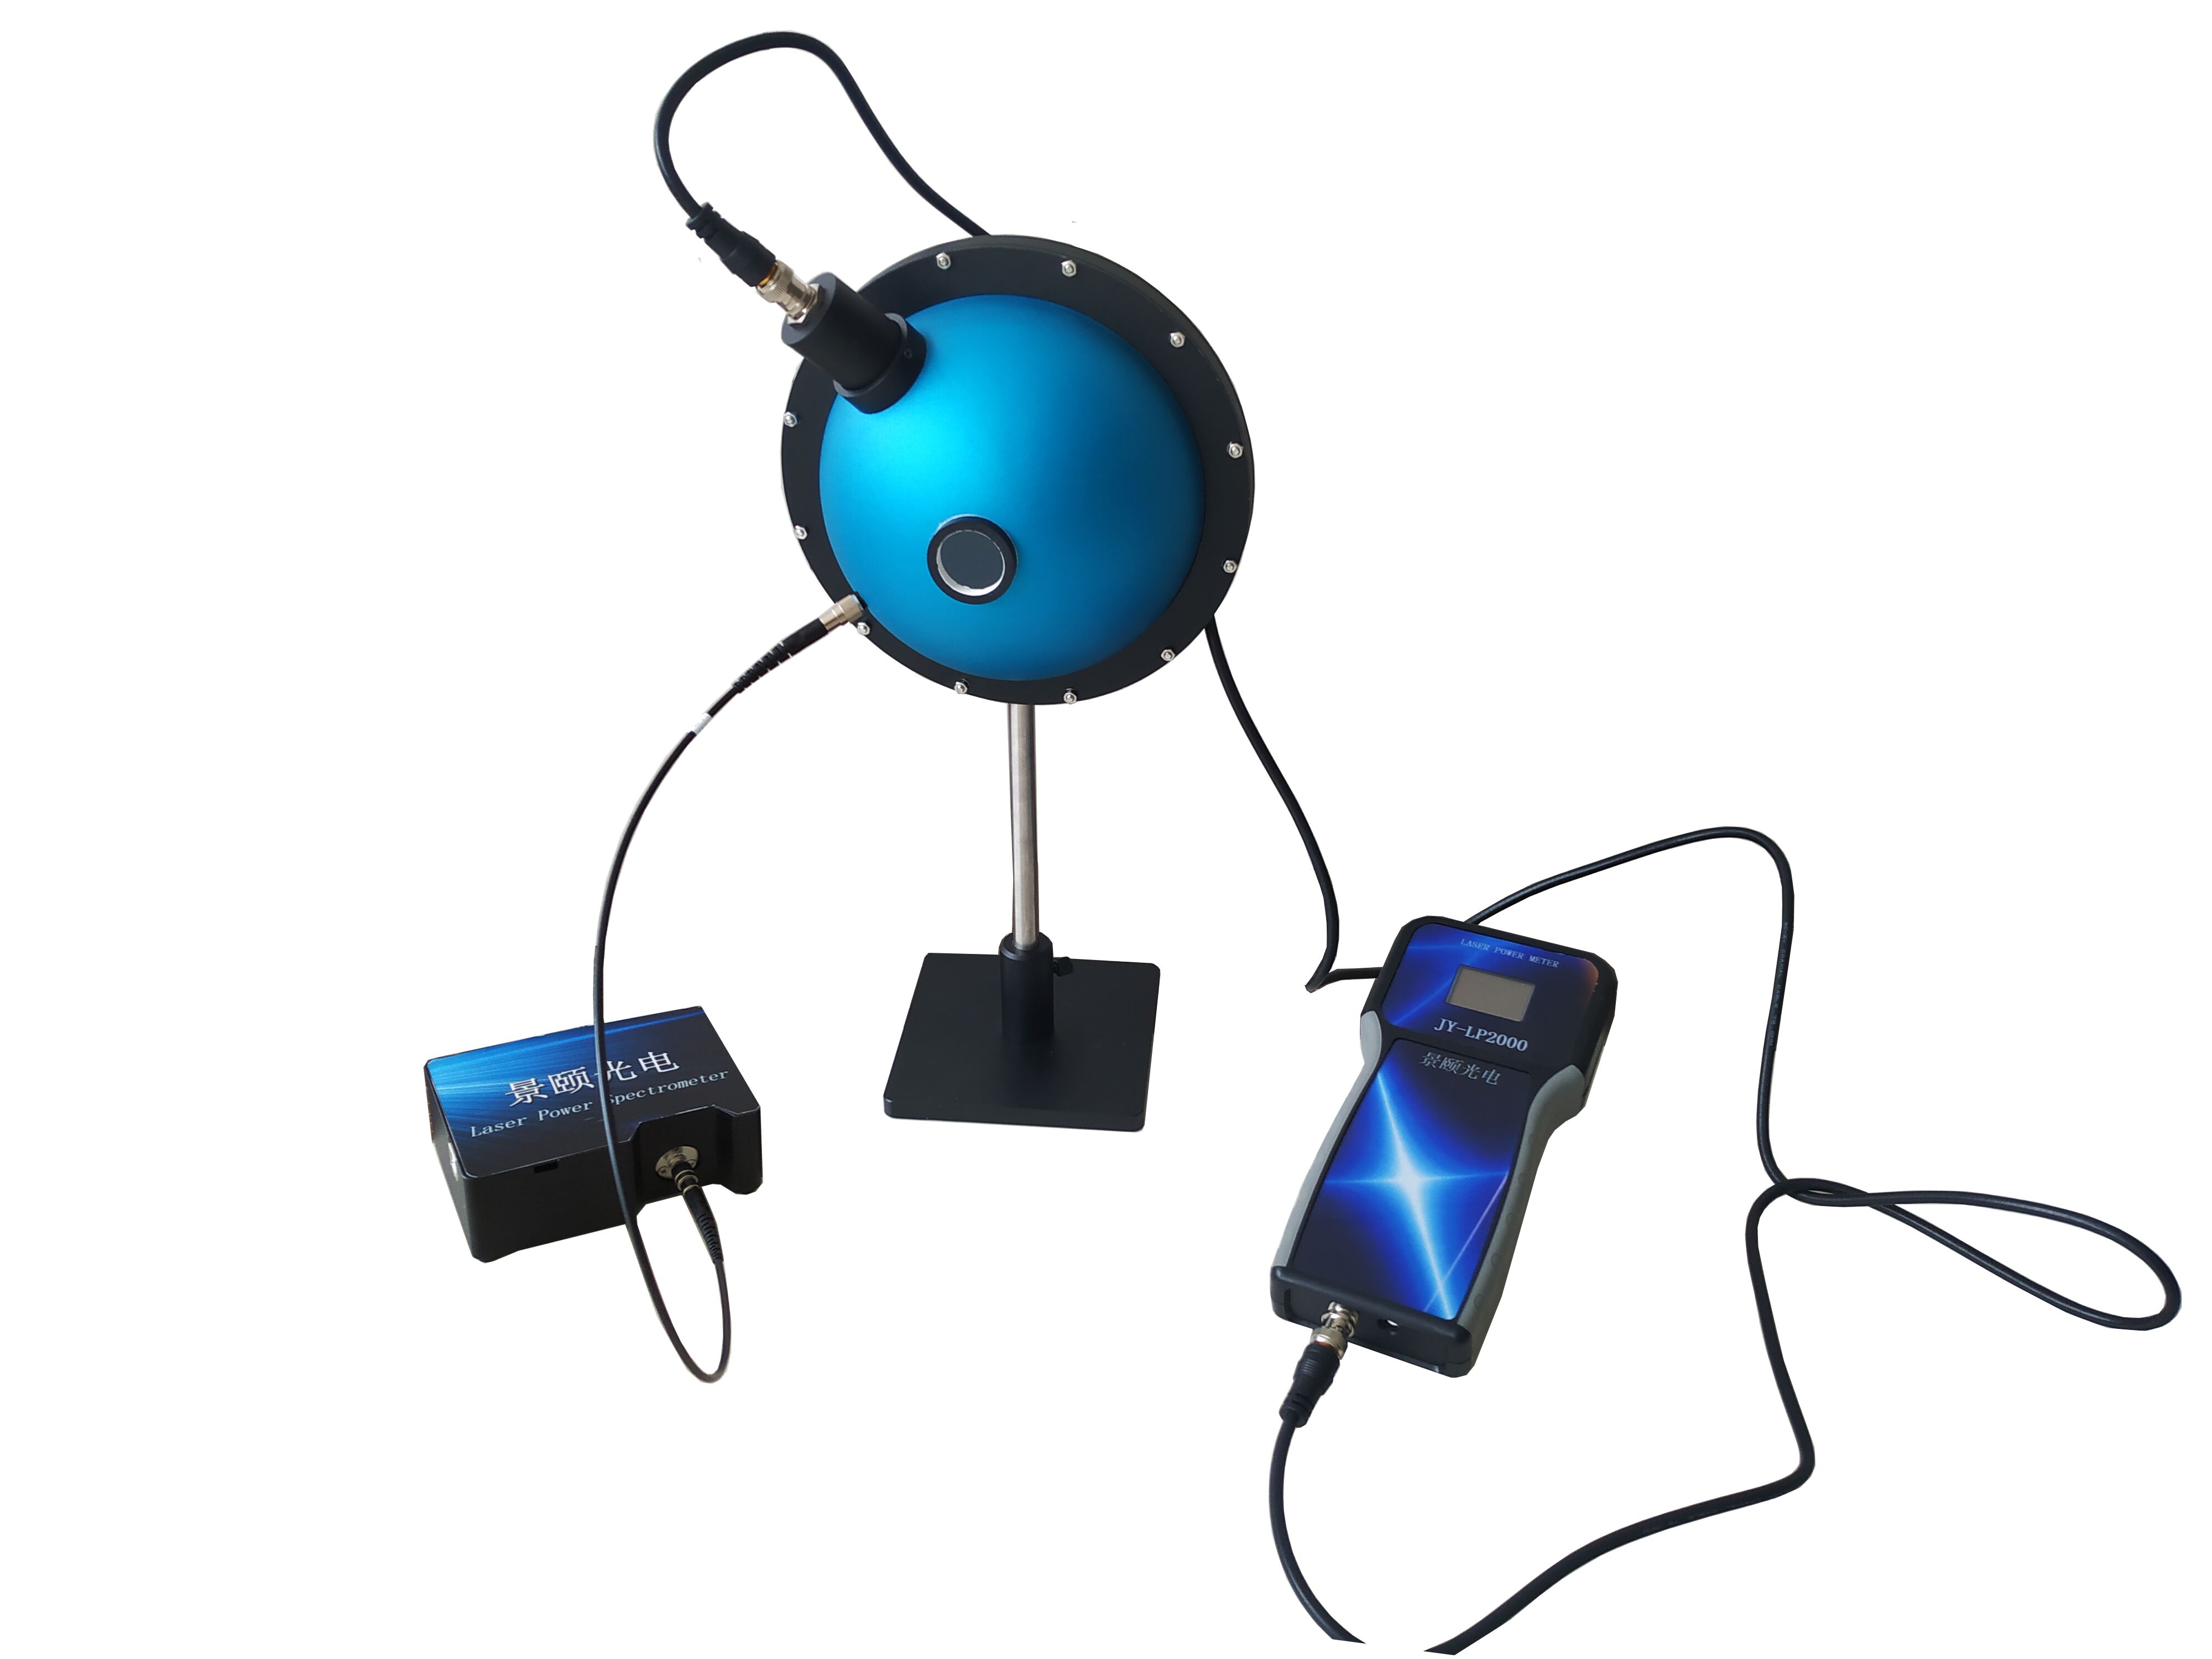
Imagine a room where every surface is frosted glass. Ordinary mirrors preserve direction; here, each photon collision scatters light in every direction, like a ping-pong ball in a velvet-lined chamber. After dozens of reflections, radiant energy at every point on the wall converges. The document stresses that this is a hollow sphere with high diffuse reflectivity, inlet and receiver ports—a geometry that converts “directional light” into “spatially uniform light.” In labs, this delivers a stable, near-Lambertian plane near the output port.
Symmetrically Arranged Light Sources
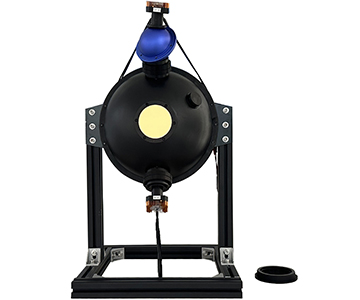
A single lamp off-center injects directionality. Bulbs must be symmetrically distributed to inject light from multiple positions, minimizing local hot spots. From an LED flux perspective, this step determines whether output is smooth and adjustable. Lamp count, placement, baffle geometry, and port size must be co-designed—you can’t just stuff in more bulbs. Powering on isn’t about chasing maximum brightness; it’s about achieving uniformity first, then dialing in luminance steps.
Output Ports and Receiver Windows
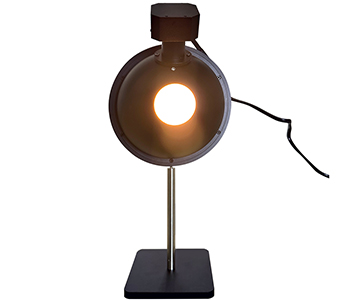
Ports act like ladles scooping standardized samples from the homogenized pool. Inlet, outlet, and detector ports can be separate, serving illumination, imaging alignment, and detection respectively. Window position, aperture, and baffles all affect uniformity. Matching port size to the detector’s field of view matters more than simply maximizing diameter.
Power Supply and Monitoring
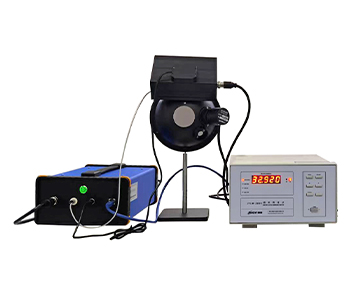
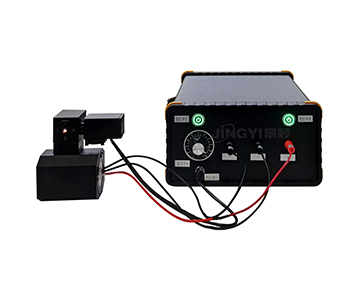
Even the best lamp flickers if current fluctuates. A uniform source must be judged not only on static uniformity but also on short-term stability and long-term drift. Engineering practice demands constant-current driving, warm-up stabilization, output monitoring, and multi-point logging. Reports should always state warm-up duration, monitoring location, and sampling interval—otherwise two calibration runs that look identical on paper will yield mismatched curves.
How Uniform Light Integrates into LED Flux Measurement
Why You Can’t “Point at the LED”
LEDs don’t emit equally in all directions; packaging, chips, and lenses steer light. Total luminous flux is the integral over the entire sphere, not a single-point reading. The integrating sphere diffuses light into a near-homogeneous field; the detector then reads a response proportional to total flux, calibrated against a standard lamp. NIST Handbook 44 and SEMI standards note that spatial non-uniformity introduces error—calibration is best done with a reference source whose spectrum and spatial distribution closely match the device under test.
This means in LED QA, the sphere isn’t a magic box. Uniformity, self-absorption, and standard lamp matching jointly determine credibility.
The Sphere as a “Standard White Wall” for Camera Calibration
When a CCD or CMOS sensor images a uniform surface, pixel output still varies due to vignetting, dark current, and responsivity differences. Positioning a uniform integrating sphere in front of the lens and capturing dark and bright fields lets you compute each pixel’s relative response for flat-field correction. This separates optical vignetting from sensor defects: if corner pixels stay low under the same uniform light, the issue is likely optical rather than electronic.
Low-Light Simulation: More Than Just Dimming the Current
Simulating starlight or moonlight requires both low intensity and preserved uniformity. Simply attenuating a strong source often introduces speckle or window reflections. The sphere’s cavity mixing produces a uniform surface, and combined with multi-level lamp control, low-light modes avoid becoming “dim but mottled.” Micro-light camera calibration must verify uniformity first, then stability—never substitute an attenuator for a sphere.
Two Industry Applications
Remote Sensing Payload Ground Calibration
During a qualification run, a lead optical engineer at a remote sensing lab mounted a small-aperture telemetry camera on a test fixture and imaged a uniform light source across three exposure tiers. Dark and bright field frames were captured per tier, and flat-field maps revealed a 6.3% lower response in one corner. After swapping interfaces and realigning the optical axis, the deviation persisted—prompting a review of the lens vignetting profile. The sphere provided a common illumination reference, ruling out wall unevenness, light guide artifacts, or mounting tilt as culprits.
Industrial Vision Camera Incoming Inspection
At an automated visual inspection facility, a batch of new cameras produced erratic yield under identical algorithm thresholds. A process engineer placed a uniform integrating sphere in front of each camera, executed dark-field subtraction and uniform-field correction, then wrote calibration files back to the devices. Retesting showed consistent imaging across the batch. The line now treats the sphere as a “camera he
Three Common Misconceptions
Myth 1: Bigger sphere, more lamps = better uniformity.
Stacking power doesn’t guarantee uniformity. Port ratio, baffle position, source symmetry, and coating condition impose hard limits. Excessive power induces wall heating, reflectivity shifts, and supply drift that can erase gains.
Myth 2: Uniform sources never need recalibration.
Coating contamination, lamp aging, window scratches, and eccentric mounting silently degrade performance. Best practice: maintain dark-field, uniform-field, and brightness monitoring logs; cross-check with standard lamps or external detectors on critical projects. Saying “it’s very uniform” without records has zero reproducibility value.
Myth 3: If it illuminates evenly, it can measure any luminous flux.
Inserting large-volume fixtures or strongly directional sources introduces self-absorption and spatial distribution errors. Standards list spatial non-uniformity as a key controlled parameter for the integrating sphere method. Spheres excel as reference sources for camera calibration; measuring total flux of specific luminaires demands additional self-absorption correction and matched reference sources.
Advanced Resources and Third-Party References
For engineers moving from科普 to engineering validation, consult open standards:
•NIST SP 250-1011 (Optical Radiation Measurements)
•SEMI PV22-0715 (Photovoltaic calibration guidelines)
•IEEE Papers on radiometric calibration
•EMVA1288 for camera characterization (uniformity, linearity, noise definitions)
For transmittance/reflectance systems, reference ISO 9050 and ASTM E903. Procurement teams should verify that suppliers provide documented calibration traceability and correction procedures—not just marketing claims.
Objective Limitations
An integrating sphere doesn’t automatically standardize any lamp you insert. Larger ports mean greater energy loss; coatings that absorb moisture, collect dust, or yellow locally will silently erode uniformity. In LED flux measurement, spatial non-uniformity and self-absorption remain unavoidable error sources—no amount of “internal uniformity” labeling can mask sample placement effects.
Stability depends on power supply and environment. Initial warm-up, wall temperature changes, and fan vibration can cause short-term drift. Engineering use requires warm-up periods, monitoring curves, and periodic re-calibration. The sphere is a reproducible reference field, not a one-time permanent fix.
Frequently Asked Questions
Q1: Is a uniform light integrating sphere the same as a luminous flux integrating sphere?
Not exactly. The former emphasizes delivering a uniform surface source from an output port, mainly for camera and detector calibration. The latter typically places the test lamp inside the sphere to collect total flux. Both share the diffuse cavity principle but differ in configuration and purpose.
Q2: Is a sphere mandatory for camera flat-field correction?
A uniform, direction-free, stable surface source yields the best results. Ordinary backlight panels suffer edge roll-off; far-field lamp arrays may retain directionality. For high-precision work, a sphere is strongly preferred. Correction still requires dark/bright field capture and algorithmic processing.
Q3: How do I verify that a low-light mode is truly uniform?
Don’t rely on visual inspection. Fix a camera, capture multiple frames, and statistically analyze center vs. corner mean, standard deviation, and spatial residual maps. Monitor drift over at least 30 minutes. Record uniformity and stability separately.
Q4: Which parameters matter most when procuring?
Port size, spectral bandwidth适配, uniformity definition and measurement location, brightness adjustment range, stability, coating condition, and monitoring method. Require suppliers to state test conditions in writing—vague claims of “good uniformity” are impossible to验收.
Q5: How can I independently verify an integrating sphere after delivery?
Use a known linear camera or external detector for multi-point scanning. Capture dark and bright fields, save raw images and condition logs. Re-test periodically to track uniformity and output drift. Ensure calibration certificates, standard documents, and sample loading procedures align for full traceability.
About This Guide
Data Sources
: NIST SP 250-1011, SEMI PV22-0715, EMVA1288 Release 4.0, in-house validation reports (n=42 calibration runs across 3 sphere configurations).
Author
: Cai Xiaodong, Senior Application Engineer, Jingyi Optoelectronics, 11 years in optical metrology and machine vision calibration.
Disclosure
: Jingyi Optoelectronics manufactures uniform light integrating spheres and related optical test equipment. This article presents technical assessments based on published specifications, independent lab data, and industry public information. No compensation was received from third-party brands mentioned.
Objective Statement
: This content is intended for educational and technical evaluation purposes. Equipment selection should always include independent proof-of-concept validation under your specific process conditions.
Last Updated
: October 2026
For detailed specifications and application notes on uniform light integrating spheres, search "Jingyi Optoelectronics uniform light integrating sphere" or visit our technical library.